六目采集设备 Y6、HARBOR 采集网络、KineFlow 处理产线与 EGO DataHub 平台,整套交钥匙、可私有化部署。你定义要让机器人学会的技能,我们交付设备与产线,让你在自己环境里持续产出可直接训练的第一人称数据——数据归你所有、不出域。 The six-camera Y6 headset, HARBOR capture network, KineFlow processing pipelines and EGO DataHub platform — delivered turnkey, deployable on-premises. You define the skill; we deliver the hardware and pipelines that keep producing ready-to-train egocentric data in your own environment — the data is yours, in your domain.
你定义要让机器人学会的技能,我们交付设备与整条数据产线,私有化部署、交钥匙落地。数据是你自建产线跑出来的产出,归你所有、不出域——我们的主业是交付设备与管线能力,而不是按条零售数据。You define the skill; we deliver the hardware and the entire data production line, deployed on-premises, turnkey. Data is what your own pipeline produces — yours, in your domain. We sell hardware and pipeline capability, not data by the clip.
定义目标技能、场景与数据规格(模态、时长、精度),任务三级编目。Define skills, scenes and data spec (modalities, hours, accuracy); tasks catalogued in three levels.
六目 Y6 自主或委托采集,HARBOR 调度全国站点与采集员,看板全程在线。Six-camera Y6 capture by your team or the network; HARBOR schedules national sites with a live kanban.
<1μs 硬件同步、机内直出 SLAM,加密回传、丢帧自动检测。Sub-μs hardware sync, on-device SLAM, encrypted upload and automatic drop-frame checks.
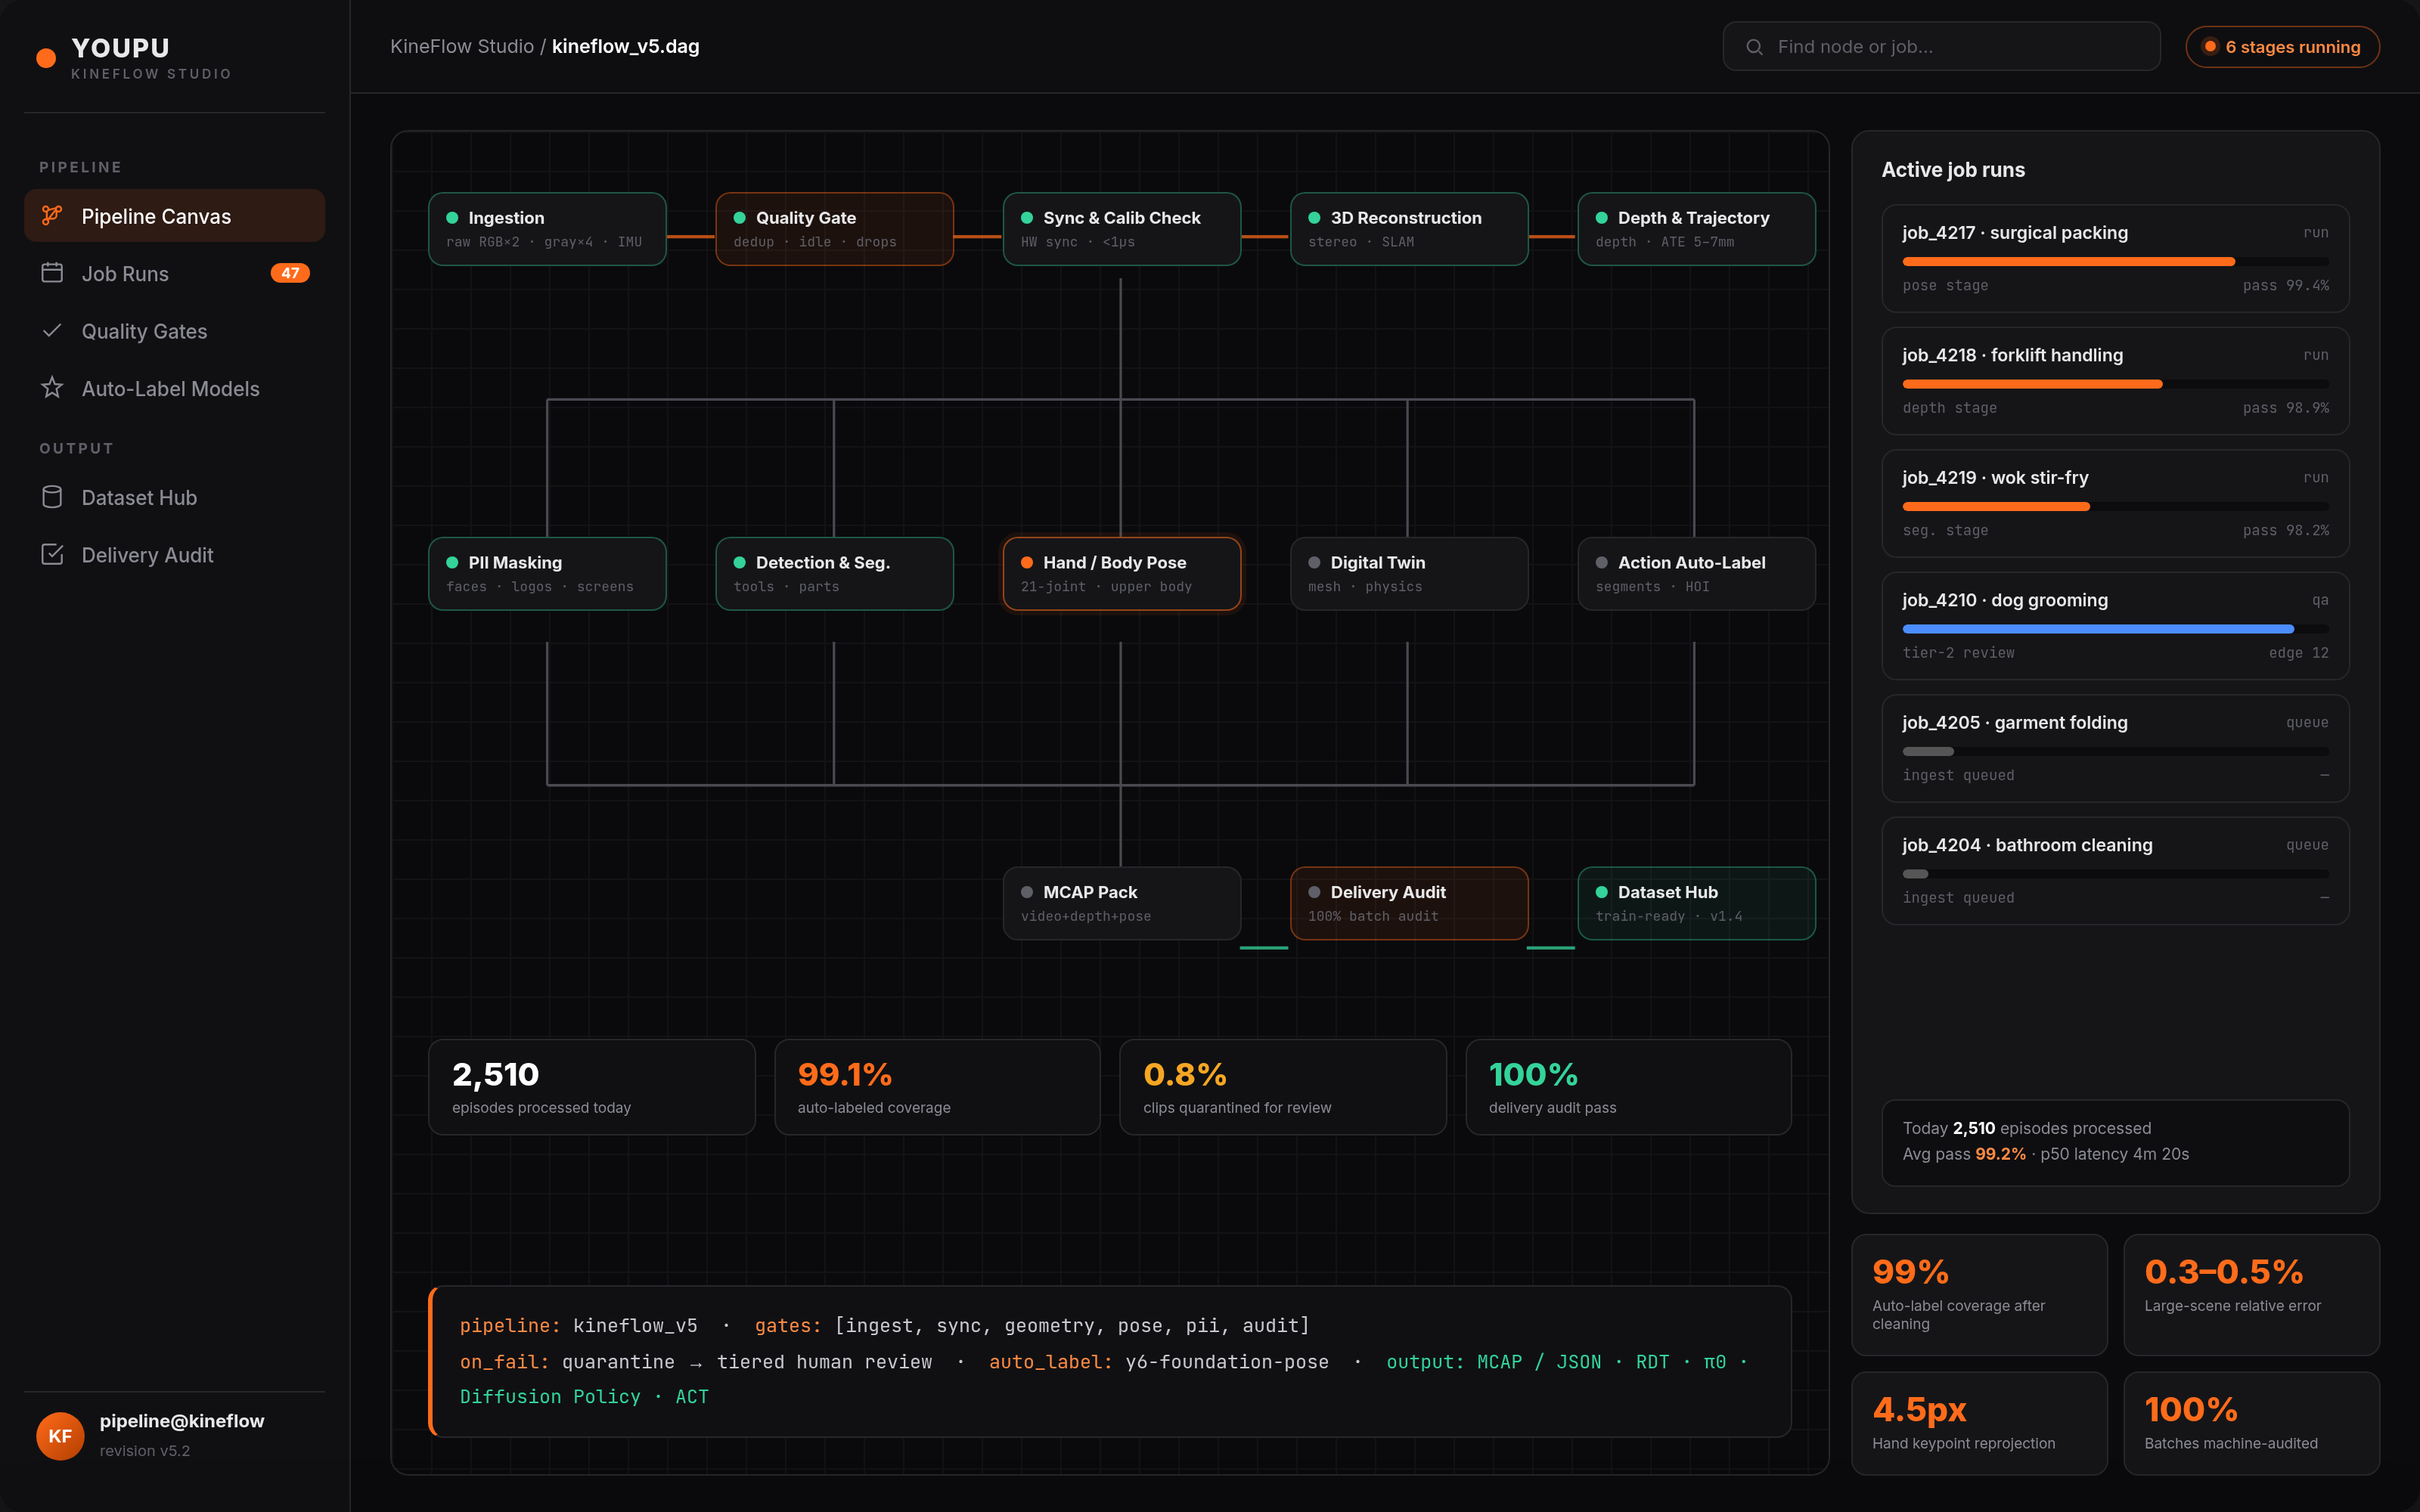
质量门、3D 重建、多模态提取、自动预标注,机器质检 + 分层人工审核。Quality gates, 3D reconstruction, multimodal extraction, auto-labeling, machine QC + tiered review.
训练就绪 MCAP 数据包,版本血缘、审计报告齐备,进入你的专属资产库。Train-ready MCAP bundles with version lineage and audit reports, into your dedicated library.
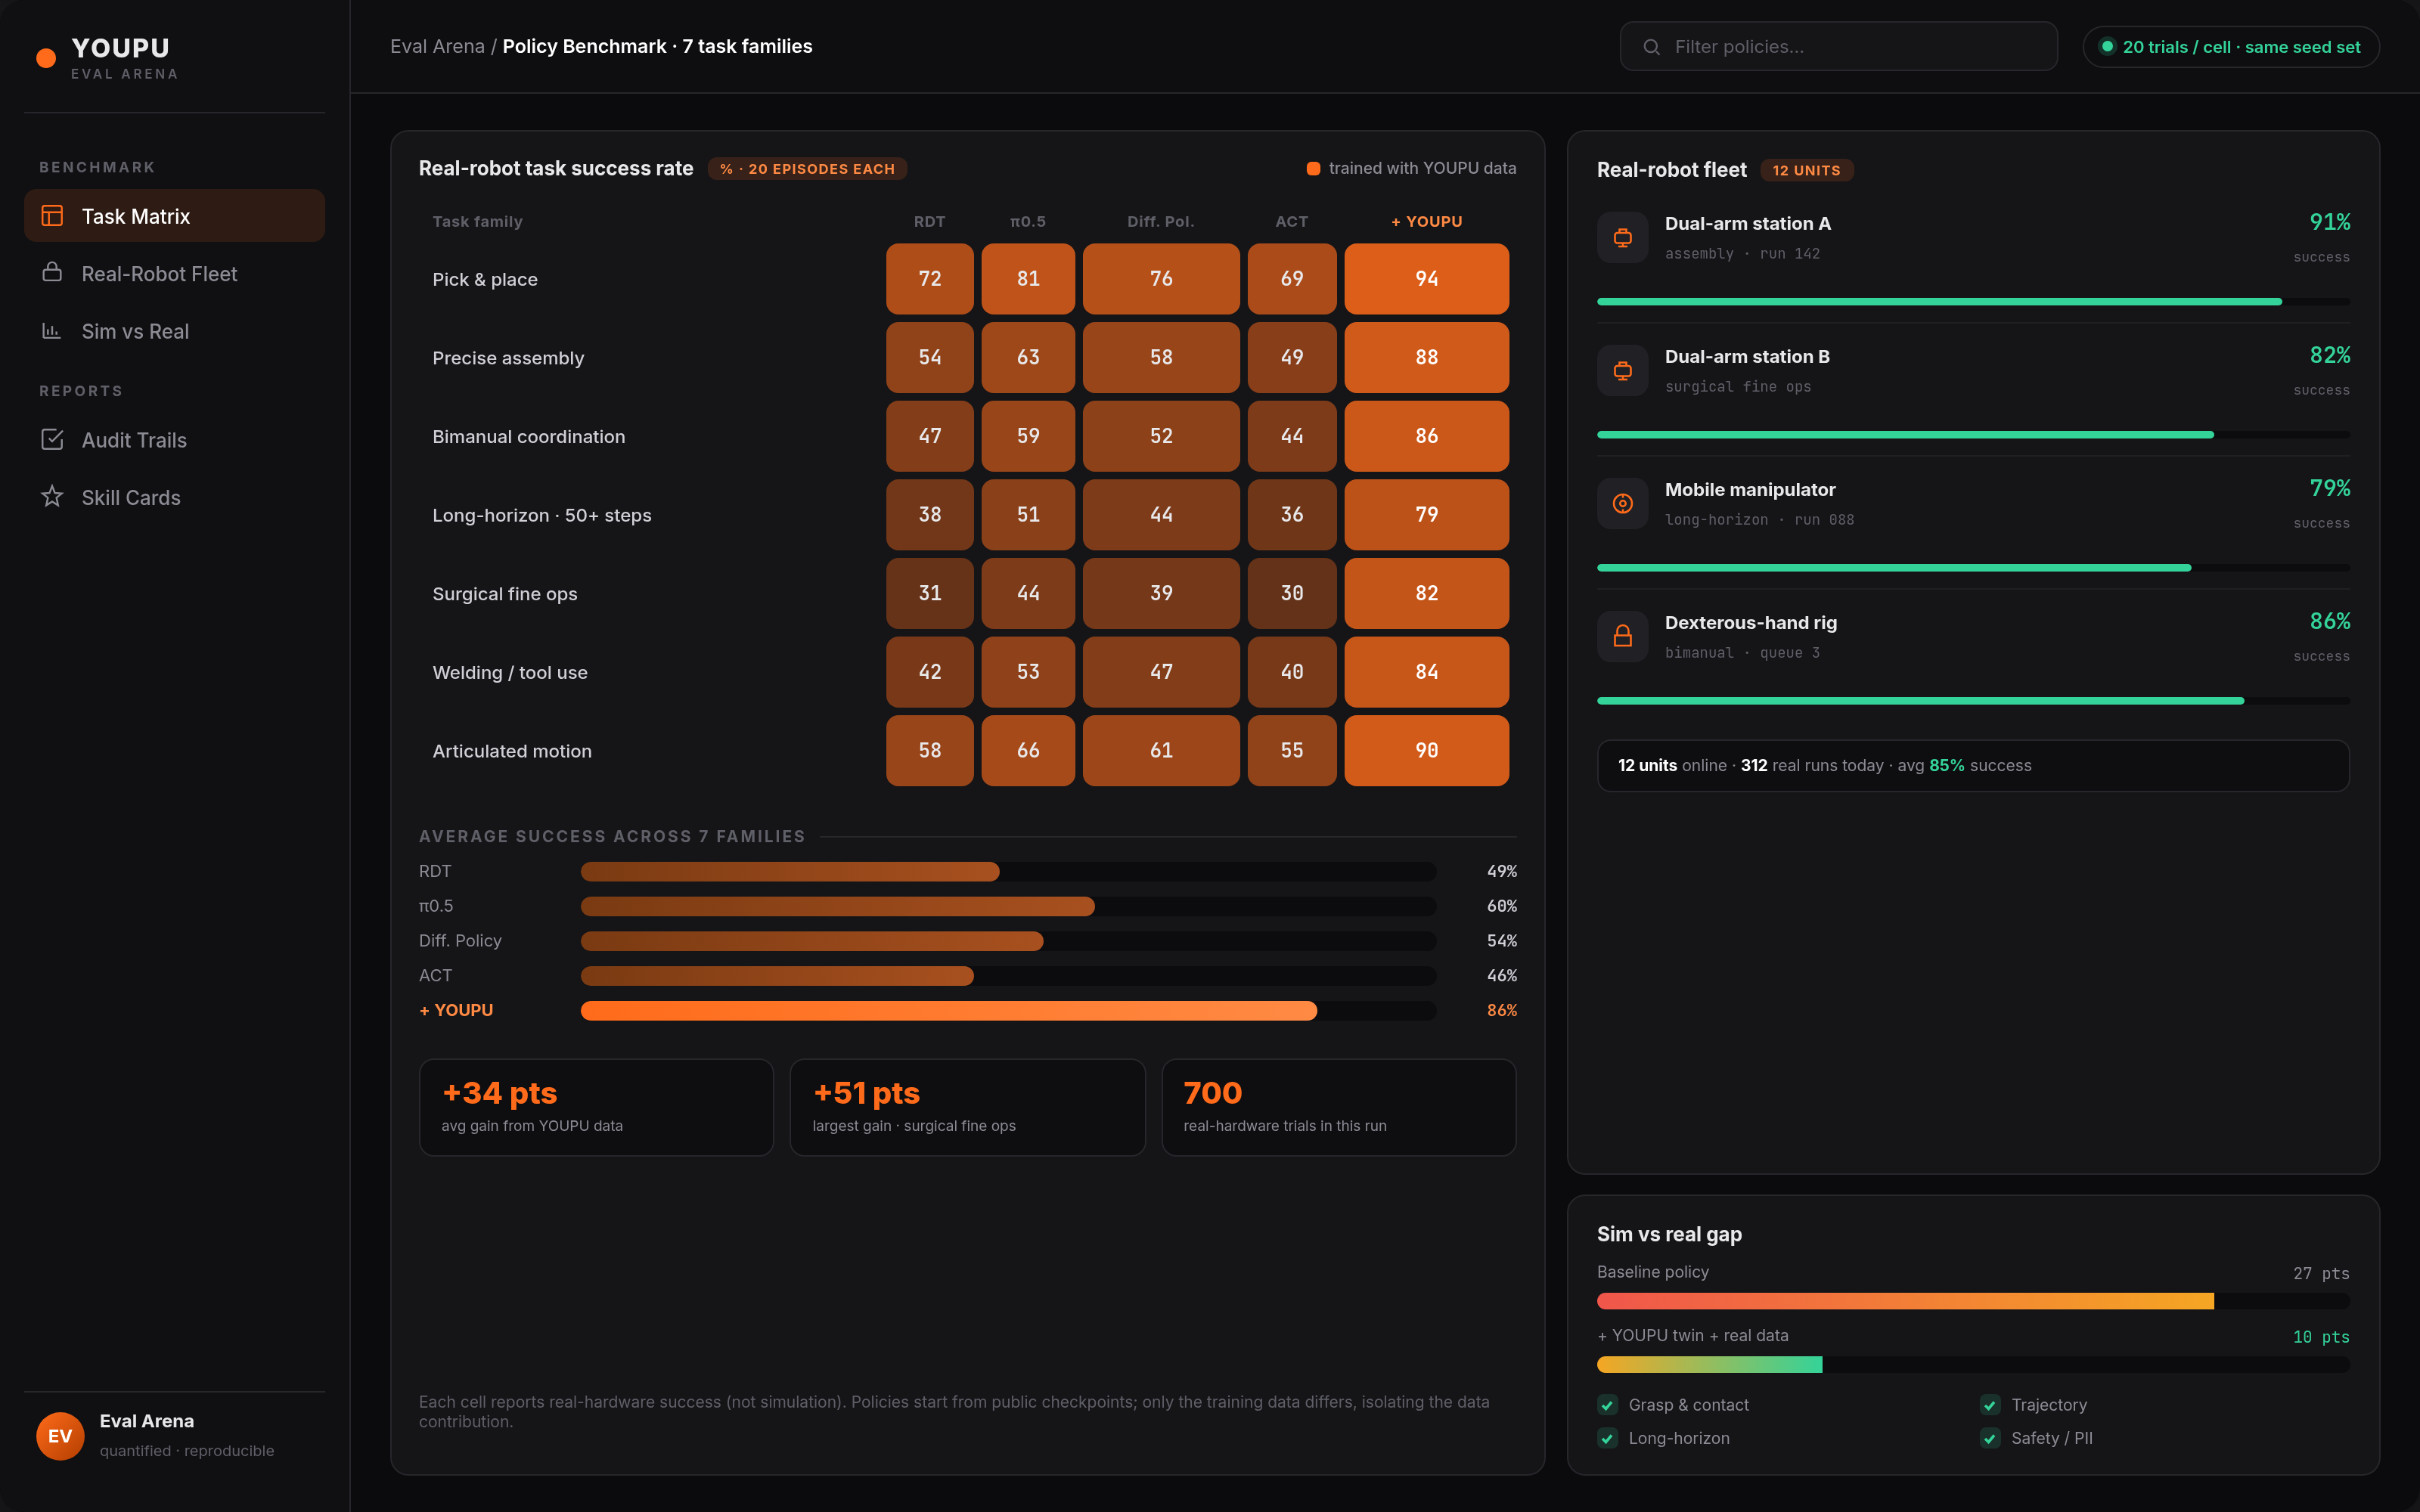
直连主流 VLA / 模仿学习,仿真扩增与真机评测,部署后数据回流、产线迭代。Plug into leading VLA / imitation models; sim augmentation, real-robot eval, post-deploy data flywheel.
既可整套交钥匙、私有化部署到你内部,也可只买设备、只授权软件,或联合共建陪跑。设备始终可单独采购,数据始终归你所有。Take the whole stack turnkey on-premises, buy headsets only, license the software, or co-build. Hardware is always sold separately, and the data is always yours.
设备 + 采集网络 + 处理产线 + 数据平台一体交付,集成、标定、培训、运维全包;数据不出域、资产归你。Headsets + network + pipelines + platform in one, with integration, calibration, training and managed ops; data stays in-domain and yours.
Y6 六目设备单独批量采购,相机 / 外观 / 结构可定制,数据接口全开放。Buy Y6 six-camera headsets in volume; camera, exterior and mech customizable, interfaces fully open.
KineFlow + EGO DataHub / HARBOR 授权或订阅,开放接入第三方双目 / 四目设备。License or subscribe to KineFlow + DataHub / HARBOR; third-party stereo / quad rigs welcome.
POC 试点、采集网络共享、标注质检托管、持续运维与产线升级。POC pilots, shared capture network, managed labeling / QC, ongoing ops and upgrades.
设备可以单独采购,但更大的价值是把采集终端、处理产线与数据平台整套交付、私有化部署——你拥有的是一条持续产出训练数据的自有产线,数据资产完全归你。Headsets can be bought on their own — but the bigger value is the full stack of capture hardware, processing pipelines and data platform deployed on-premises. You own a production line that keeps generating training data, and you own the data.
双目能"看见",六目才能"测准"。更多灰度相机提供稳定的立体基线与冗余视角,让全天候、长时序作业下的 SLAM 与手部轨迹更稳、更准。Stereo can see; six cameras can measure. Extra grayscale cameras add stable baselines and redundant views, keeping SLAM and hand trajectories robust across long, all-day sessions.
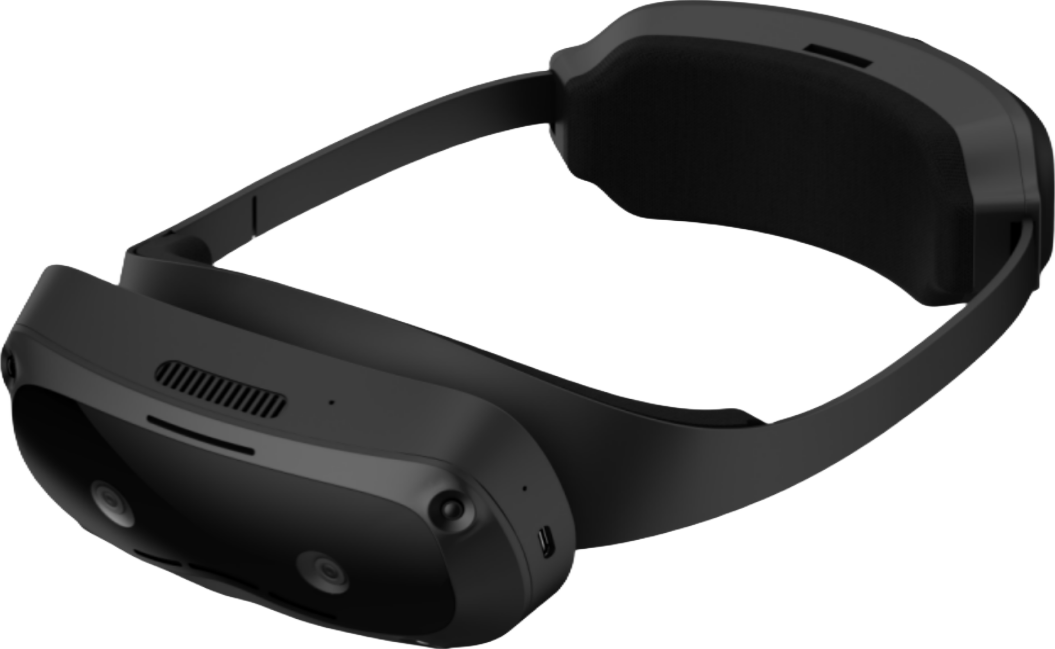
灰度全局快门在弱纹理、快速运动、光照变化下仍稳定锁定特征,是长时序不漂移的关键。
Grayscale global shutter locks features under weak texture, fast motion and lighting shifts — key to drift-free long sessions.
我们不与成熟双目/四目厂商对立——管线对主流设备开放兼容;但要全天候、长时序、毫米级的高质量数据,六目是更稳的答案。We don't compete with mature stereo/quad vendors — the pipeline is open to mainstream rigs. But for all-day, long-horizon, millimeter-grade data, six cameras are the robust answer.
| 维度Dimension | 双目(第三方)Stereo (3rd-party) | 四目(第三方)Quad (3rd-party) | 六目 Y6Six-Cam Y6 |
|---|---|---|---|
| 立体基线 / 冗余Baseline / redundancy | 单一基线,遮挡即失效Single baseline, fails on occlusion | 有限冗余Limited redundancy | 多基线 + 多视角冗余Multi-baseline, multi-view redundancy |
| 长时序漂移Long-horizon drift | 大场景易累积漂移Accumulates in large scenes | 中等Moderate | 近距 5–7mm,大场景相对误差 0.3–0.5%5–7 mm near, 0.3–0.5% large-scene |
| 弱光 / 弱纹理Low light / texture | 易丢特征Loses features easily | 一般Fair | 4 灰度全局快门,稳定4 grayscale global shutters, stable |
| 手部精细操作Fine manipulation | 手部遮挡时视角不足Insufficient views when occluded | 可用Usable | 多视角补盲,可信帧 >96%Multi-view fill-in, >96% valid frames |
| 重量 / 续航Weight / battery | <140g · 6h | 370g · 5500mAh | 370g · 后置配重长续航 |
| 适配定位Best for | 轻量、短任务、低成本Light, short, low-cost tasks | 中等复杂度作业Mid-complexity work | 全天候长时序高质量数据All-day, long-horizon, high-quality data |
戴在额头、双眼露出,无显示无镜片;从实验室、车间到手术室,长时间佩戴依然舒适。Forehead-worn with eyes free, no display or lens; comfortable for long sessions from labs and workshops to operating rooms.
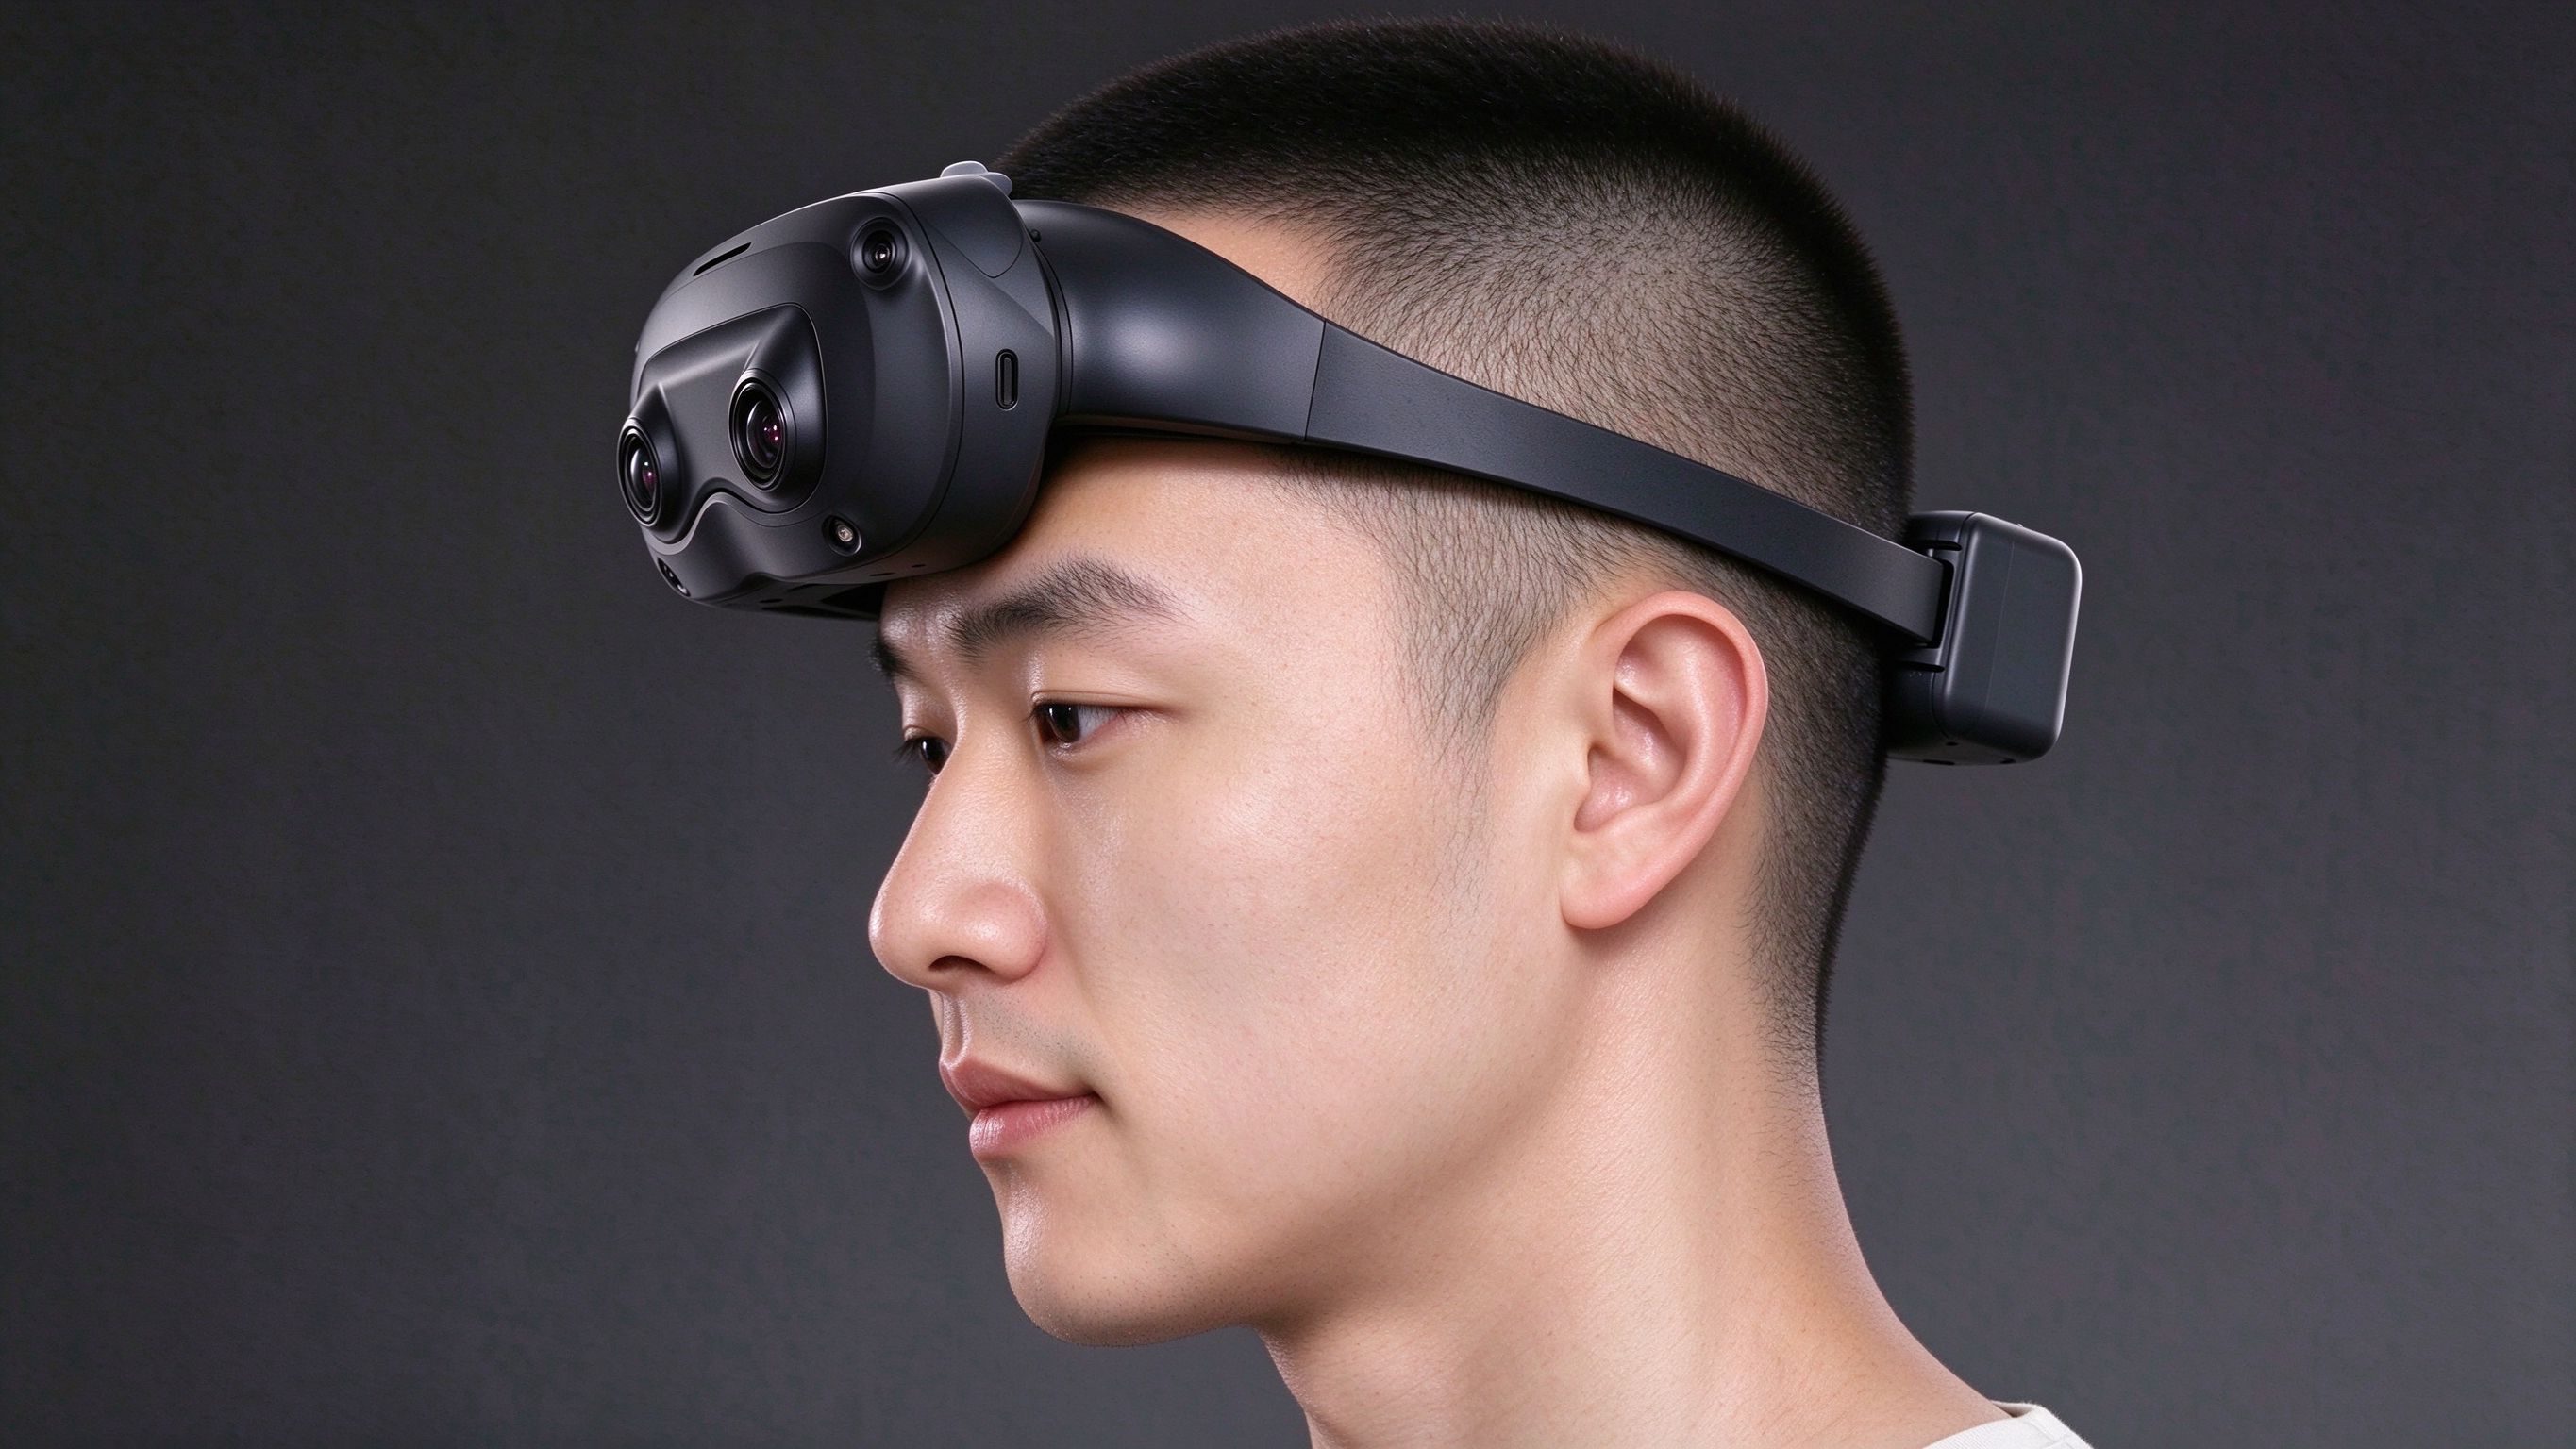
佩戴侧视 · 后置电池Side · rear battery
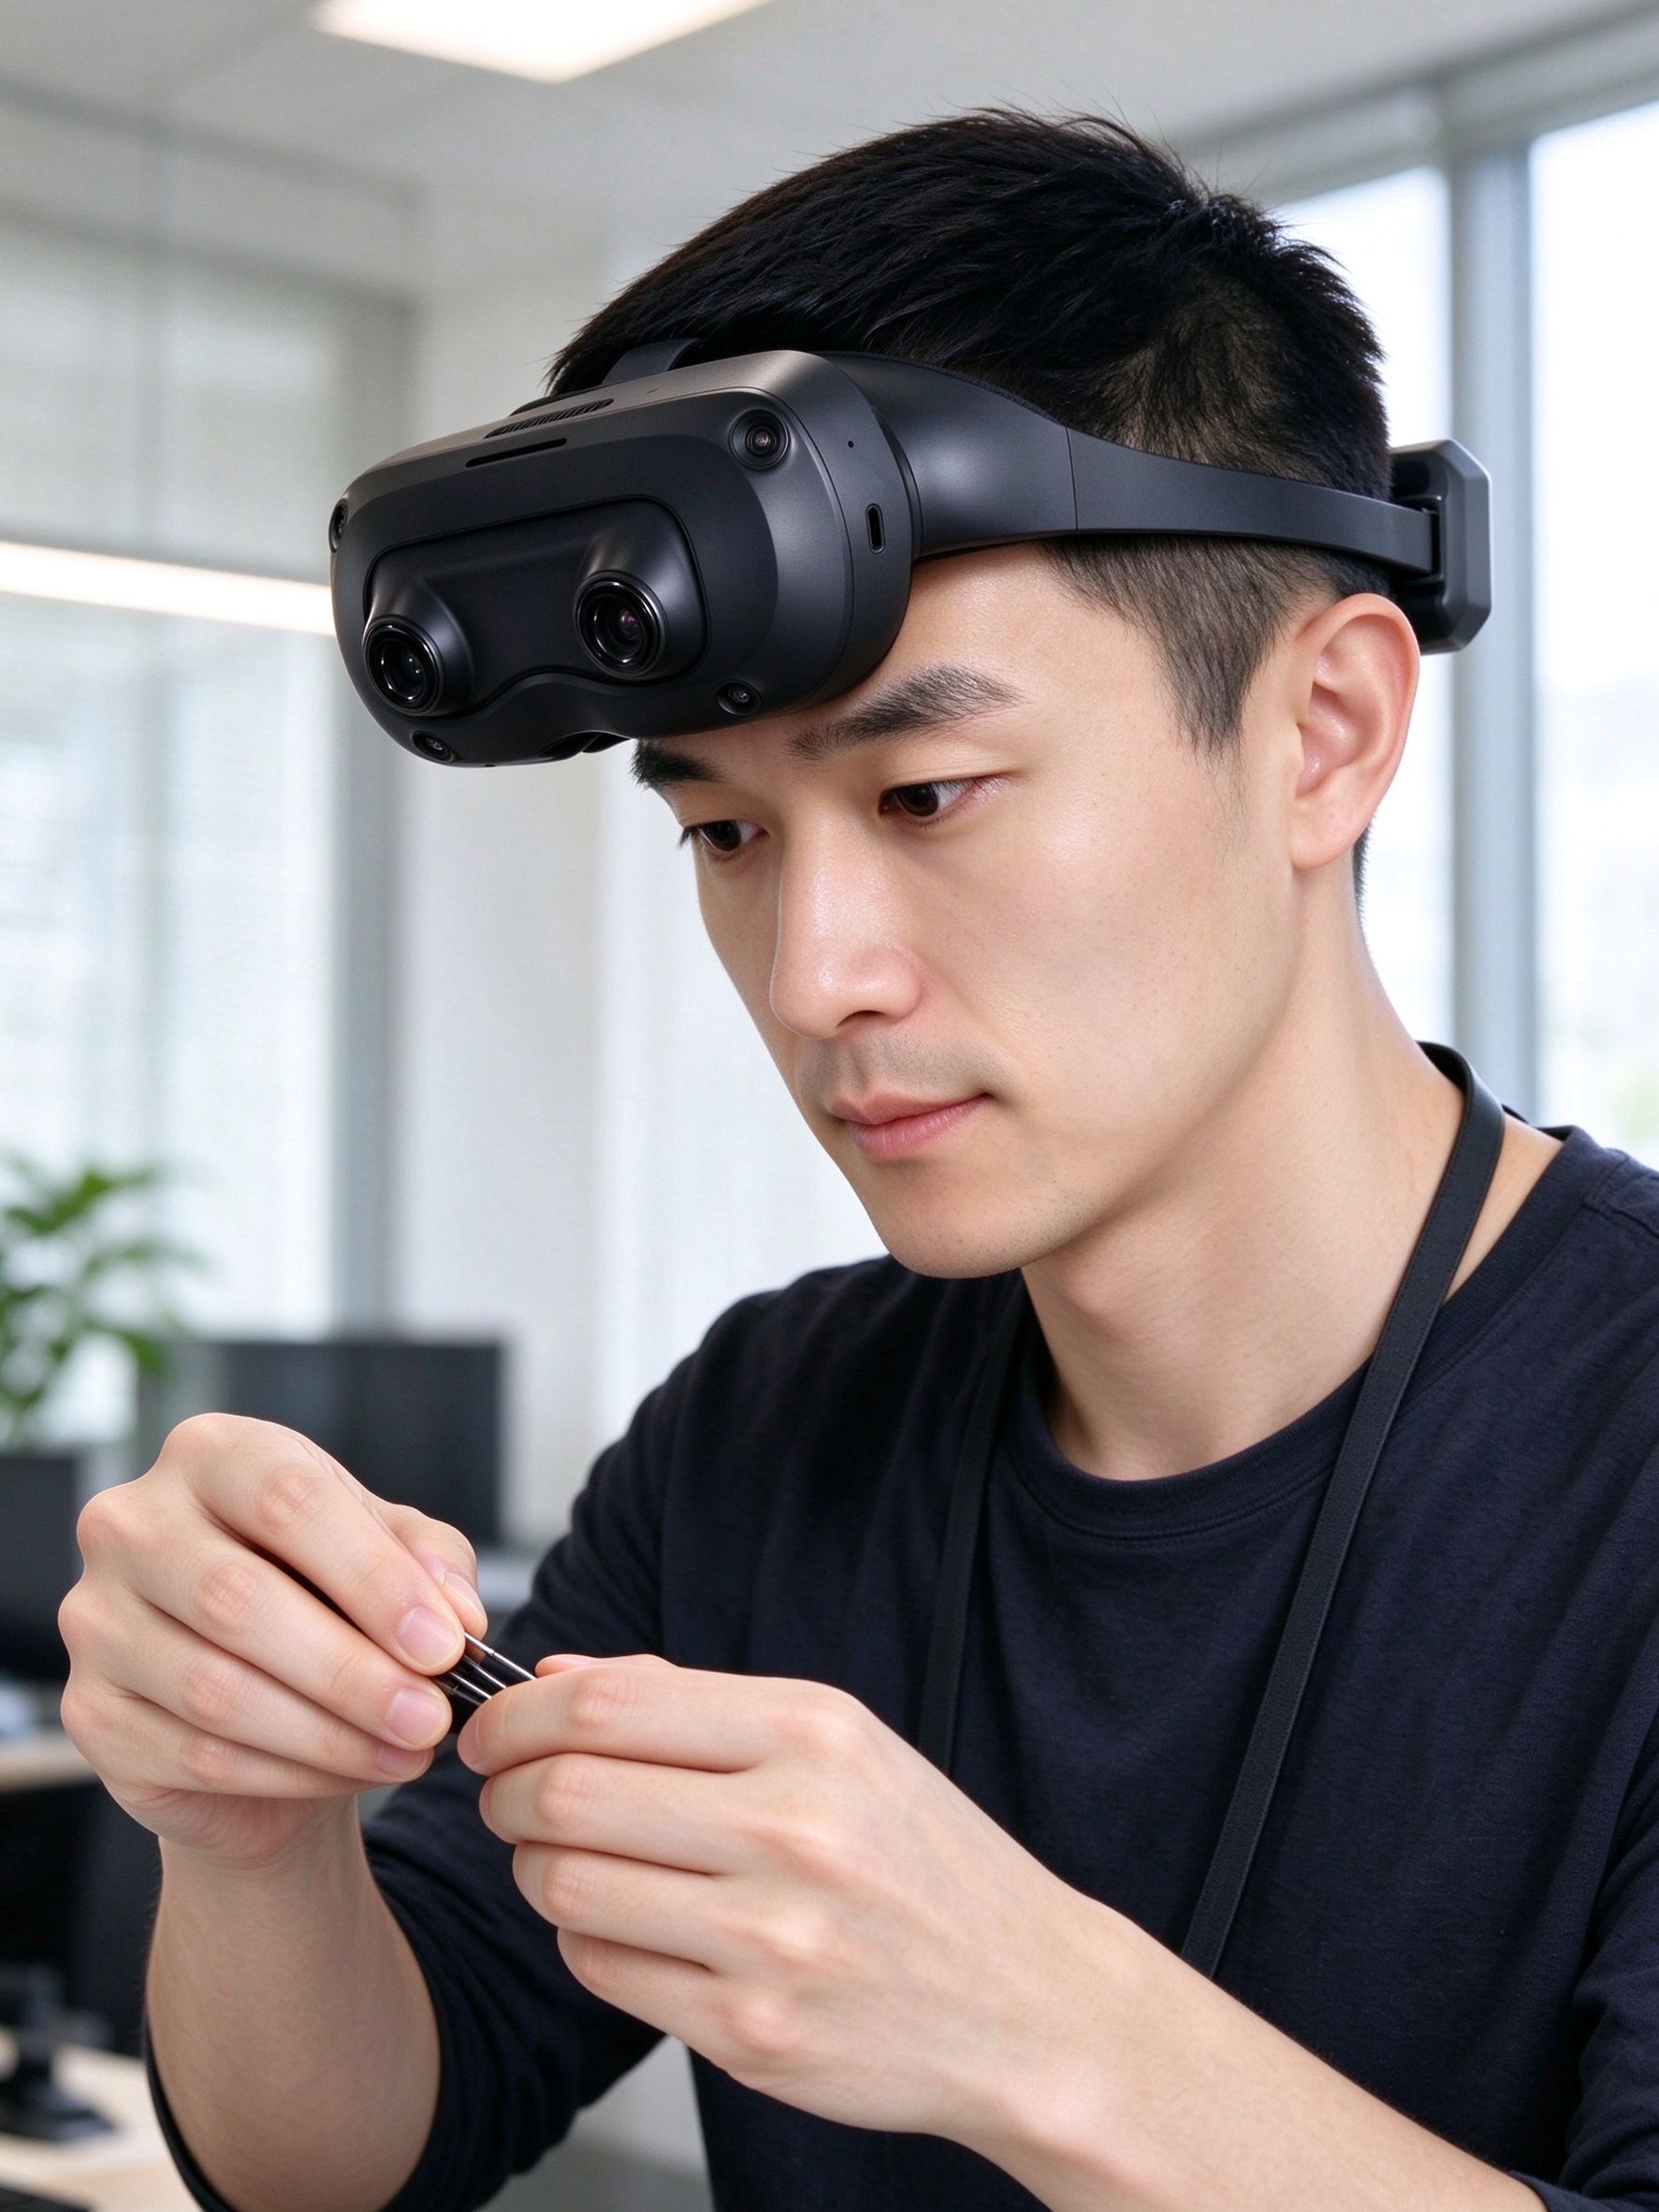
正面佩戴Front wear
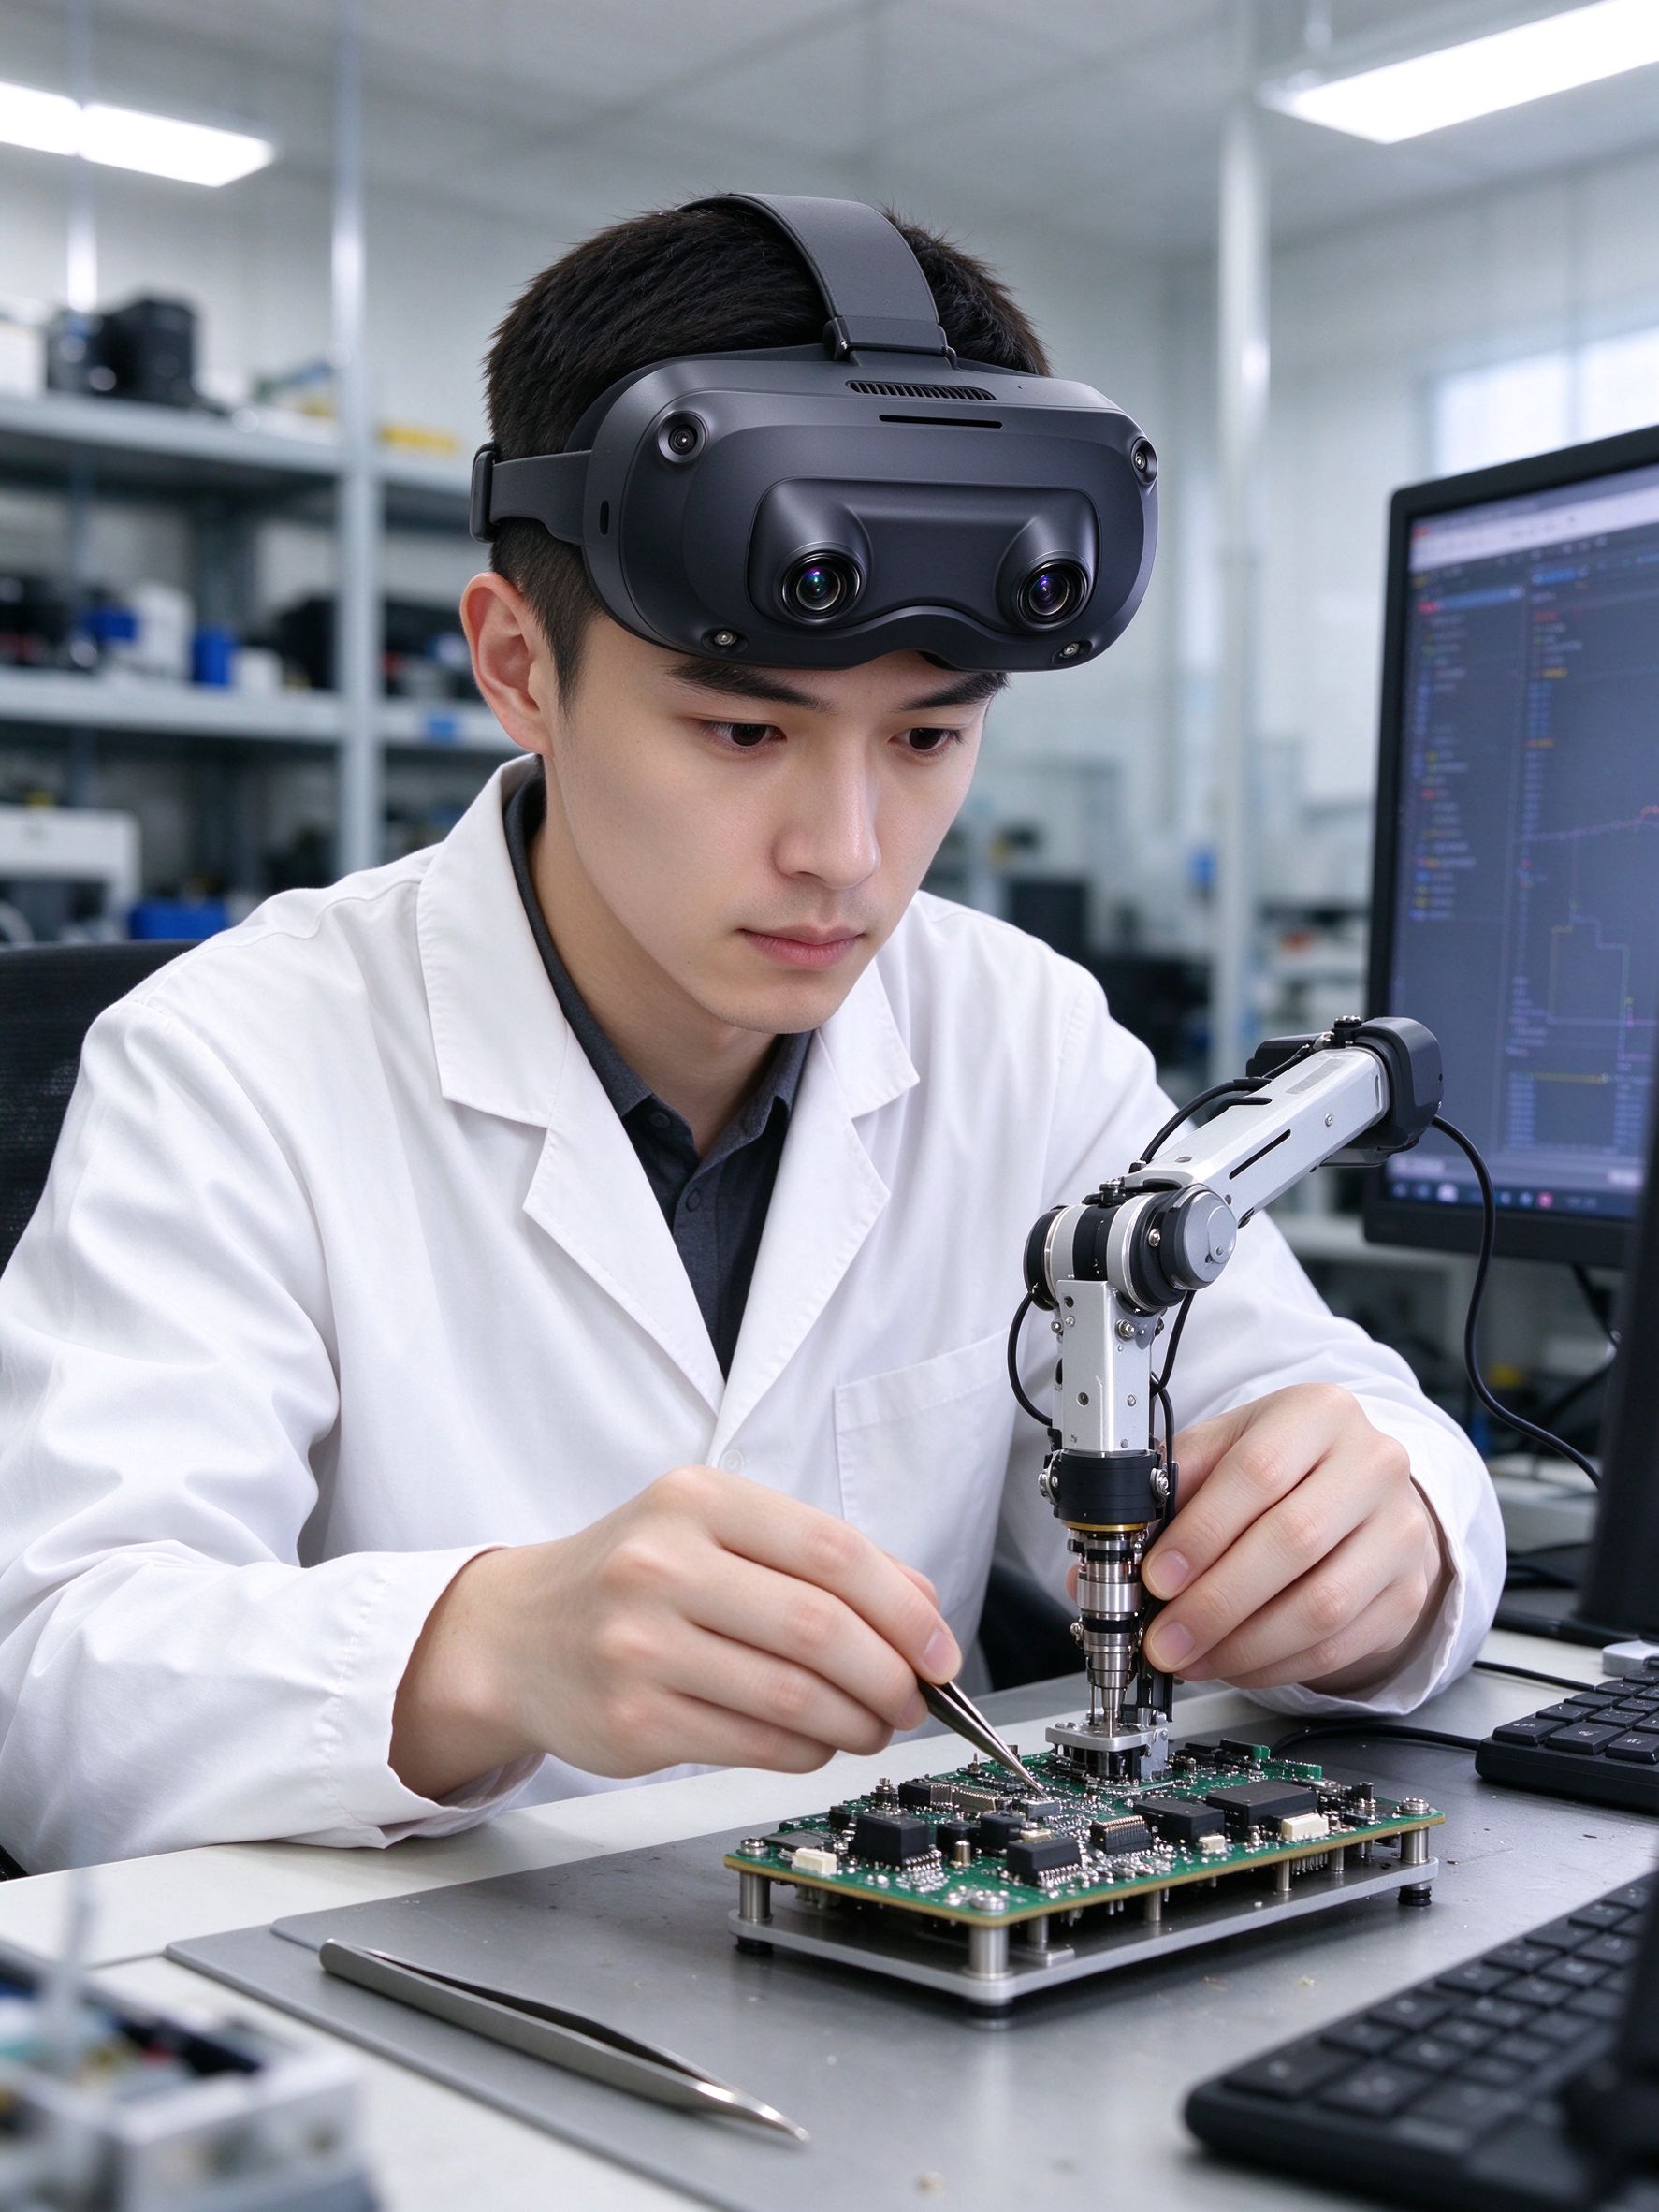
实验室Laboratory
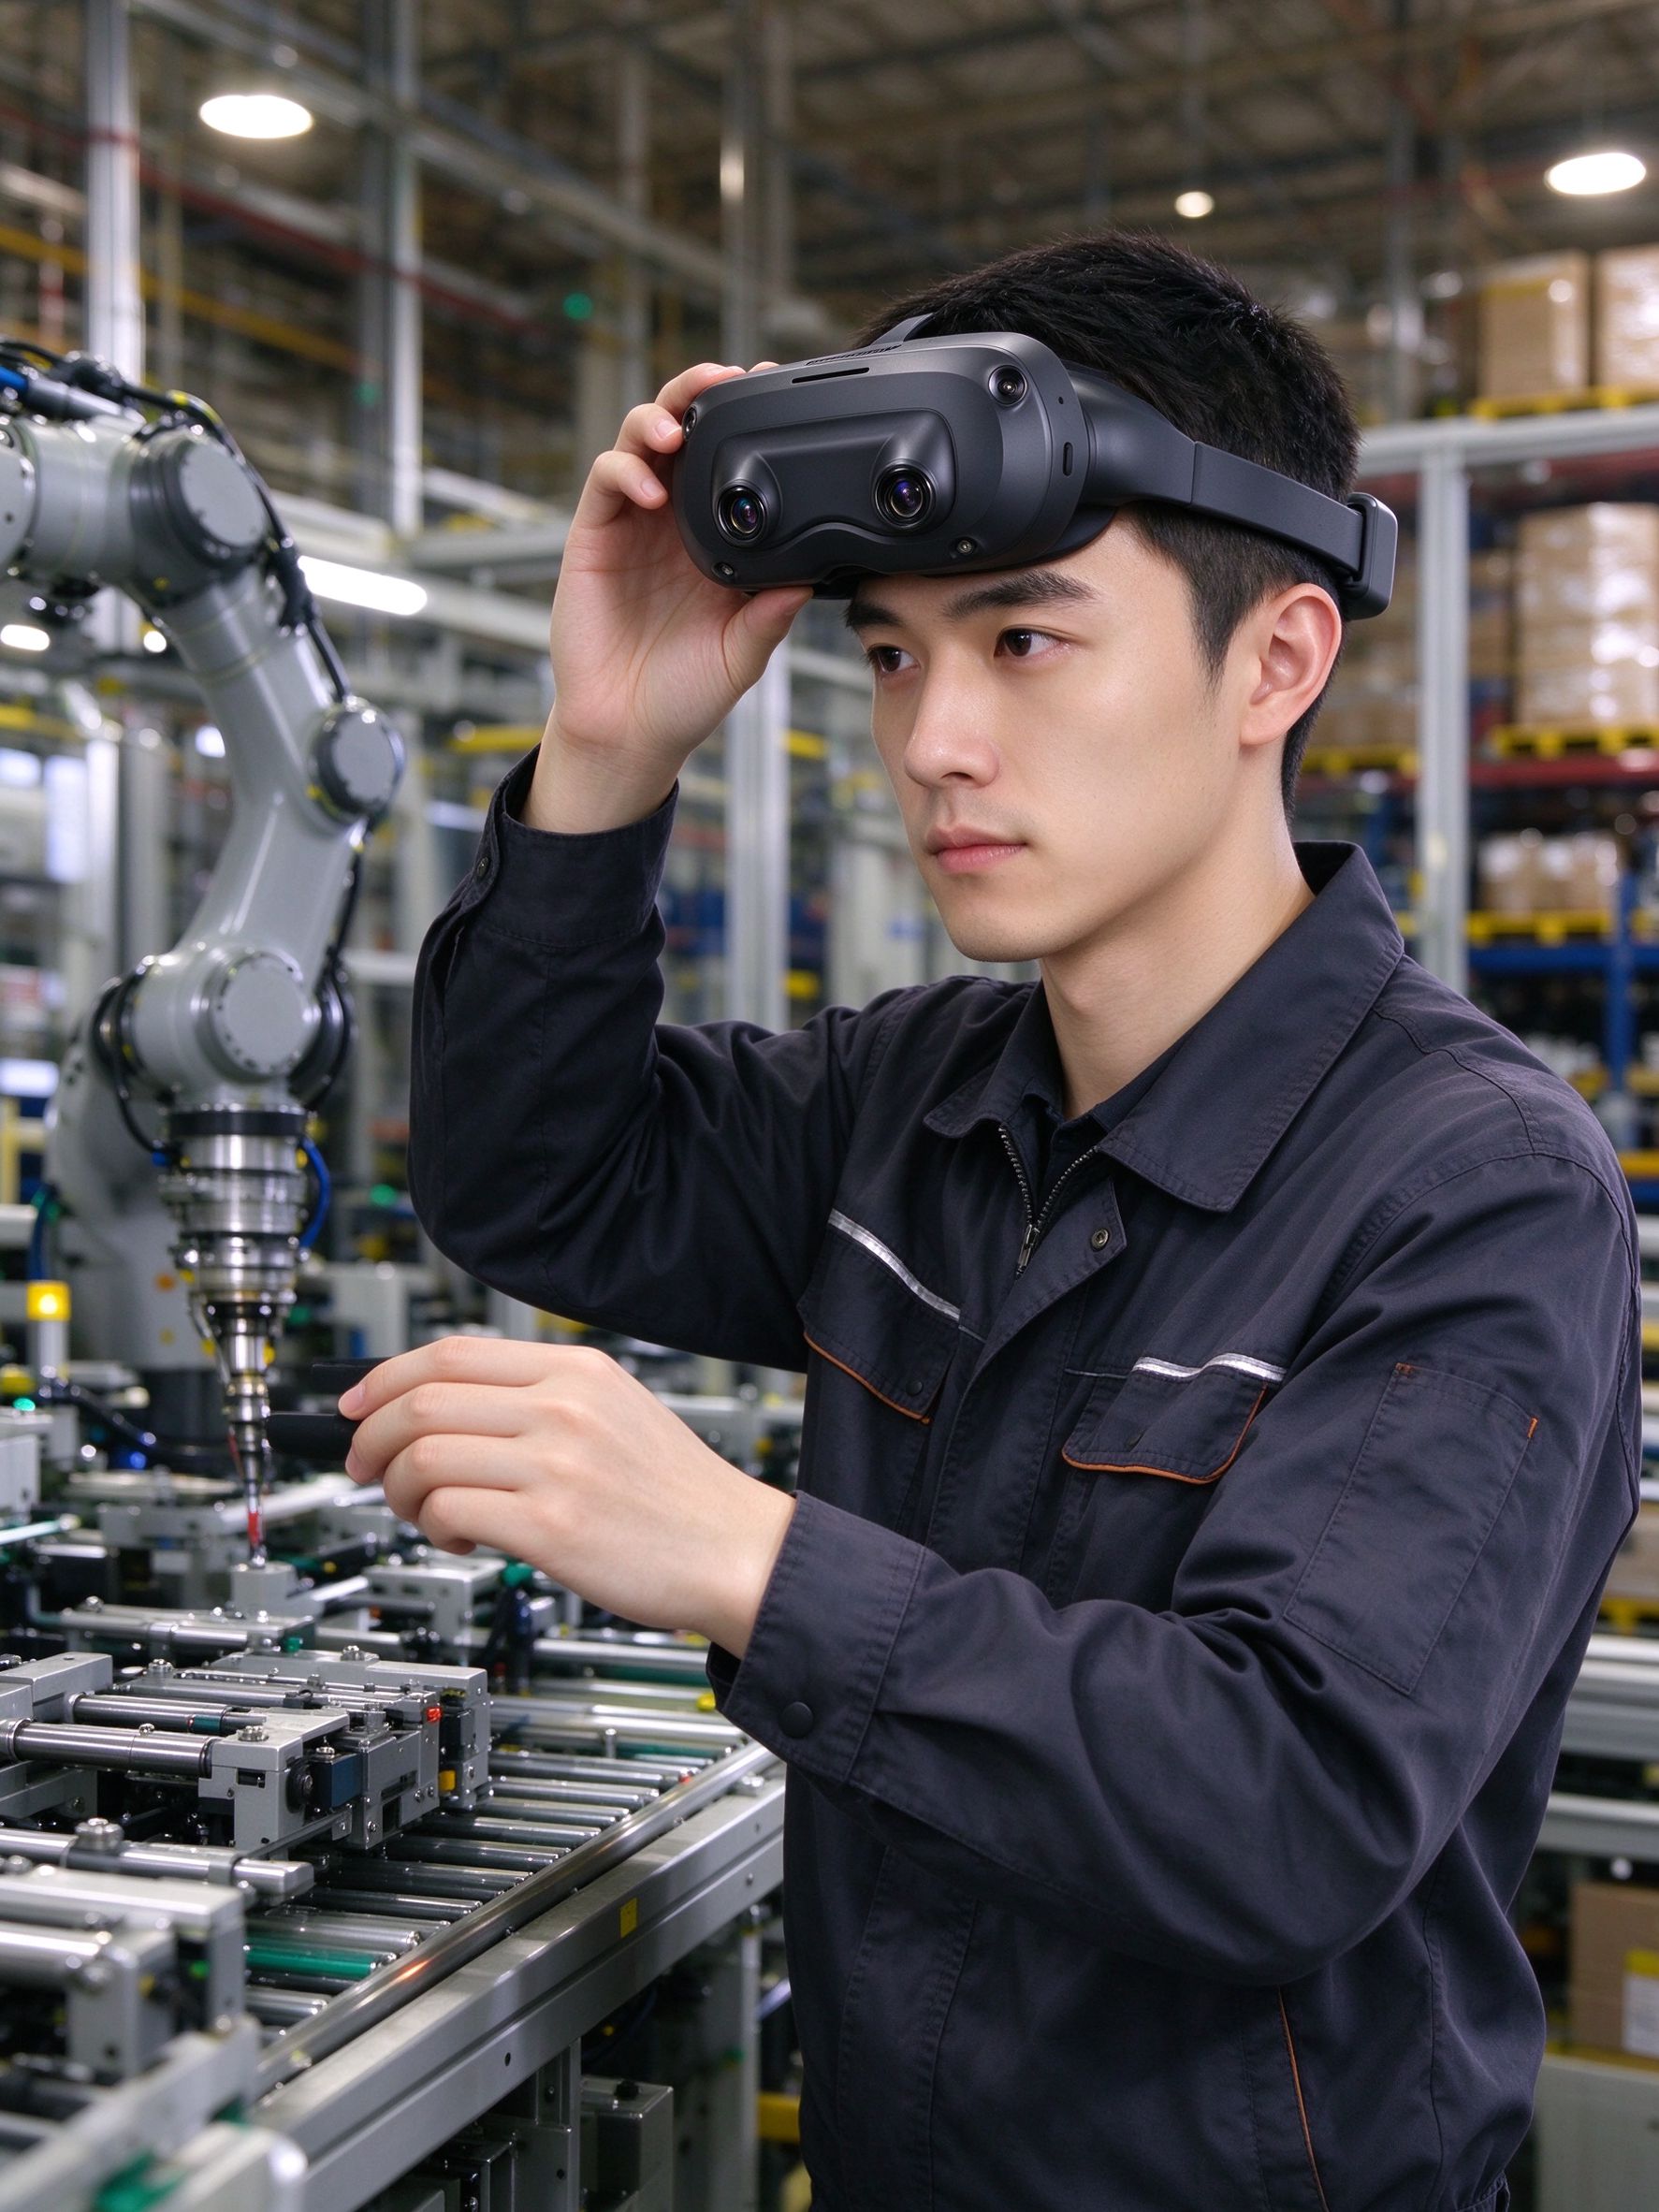
车间Factory
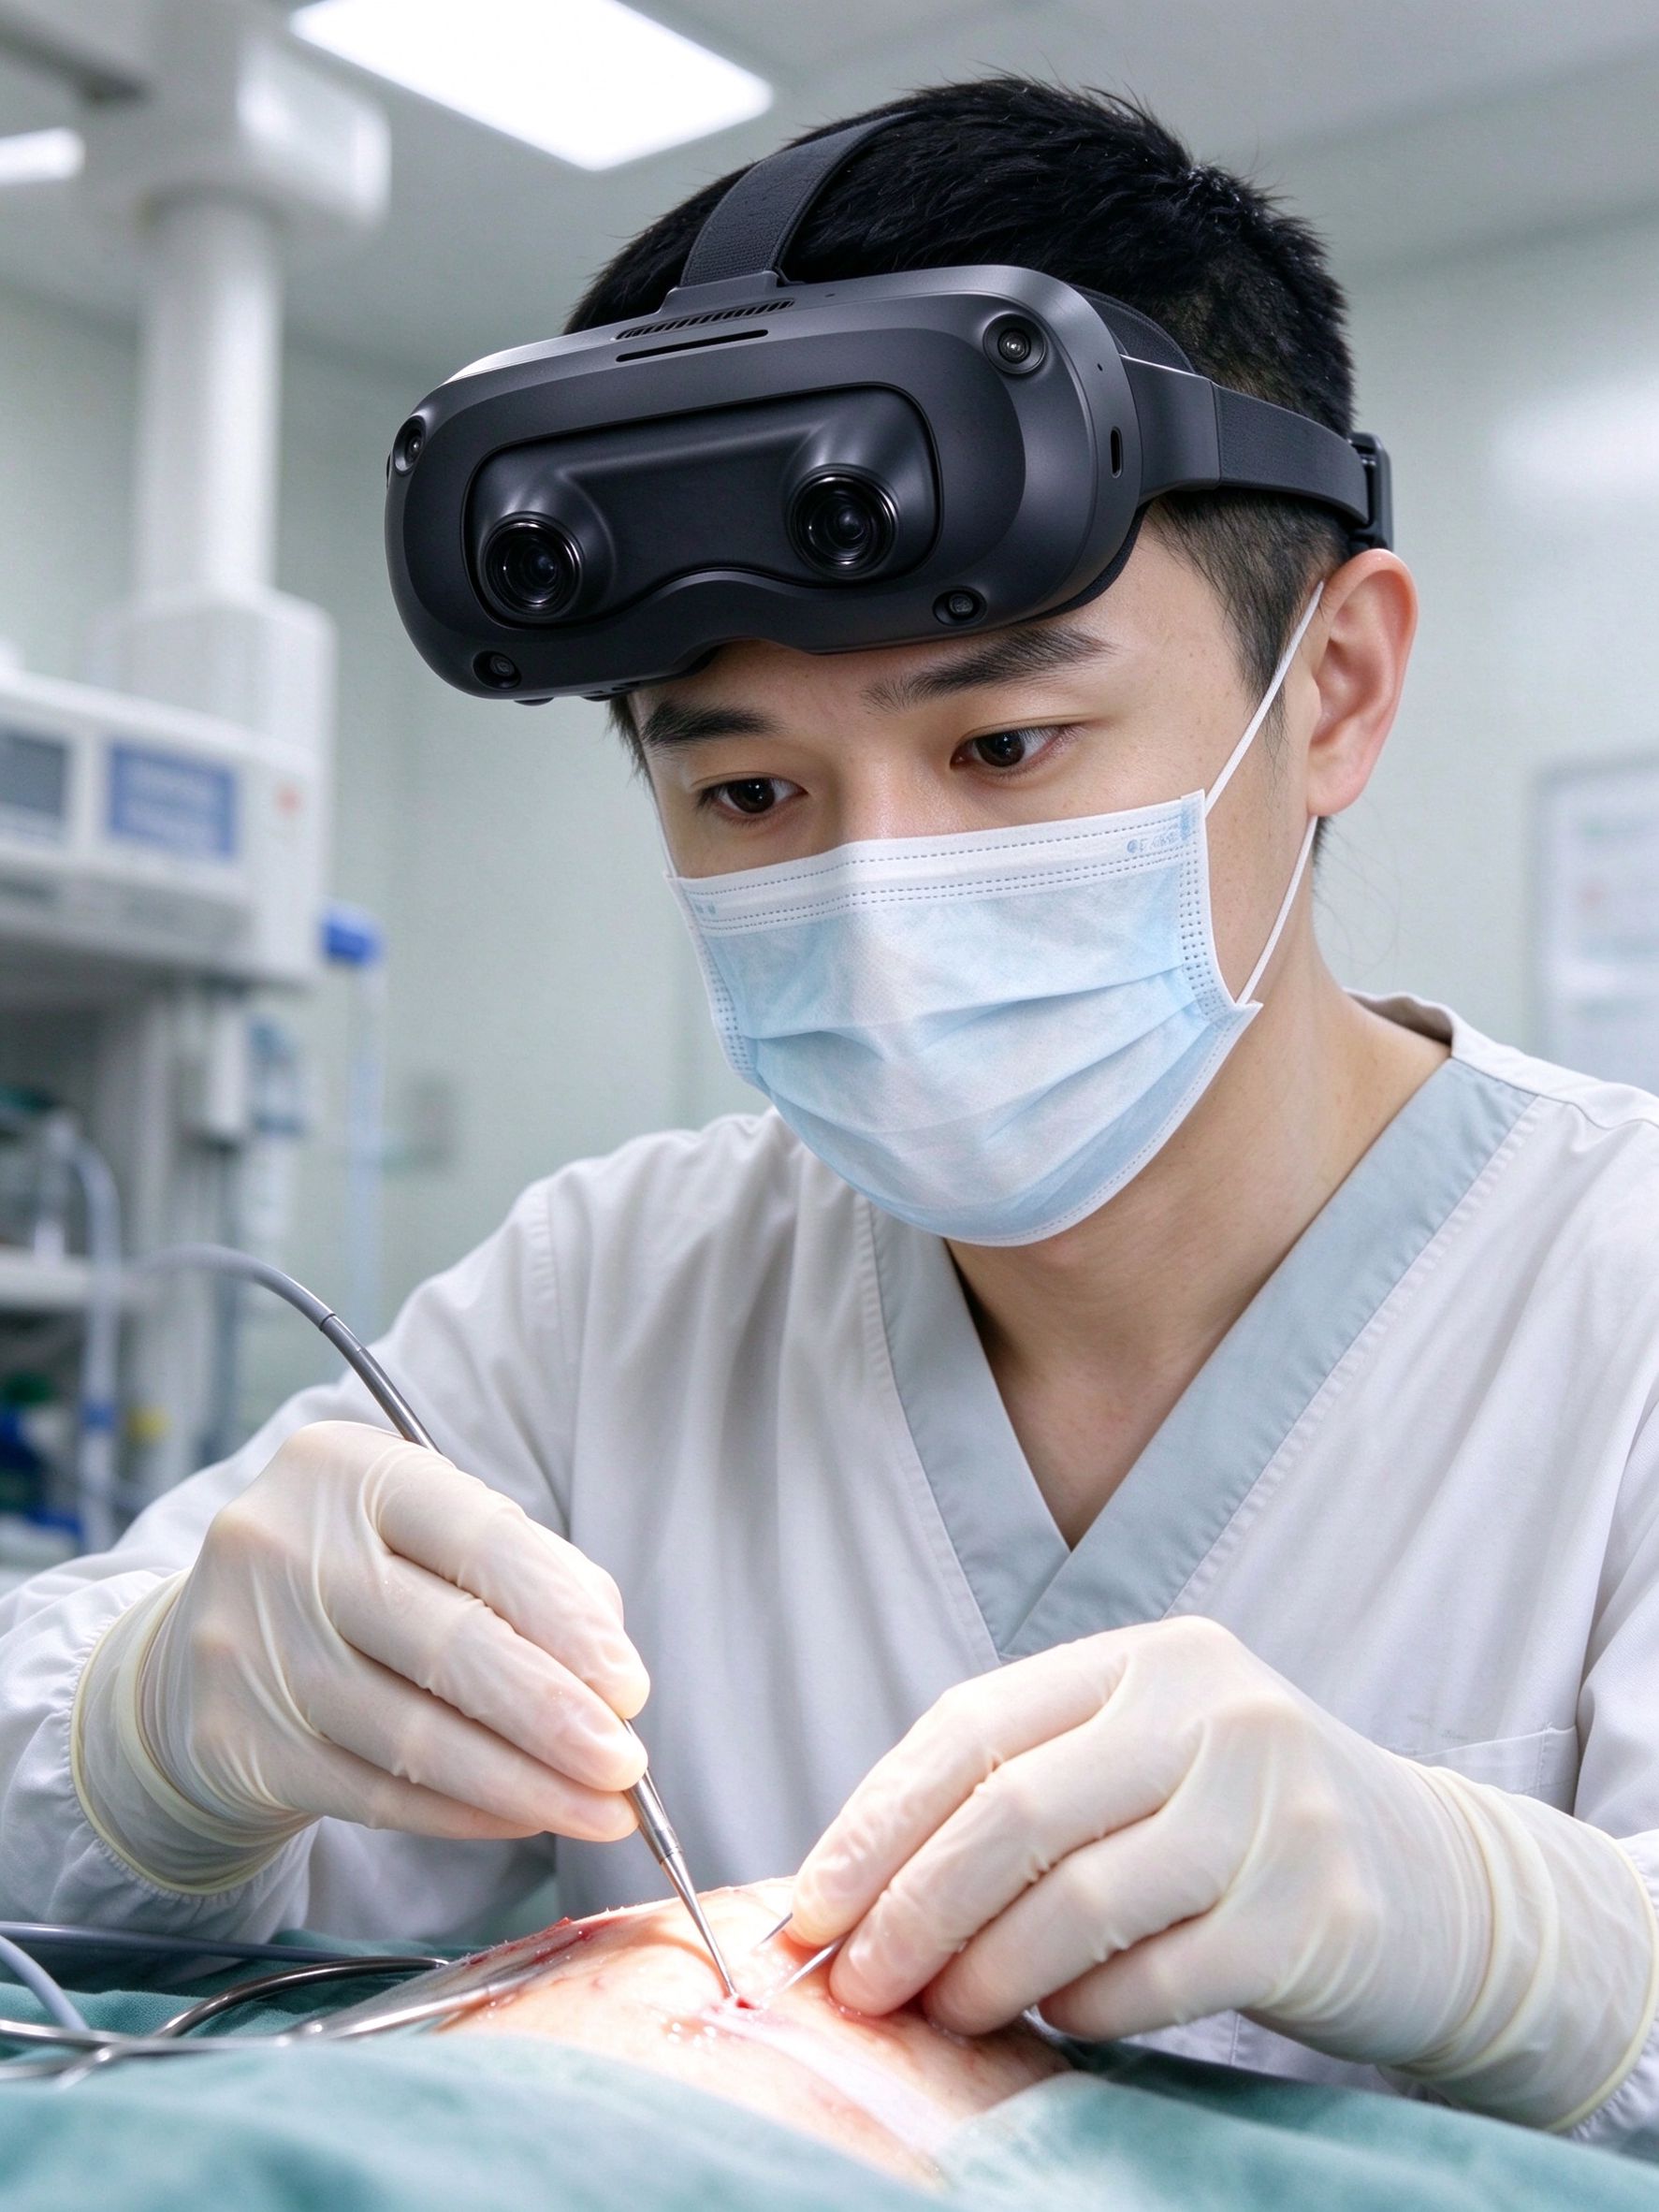
手术室Operating room质量门前置、自动结构化、机器质检 + 分层人工抽检 + 每次交付机器审计——把脏活累活做在交付之前,客户拿到的是干净、对齐、带语义的多模态数据。Quality gates up front, automated structuring, machine QC plus tiered human review and a machine audit on every delivery — clean, time-aligned, semantic multimodal data, not raw footage.
自动剔除空闲、低质、手部遮挡片段,同步校验、丢帧检测前置。Auto-rejects idle, low-quality and hand-occluded clips; sync and drop-frame checks up front.
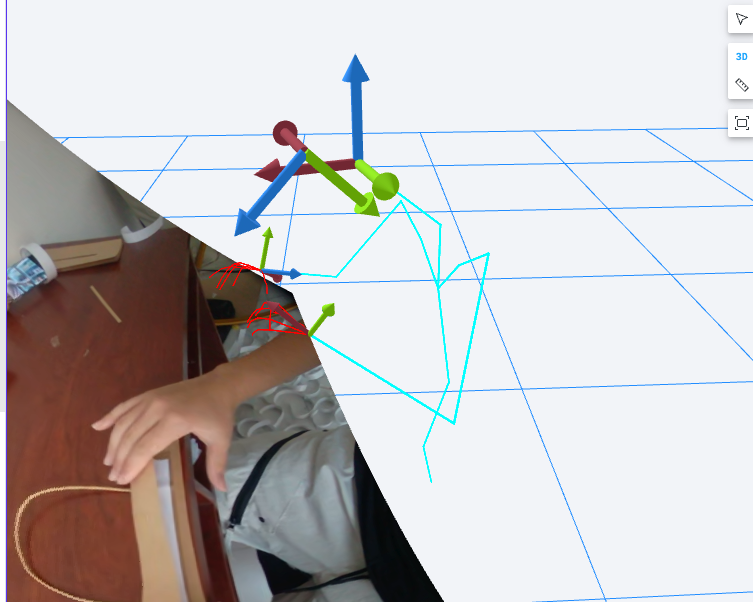
多目立体 + SLAM 恢复相机轨迹、场景几何与真深度流。Multi-view stereo + SLAM recover camera trajectory, scene geometry and true depth.
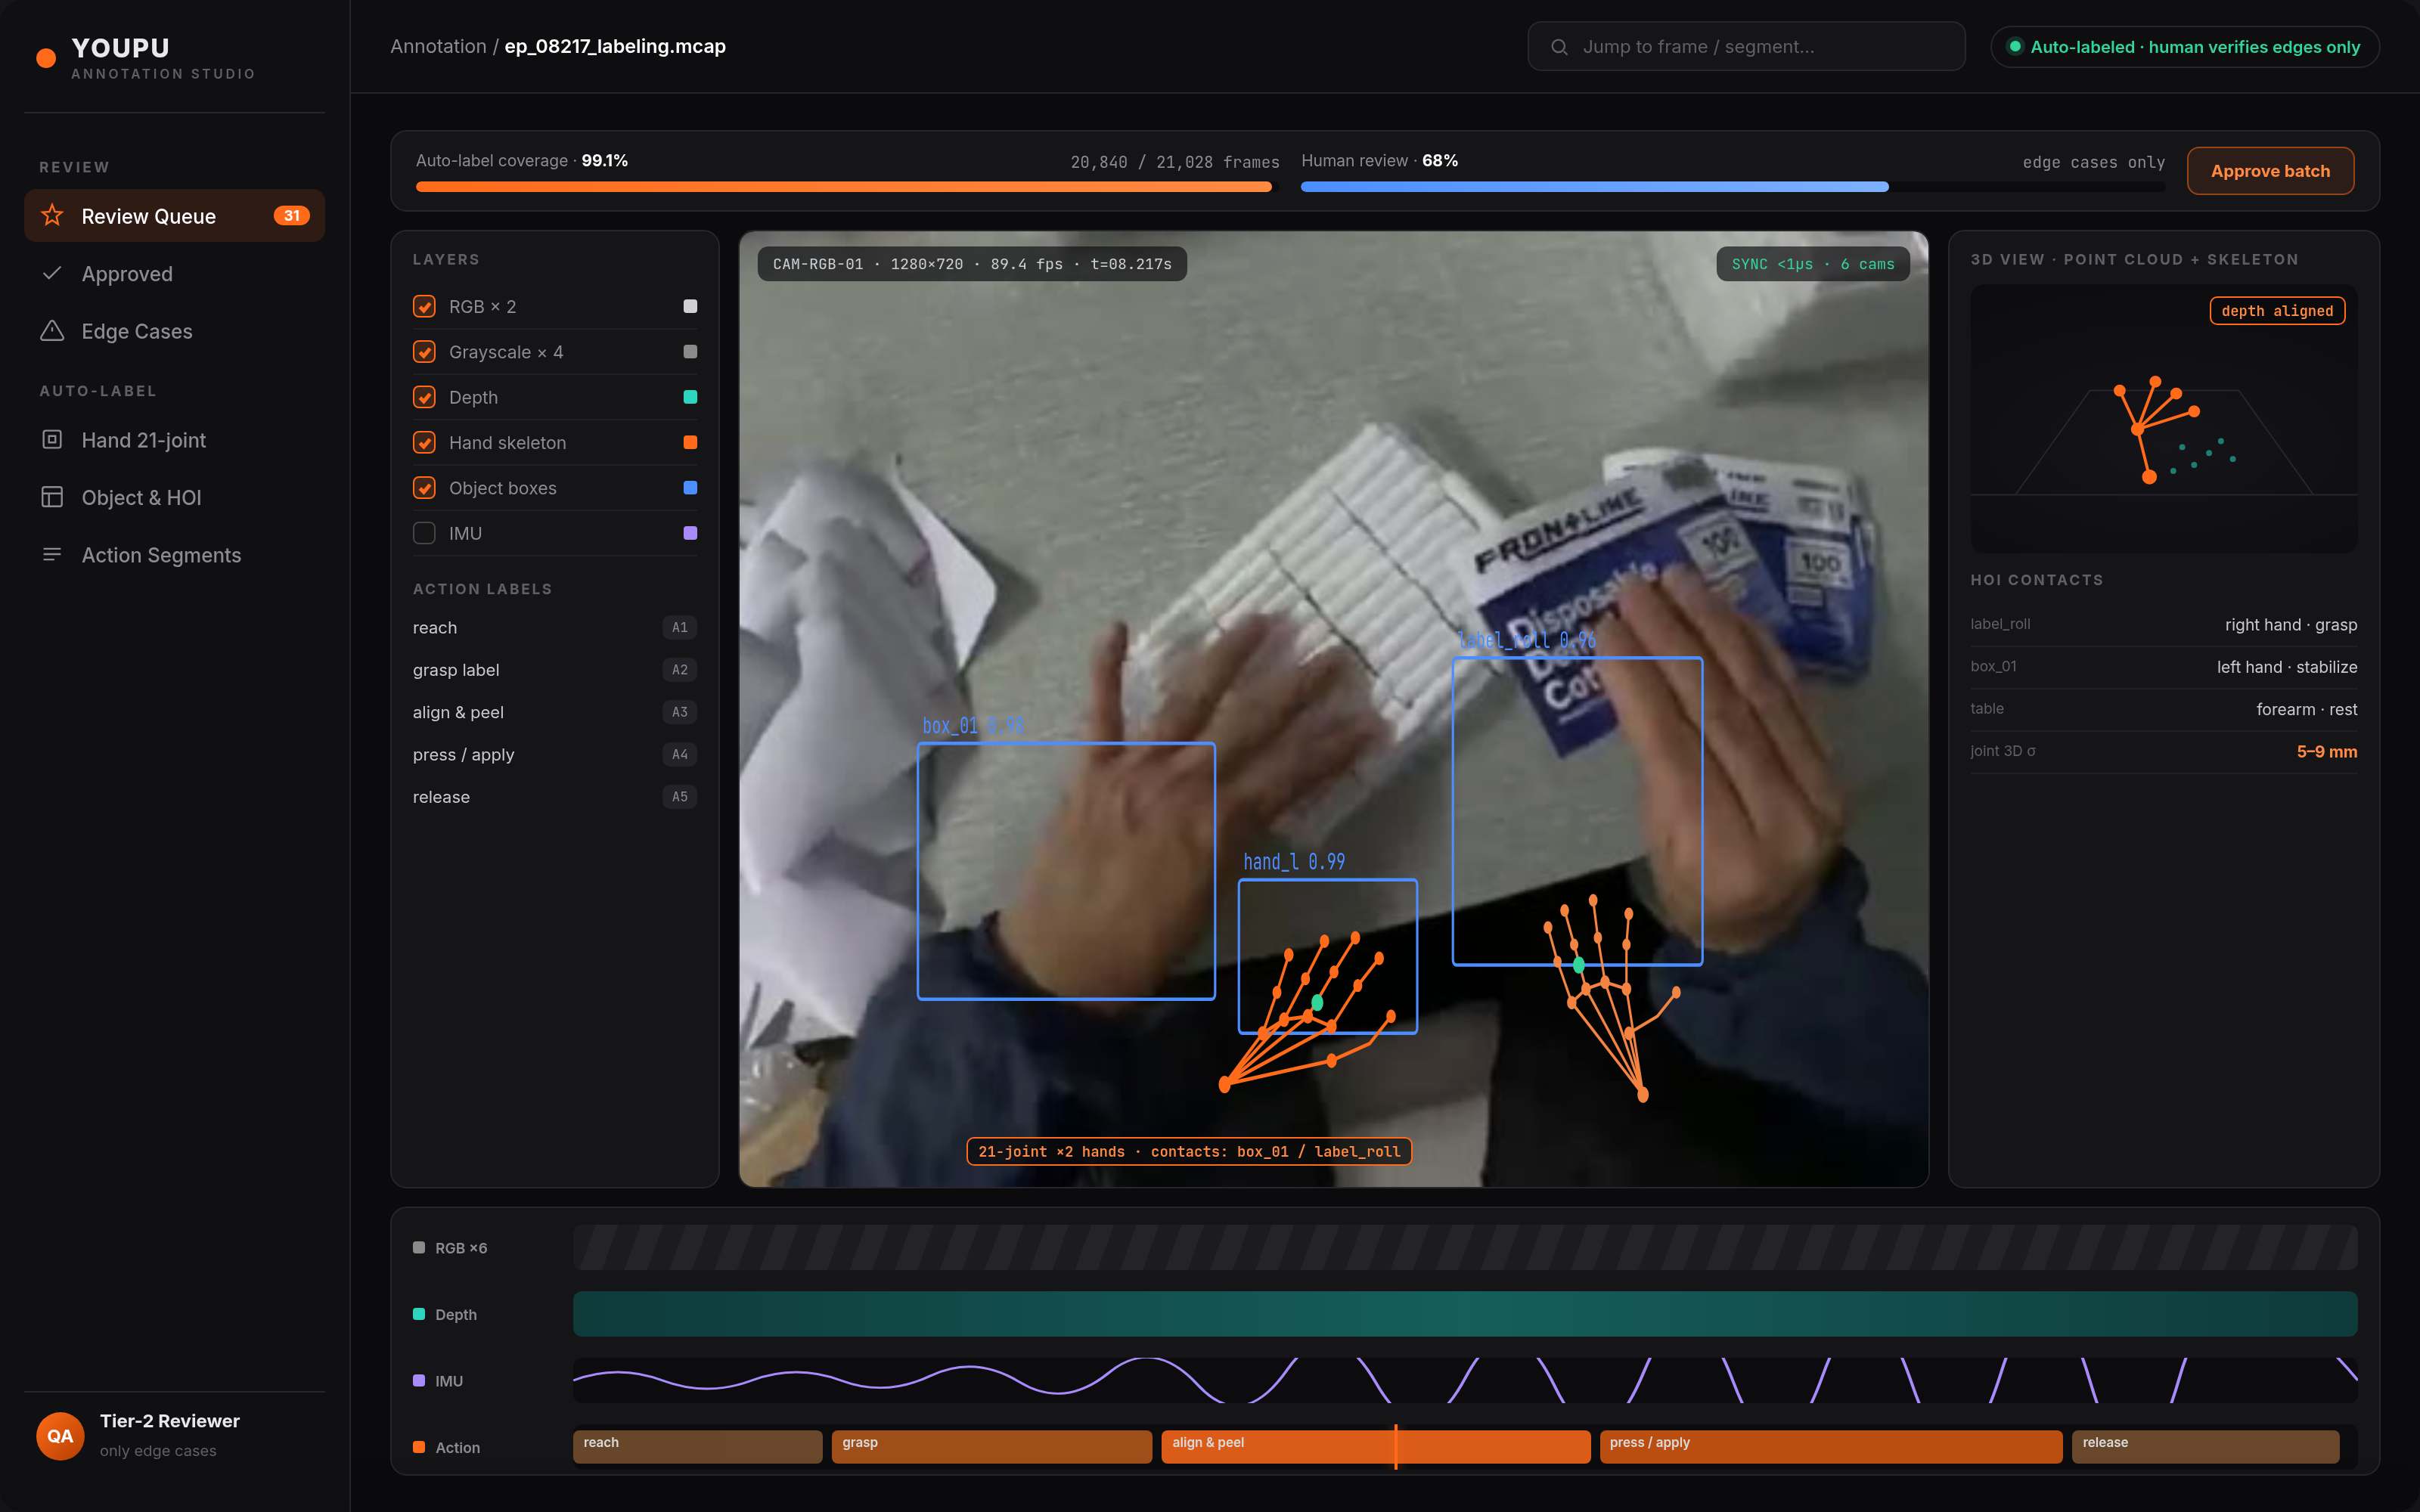
手部 / 上半身姿态、3D 轨迹、物体检测分割、IMU、PII 脱敏。Hand/upper-body pose, 3D trajectories, object detection & segmentation, IMU, PII masking.
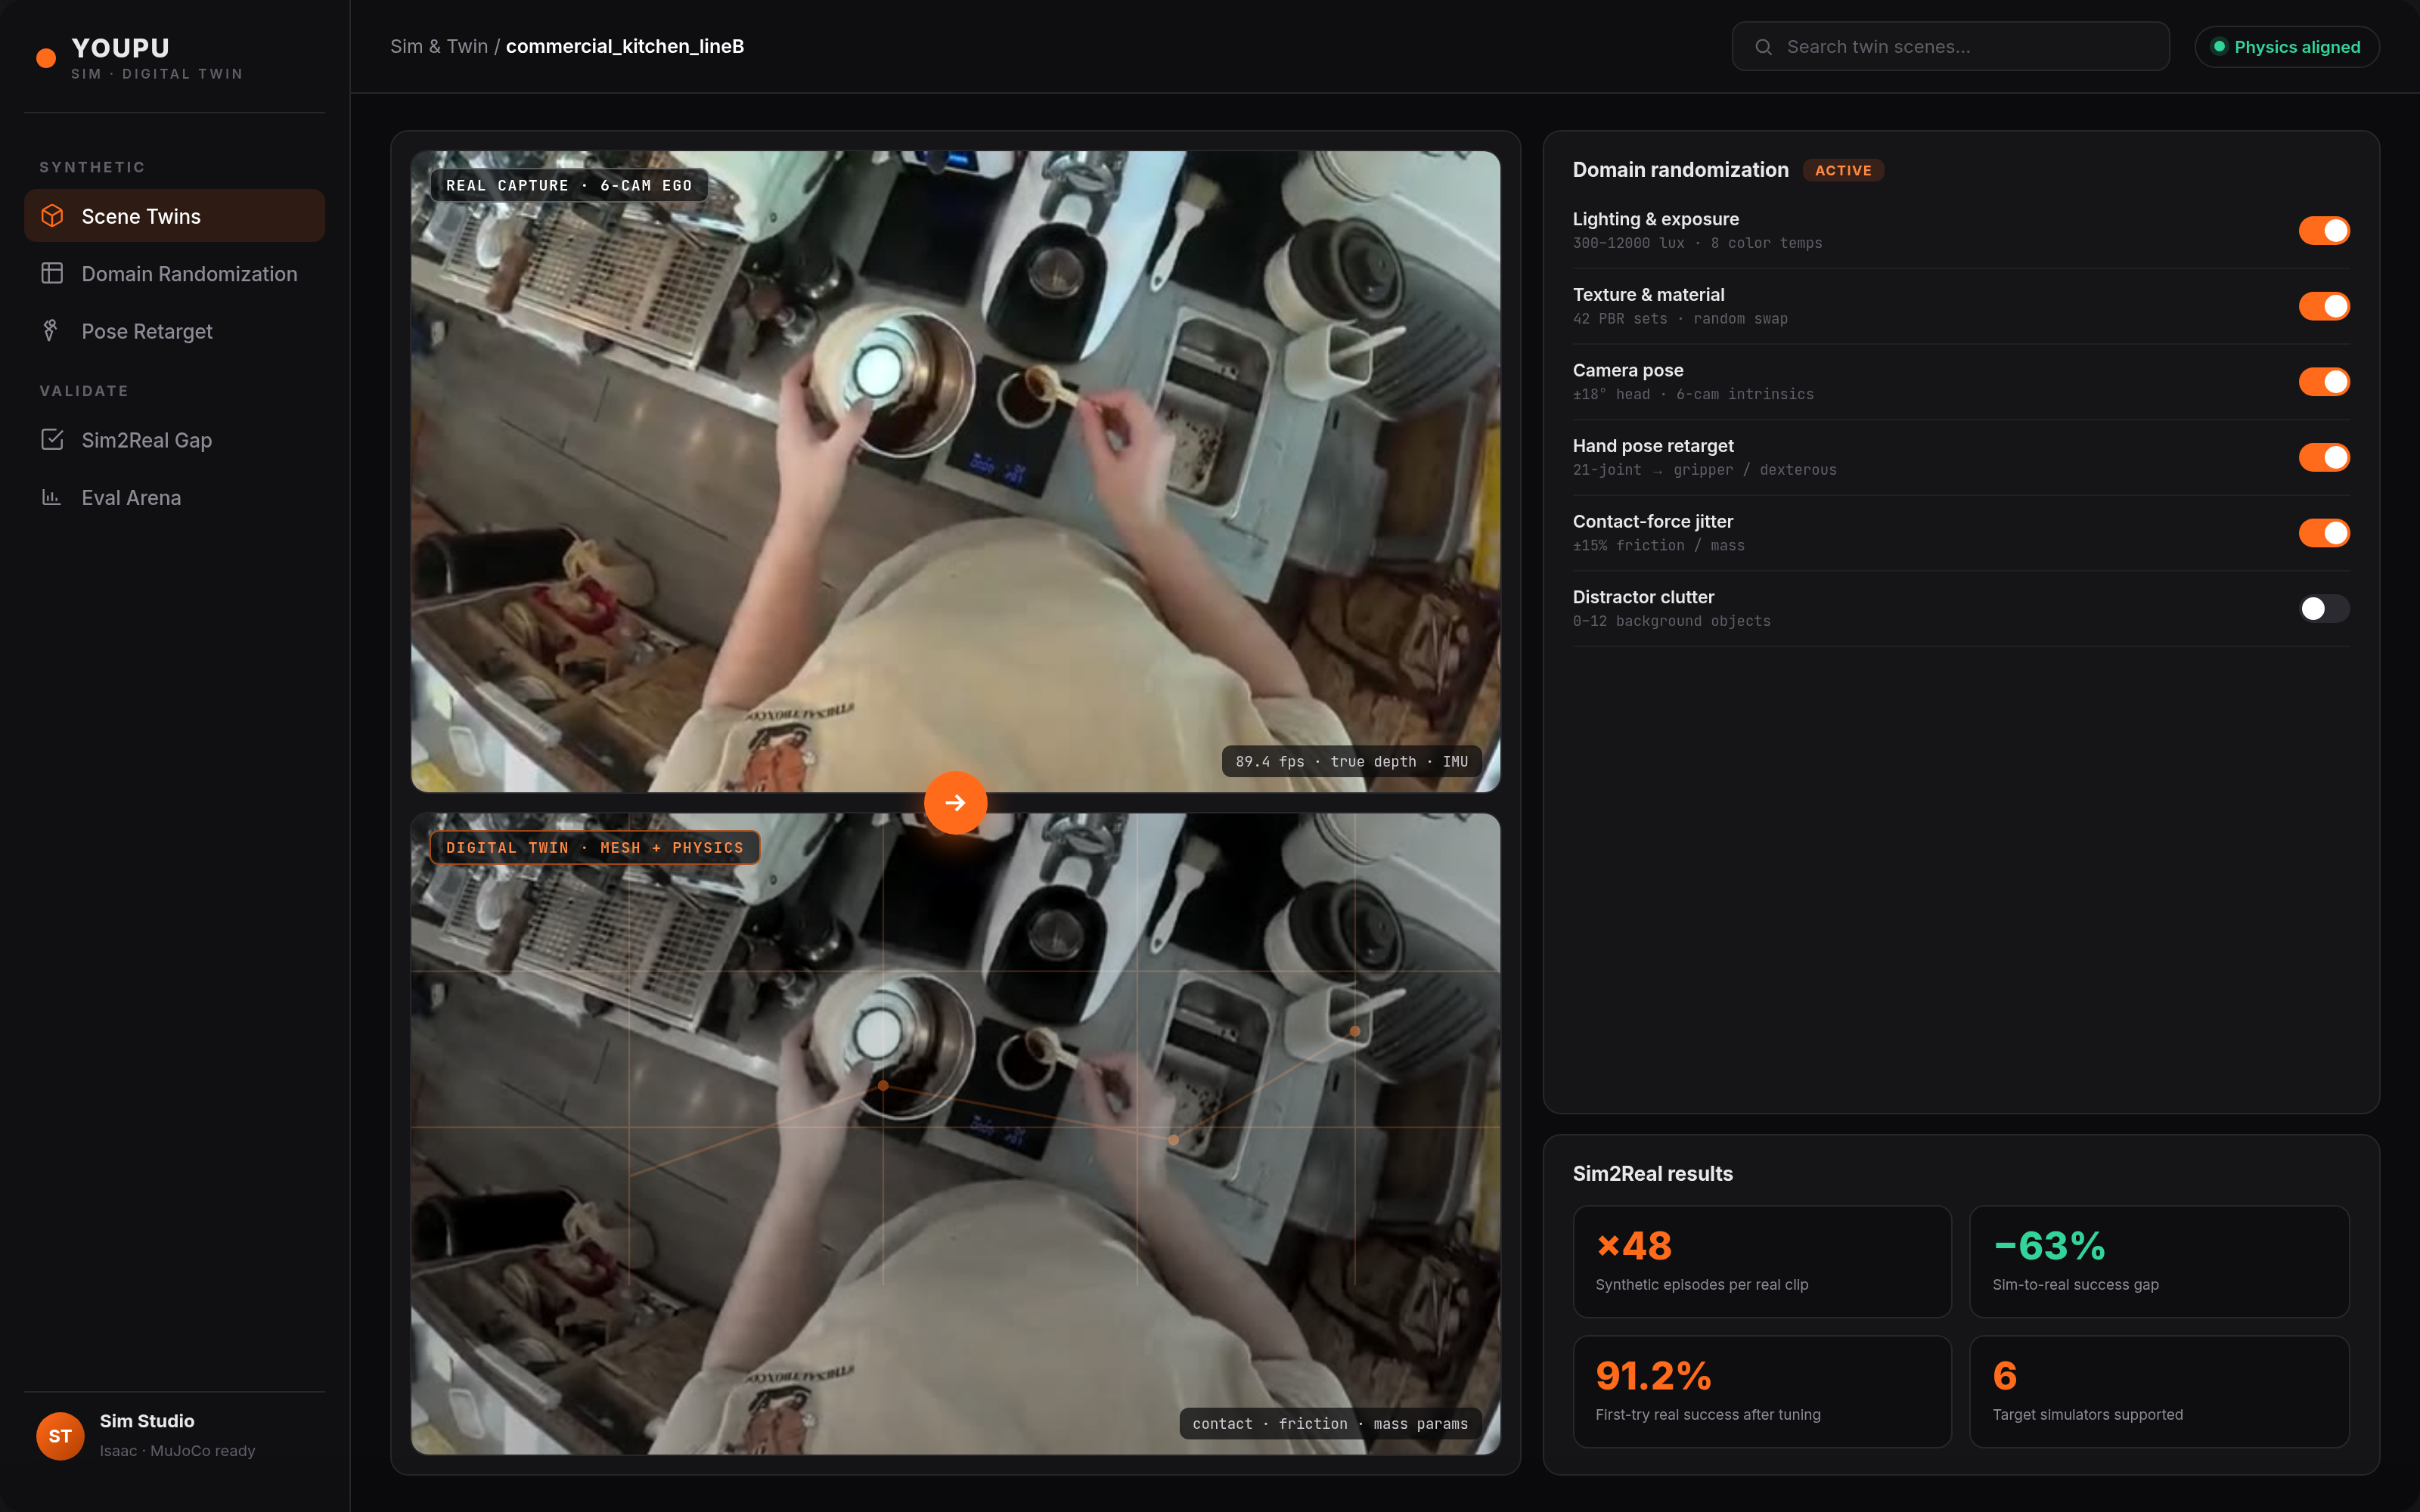
数字孪生重建与物理参数对齐,支持合成数据与仿真训练。Digital-twin reconstruction and physics alignment for synthetic data and sim training.
MCAP 打包:同步 3D 视频 + 真深度 + 元数据 + 时间动作标签。MCAP packages: synced 3D video + true depth + metadata + temporal action labels.

六目硬同步 + 立体校正,输出对齐的多视角与深度。Hardware-synced six views with rectification, aligned multi-view and depth.

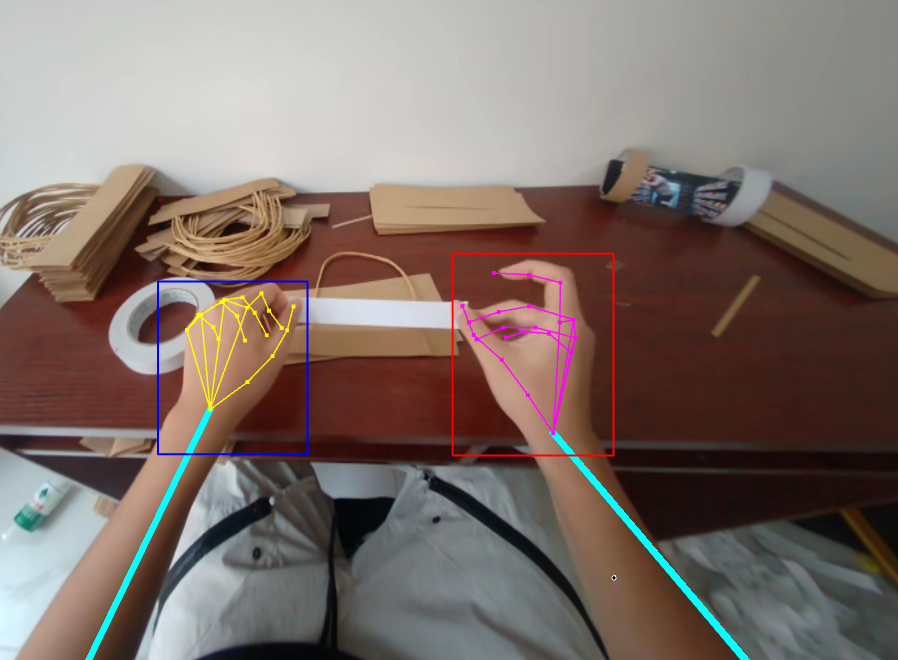
21 关节手部骨架、人–物交互与接触关系。21-joint hand skeleton, human–object interaction and contacts.

毫米级相机轨迹、上半身关节与速度日志。Millimeter camera trajectory, upper-body joints and velocity logs.

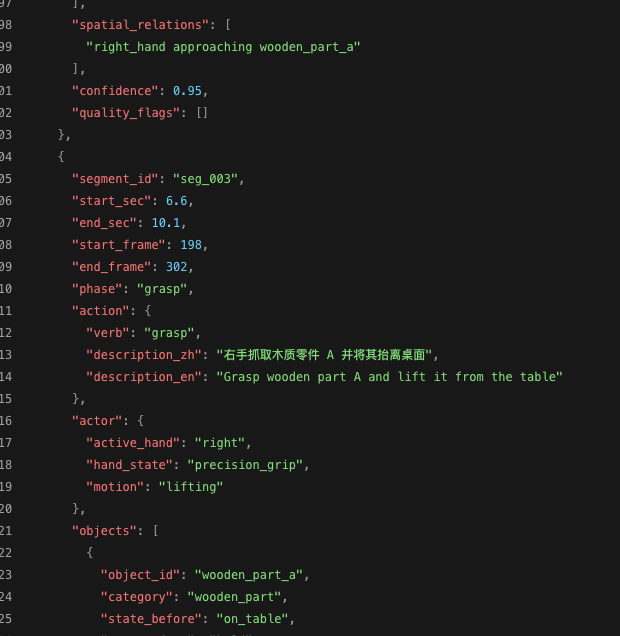
活动标签、注意力项、动作分段,输出机器可读 JSON / MCAP。Activity labels, attention items, action segmentation as machine-readable JSON / MCAP.

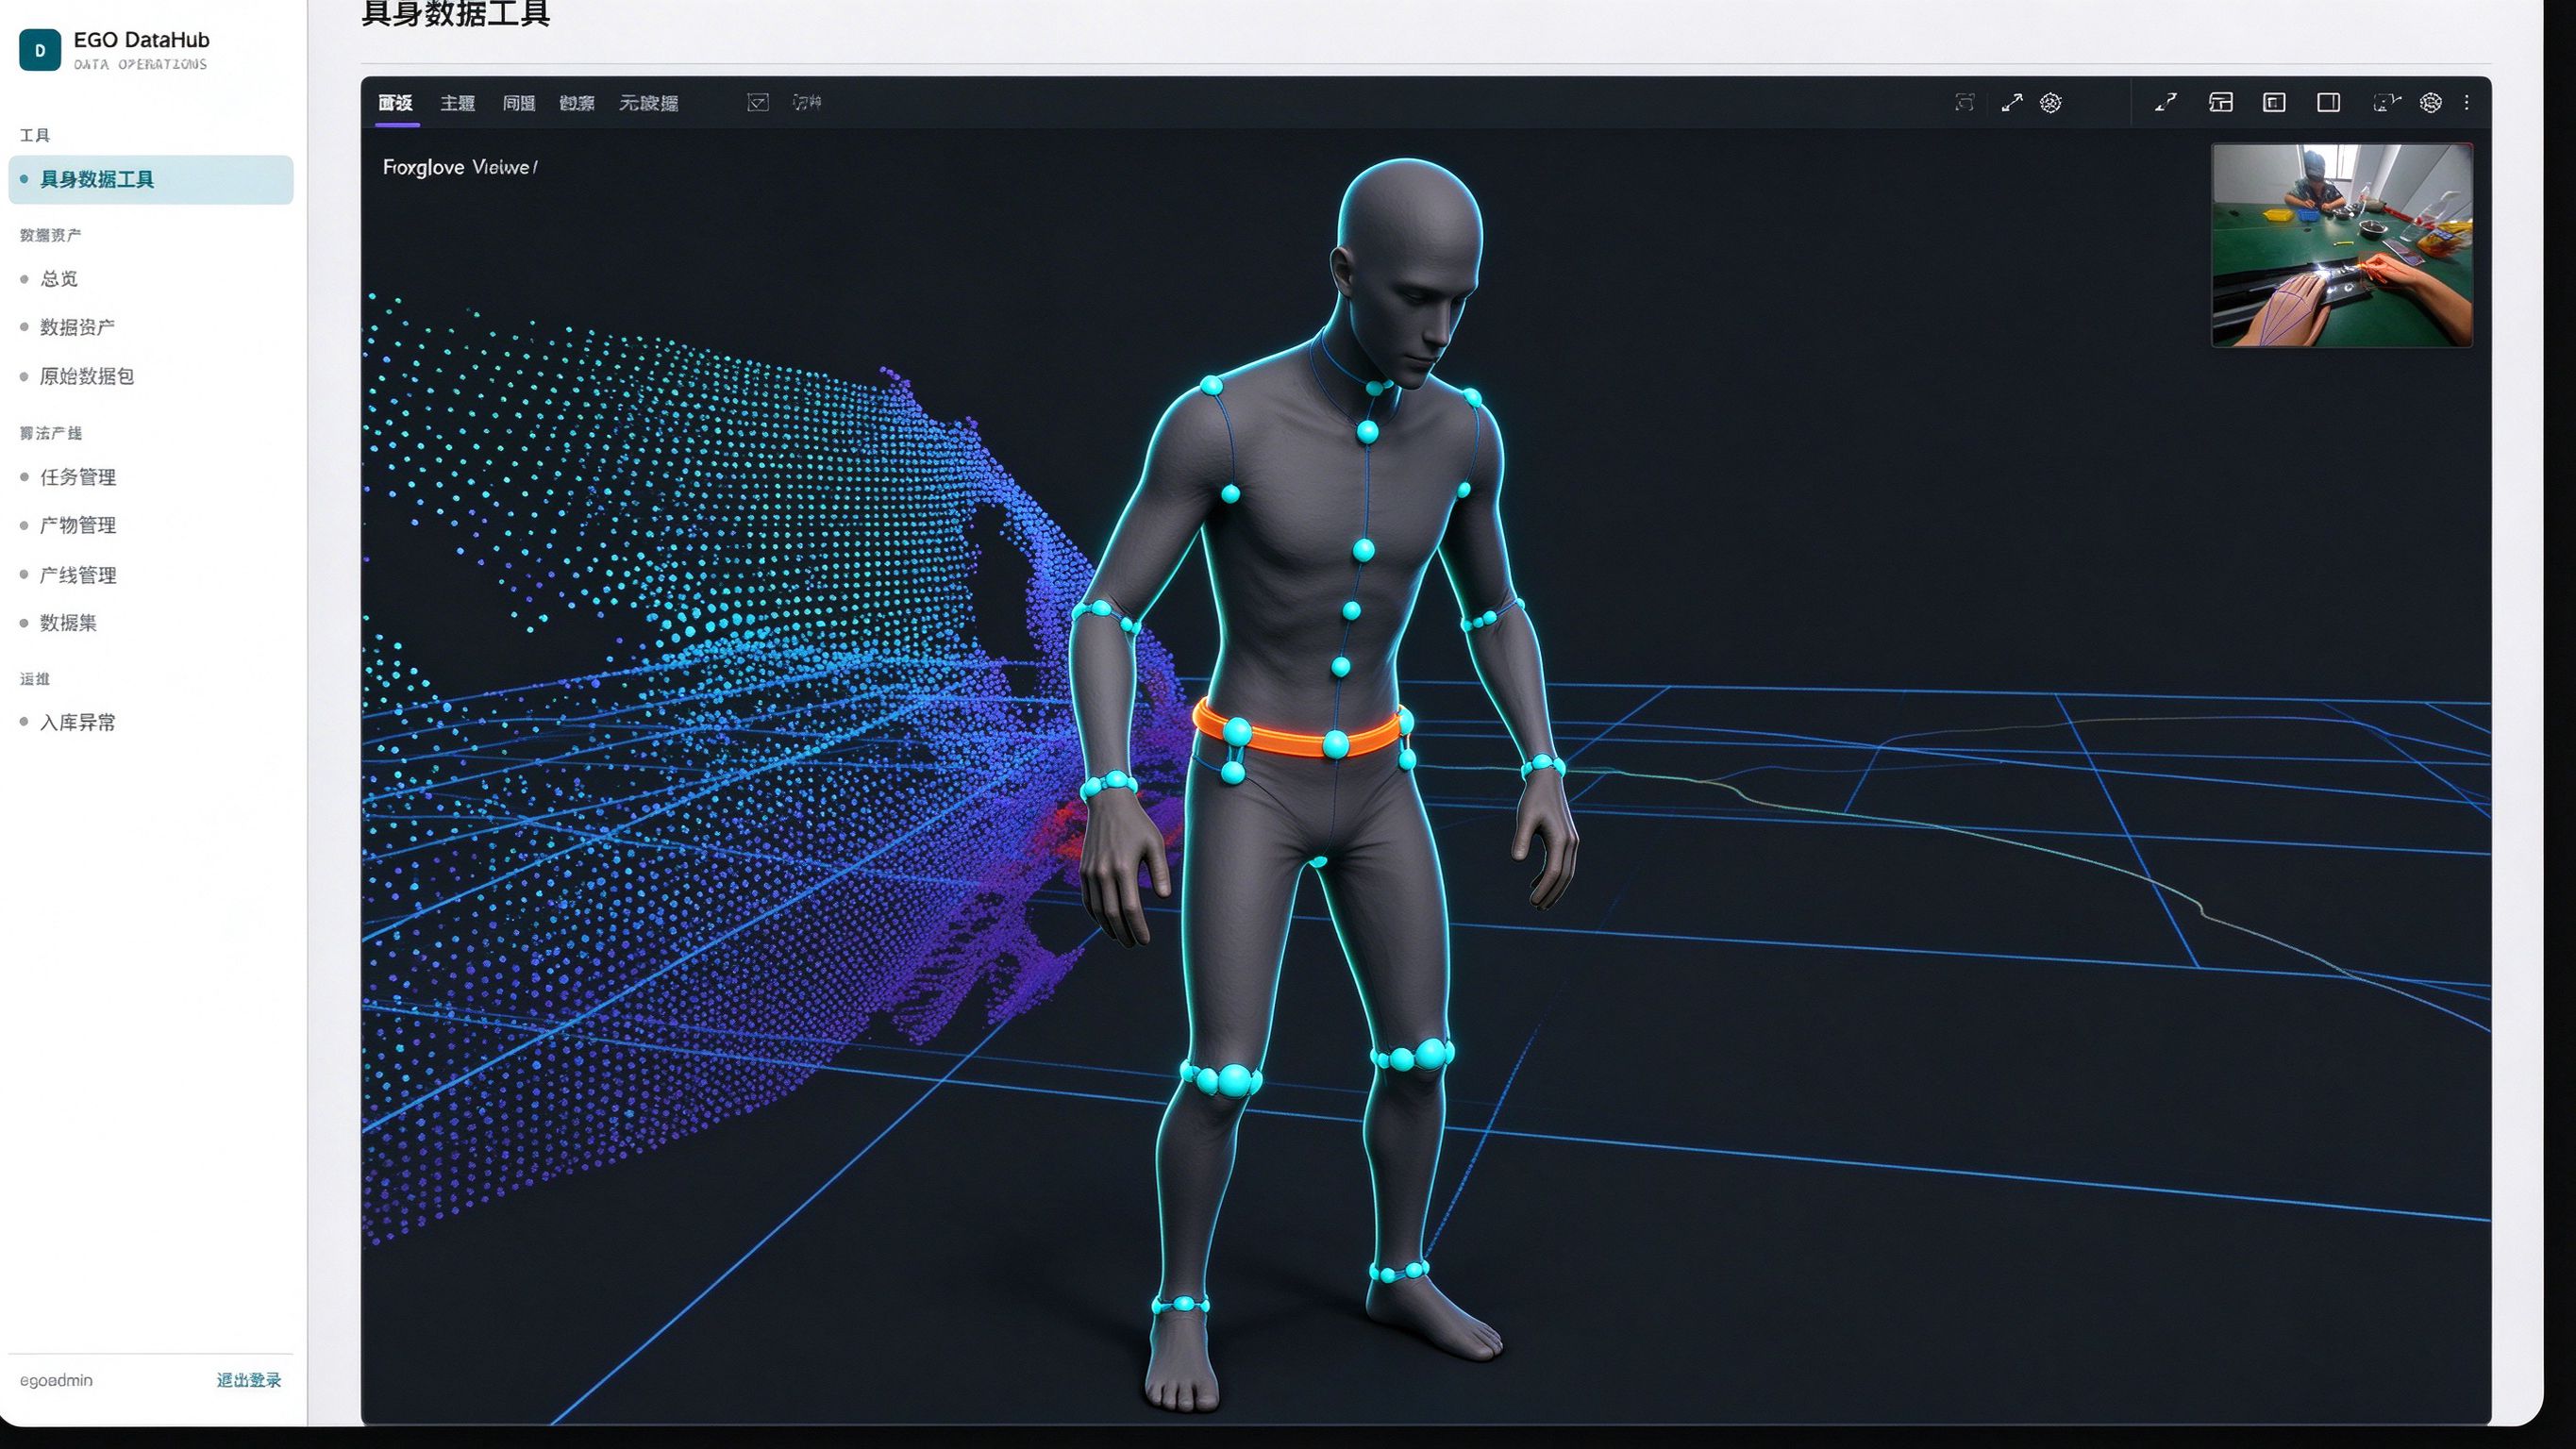
在双手之外,管线进一步输出躯干、骨盆与全身骨架:以 SMPL/SMPL-X 参数化蒙皮人体与 MANO 手模表达,关节点、点云、网格与轨迹在 Foxglove 内直接三维预览,全身动作与接触关系一目了然。Beyond the hands, the pipeline outputs the torso, pelvis and full skeleton as SMPL/SMPL-X parametric bodies with MANO hands; joints, point cloud, mesh and trajectory preview in 3D directly inside Foxglove.
每一段数据都可按需叠加以下结构化数据层,构成物理 AI 所需的完整观测。Each clip can be enriched on demand with the structured layers below — the full observation Physical AI needs.
手部与上半身逐帧骨架,高保真运动学。Frame-by-frame hand & upper-body skeletal kinematics.
高频实时深度,支撑避障与精准抓取。High-frequency real-time depth for obstacle avoidance & grasp.
高频线加速度与角速度,物理感知遥测。High-rate linear acceleration & angular velocity telemetry.
自动模糊人脸、Logo 与敏感信息,企业合规。Auto-blur faces, logos & sensitive info; enterprise-ready.
逐帧工具与工件检测、分割与跟踪。Per-frame tool/object detection, segmentation & tracking.
摄影测量重建、接触力与加速度,供仿真。Photogrammetry, contact forces & acceleration for sim.
100 段真实任务、双目 VST、21 关节手部实测;SLAM 轨迹以机械臂 GT 与 AprilTag-PnP 视觉 GT 为基准。Internal benchmark over 100 real tasks, stereo VST, 21-joint hands; SLAM benchmarked against arm GT and AprilTag-PnP visual GT.
100 段任务均值,std 3.0%Mean over 100 tasks, std 3.0%
可信关键点均值,std 1.7pxTrusted-keypoint mean, std 1.7 px
30–50cm,Stereo-PnP 推导30–50 cm, Stereo-PnP derived
机械臂 GT,ATE 约 6–9mmArm GT; ATE ≈ 6–9 mm
视觉 GT(AprilTag-PnP),0.4–0.8mVisual GT (AprilTag-PnP), 0.4–0.8 m
相对场景尺度,采用物理深度Relative to scene scale, physical depth
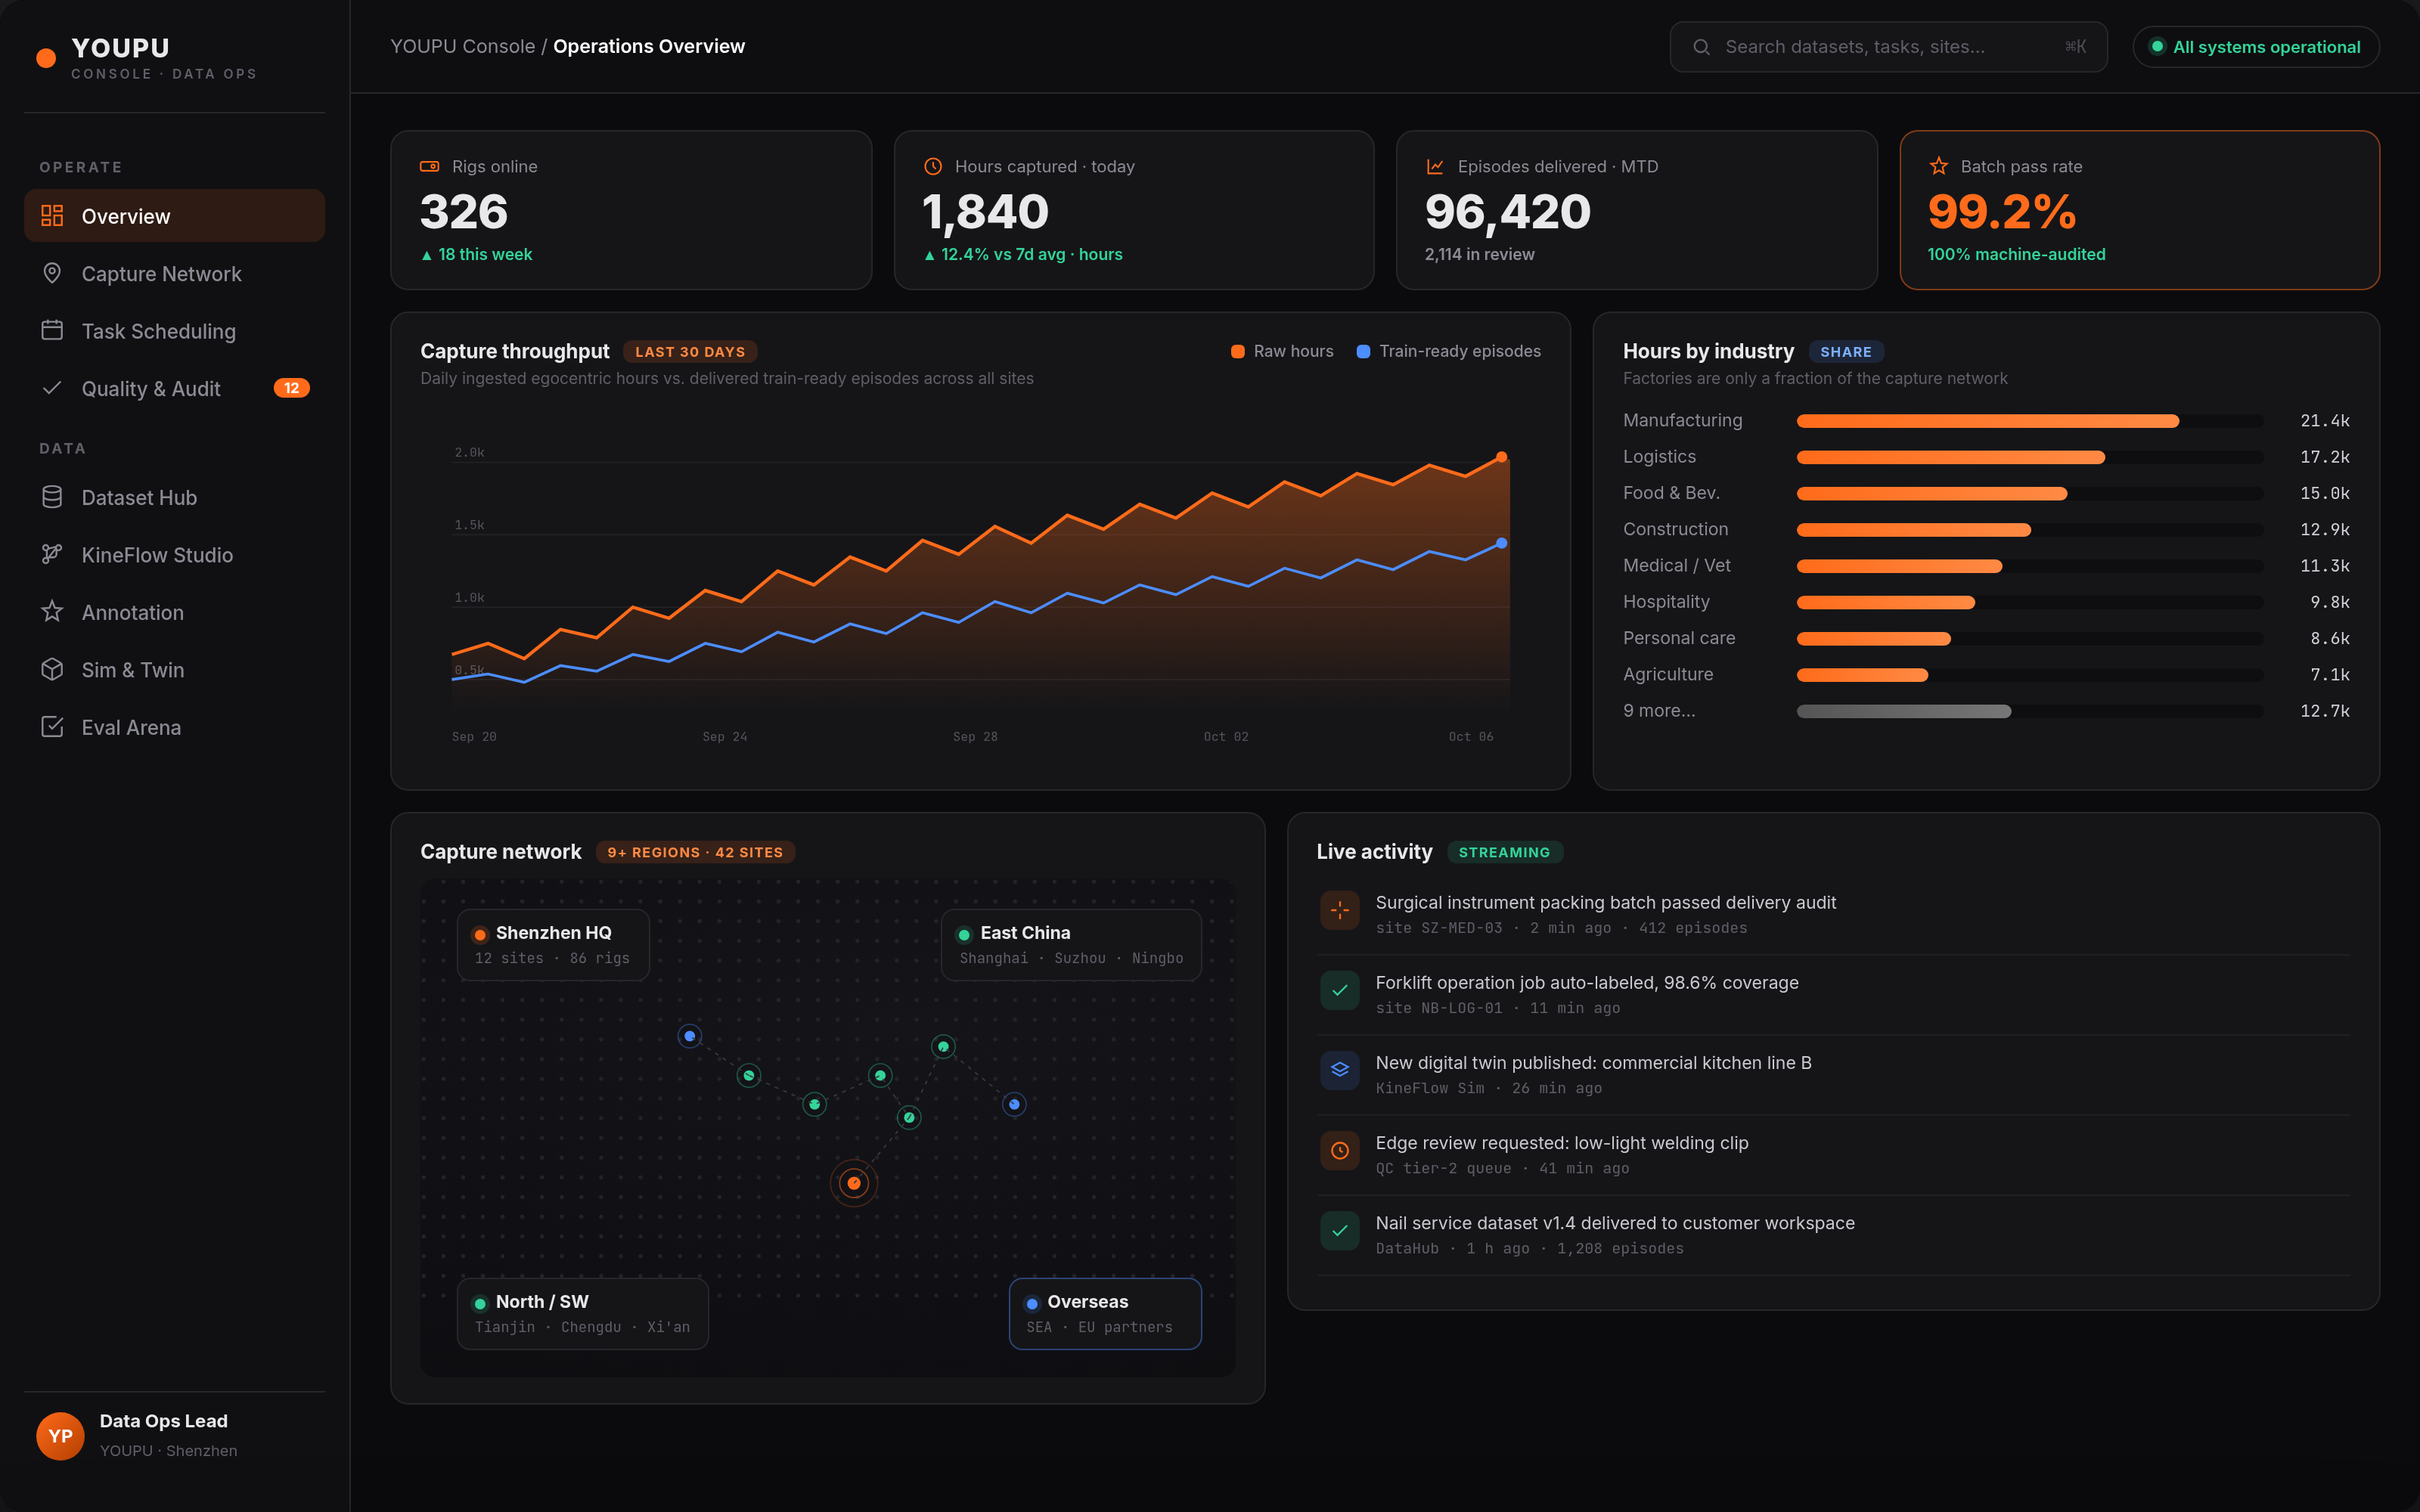
不只是硬件和数据:运营驾驶舱、采集任务网络、KineFlow 流水线、多模态标注、数据资产、仿真孪生与真机评测构成完整的数据基础设施,全部流程可观测、可追溯、可重跑。点击下方模块查看各平台界面。Beyond hardware and data: ops cockpit, capture network, the KineFlow pipeline, multimodal annotation, data assets, simulation & twin and real-robot evaluation form a complete, observable, traceable and re-runnable data infrastructure. Click a module to explore each interface.
六目头戴 · 手套夹爪 · 第三方接入Six-cam, glove, gripper, 3rd-party
质量门 · 3D 重建 · 标注 · 脱敏Quality gate, 3D, labels, PII
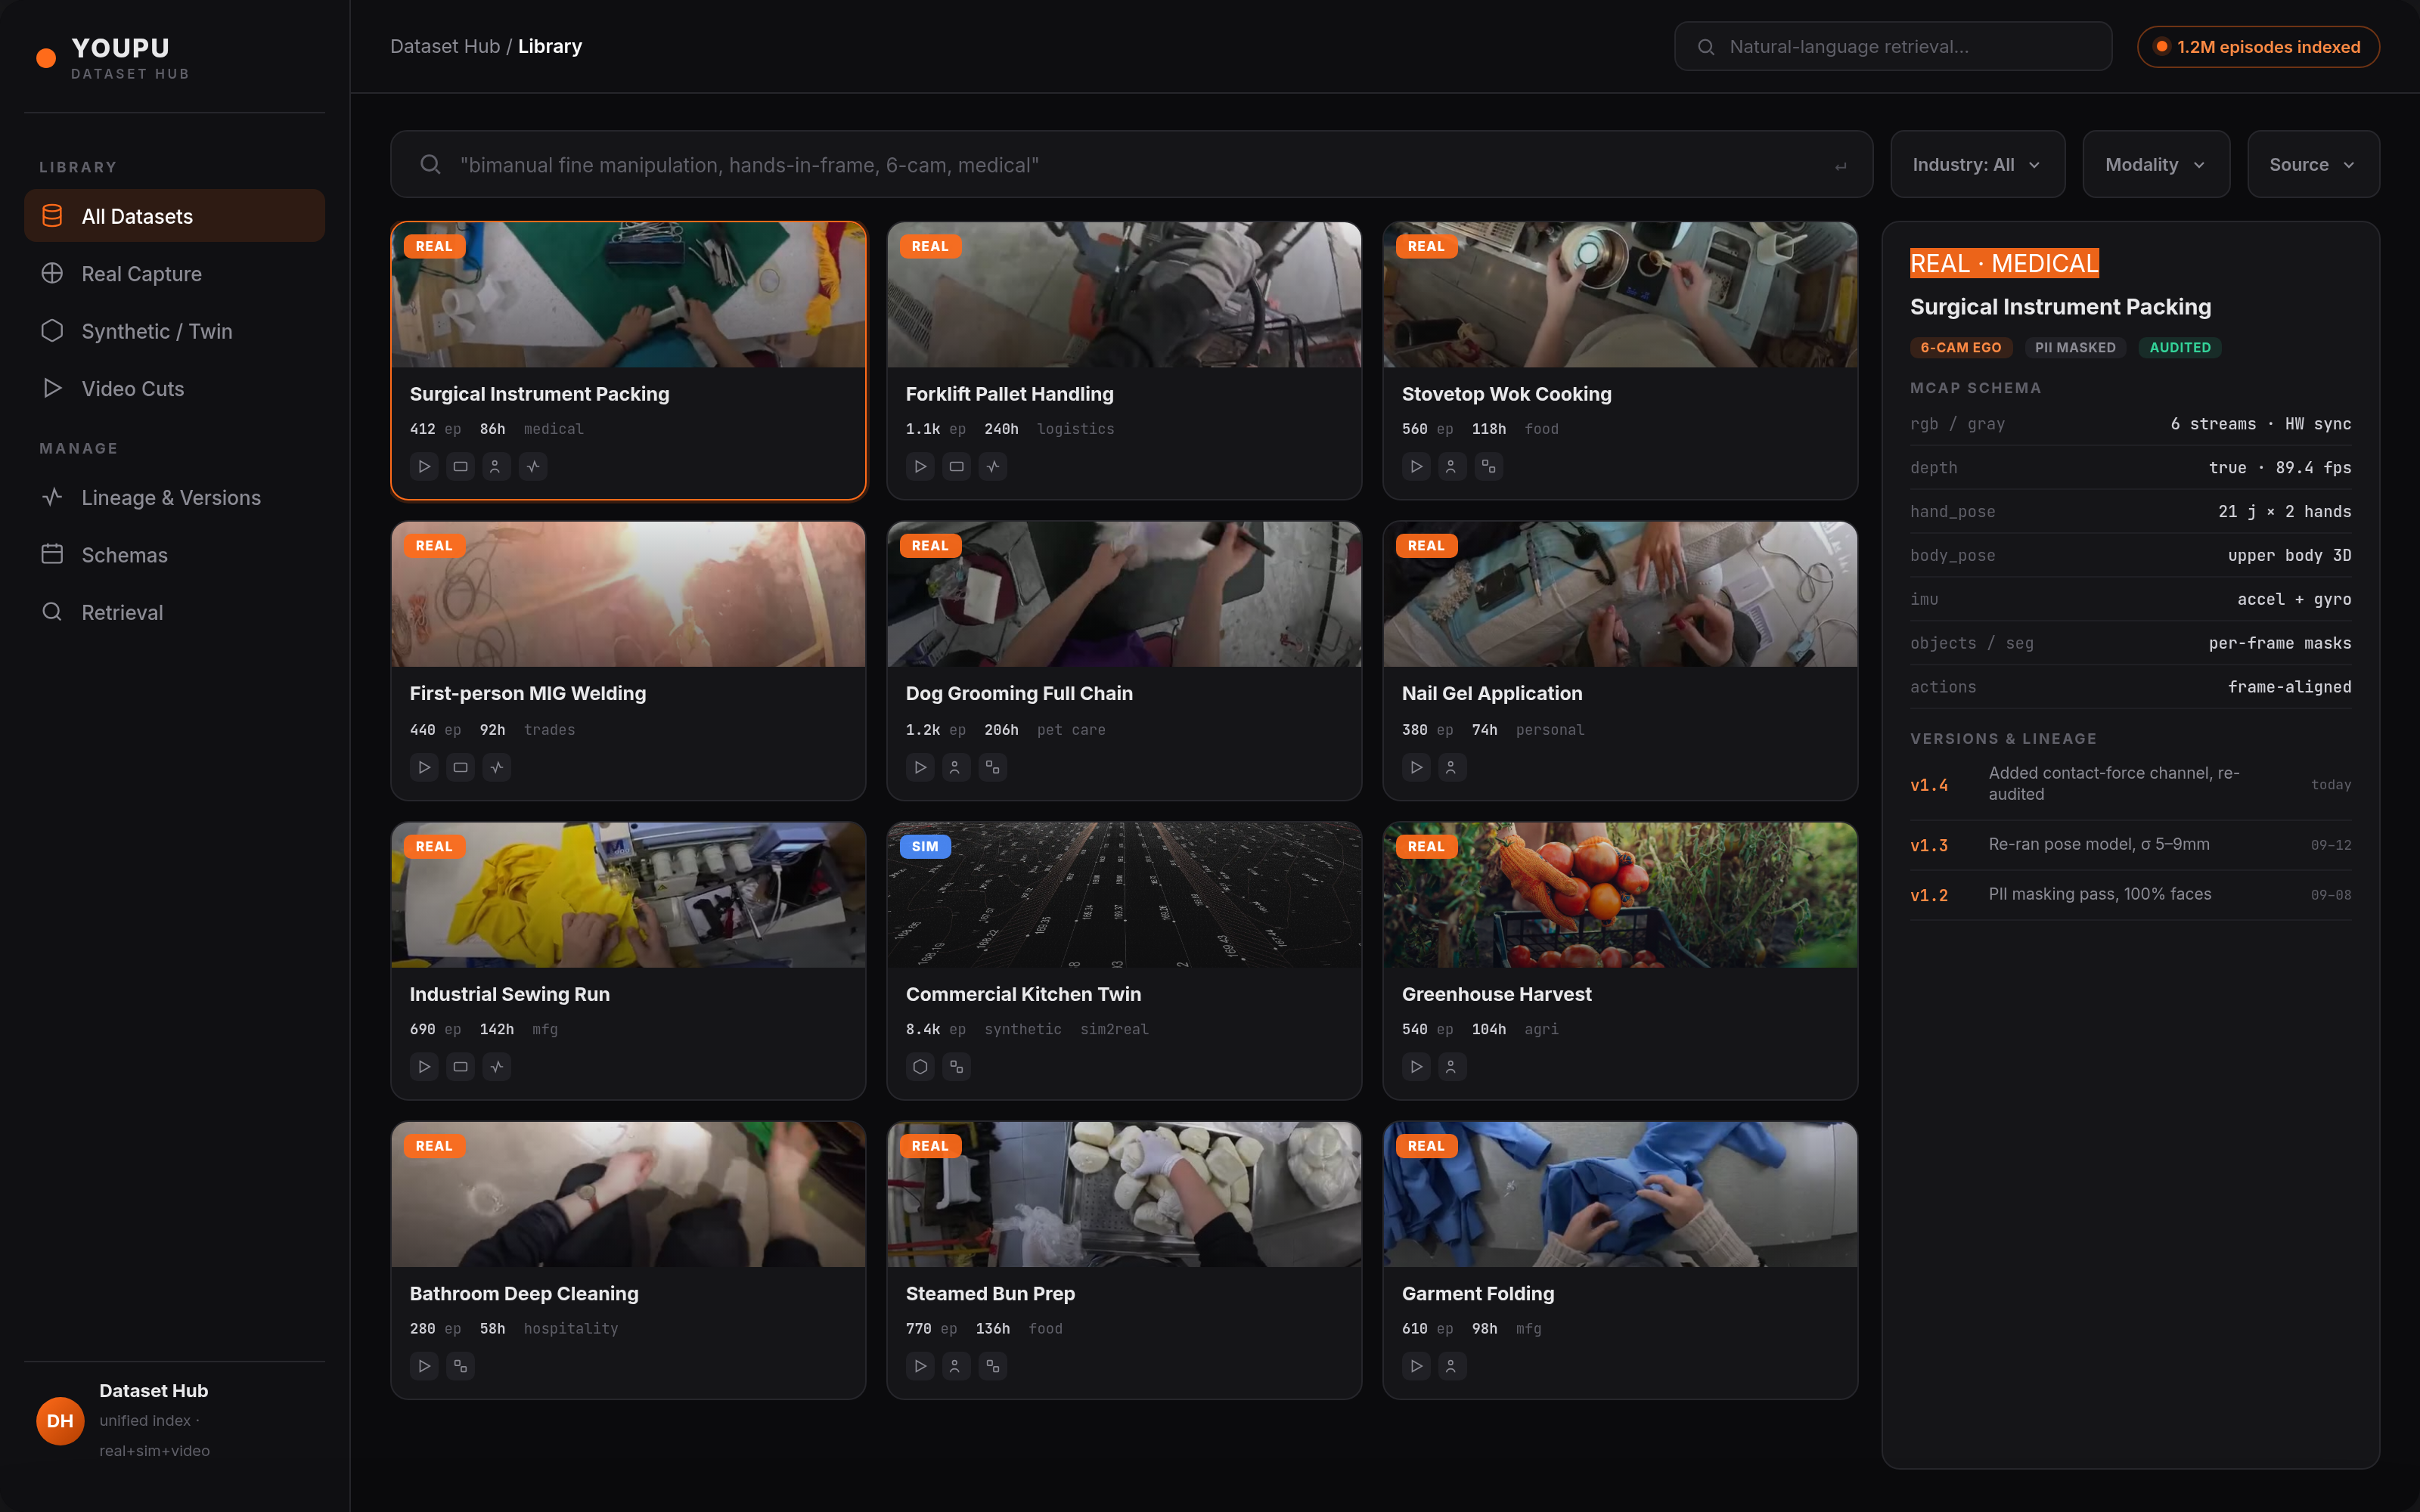
MCAP 湖 · 统一检索 · 版本血缘MCAP lake, search, lineage
VLA / 模仿学习 · 仿真合成扩增VLA, imitation, synthetic
真机竞技场 · 多维能力诊断Real-robot arena, diagnosis
API / SDK · 私有化部署API / SDK, private deploy
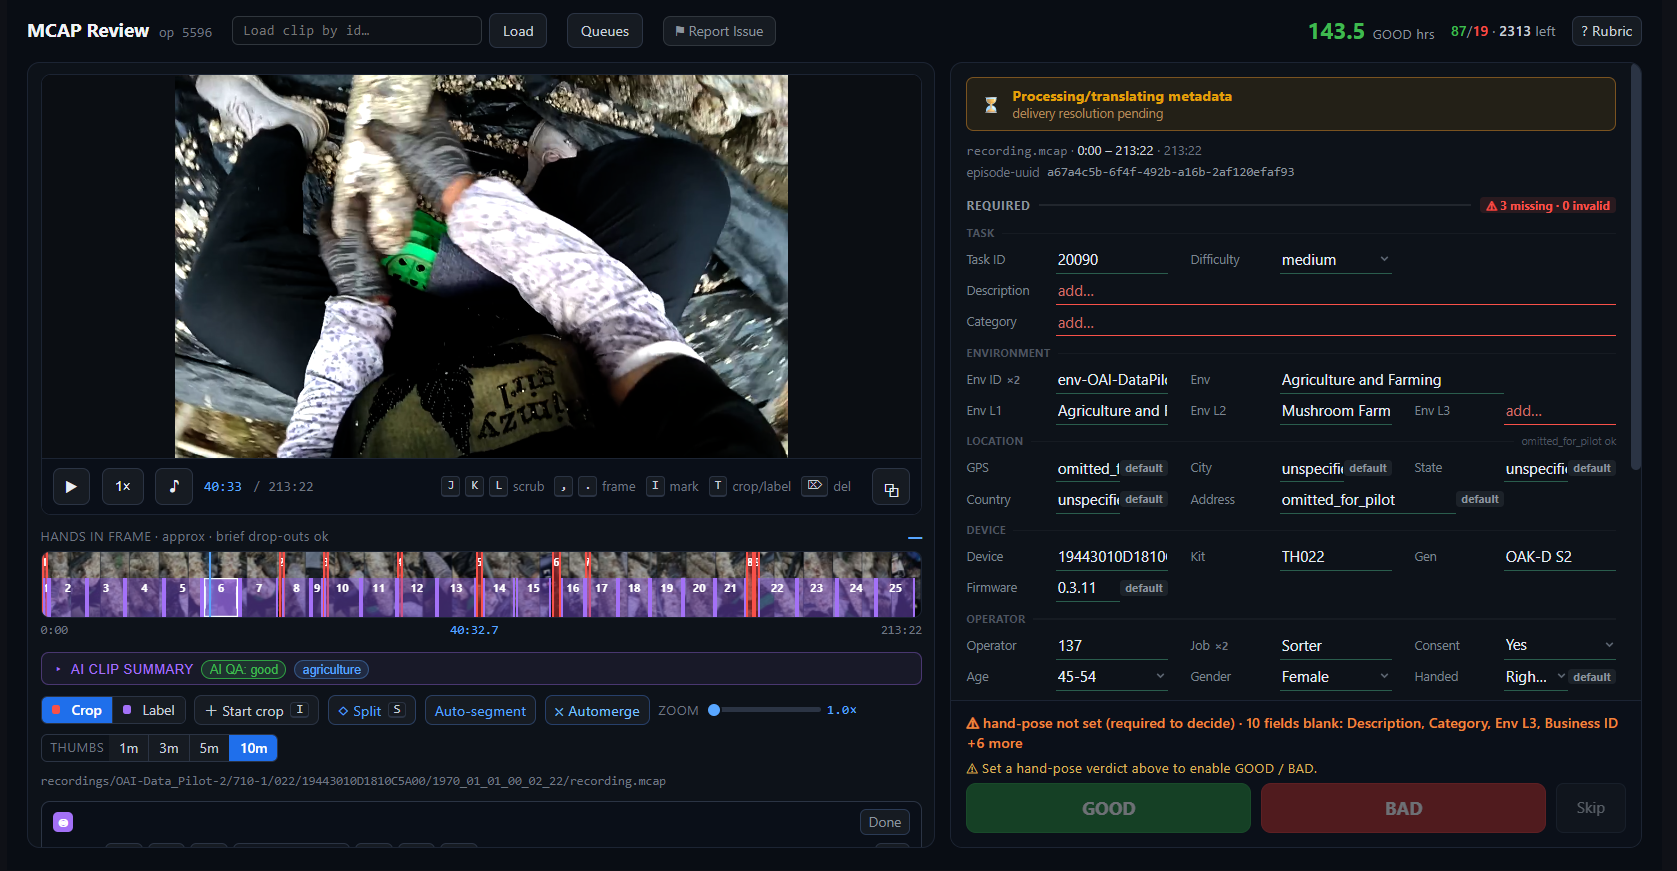
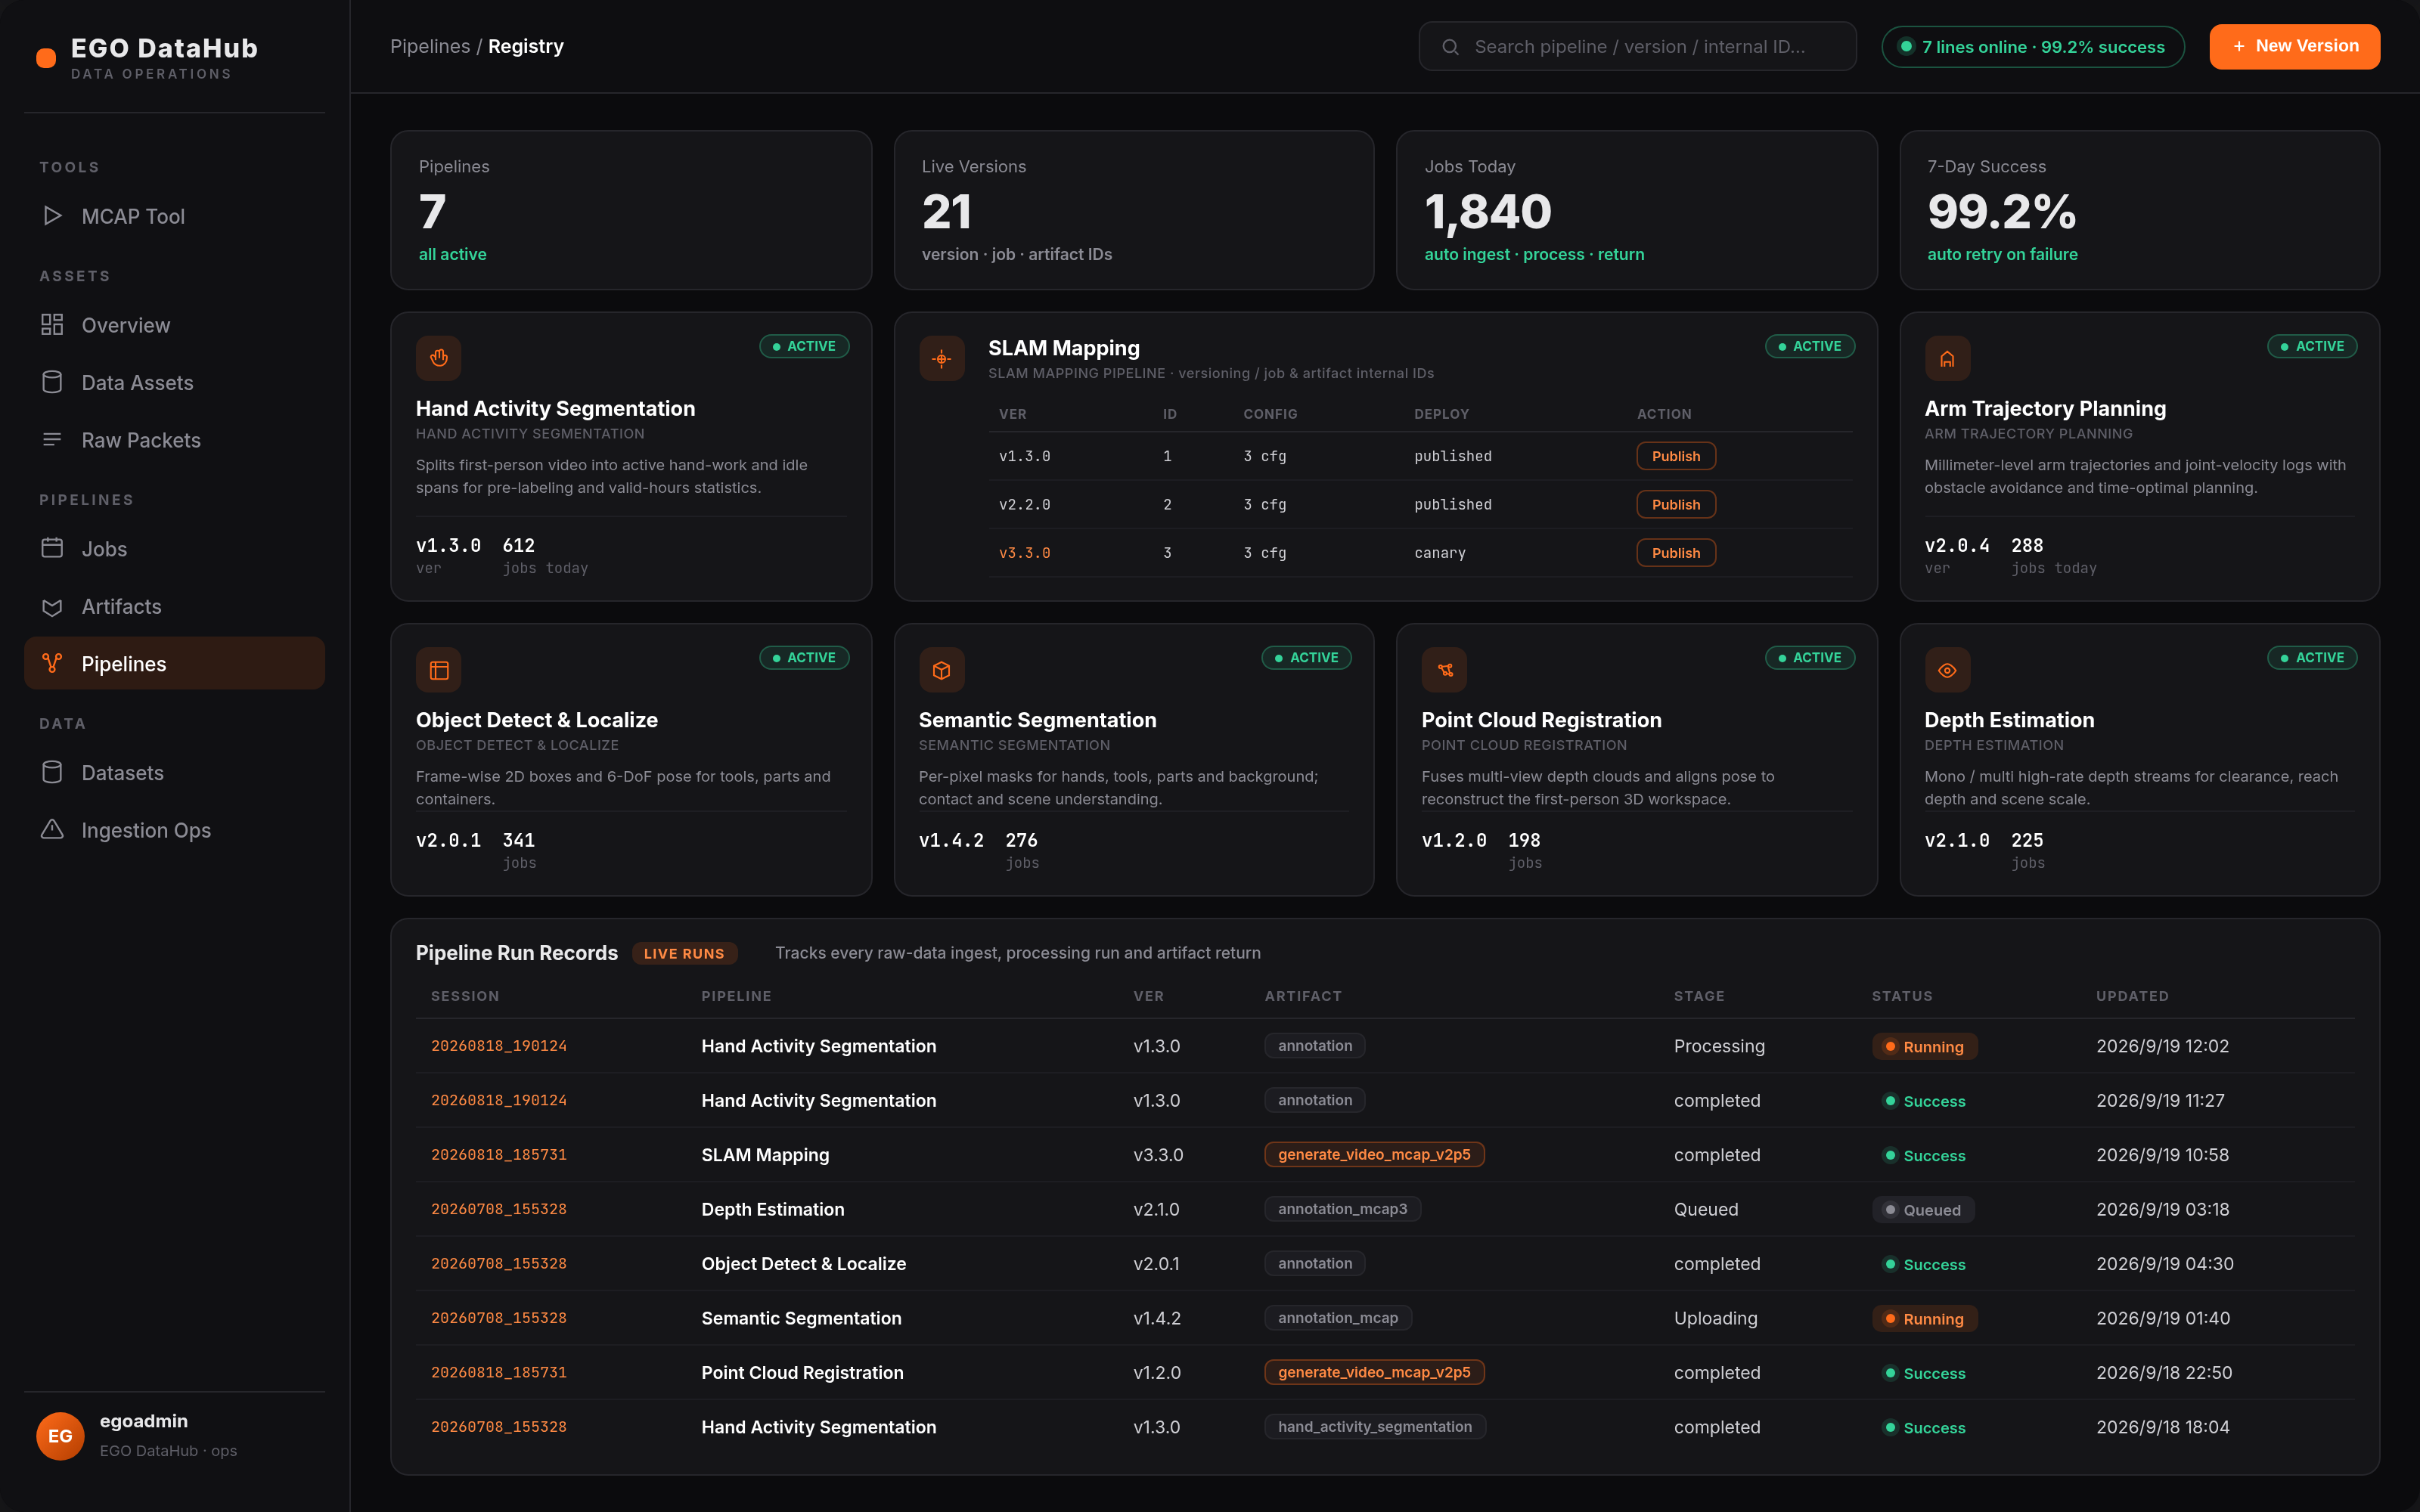
数据处理中枢:具身数据工具(MCAP / Foxglove 回放)、数据资产、算法产线(任务 / 产物 / 产线管理)、数据集与运维。Data-processing core: MCAP / Foxglove replay tool, data assets, algorithm pipelines (jobs / artifacts / registry), datasets and ops.
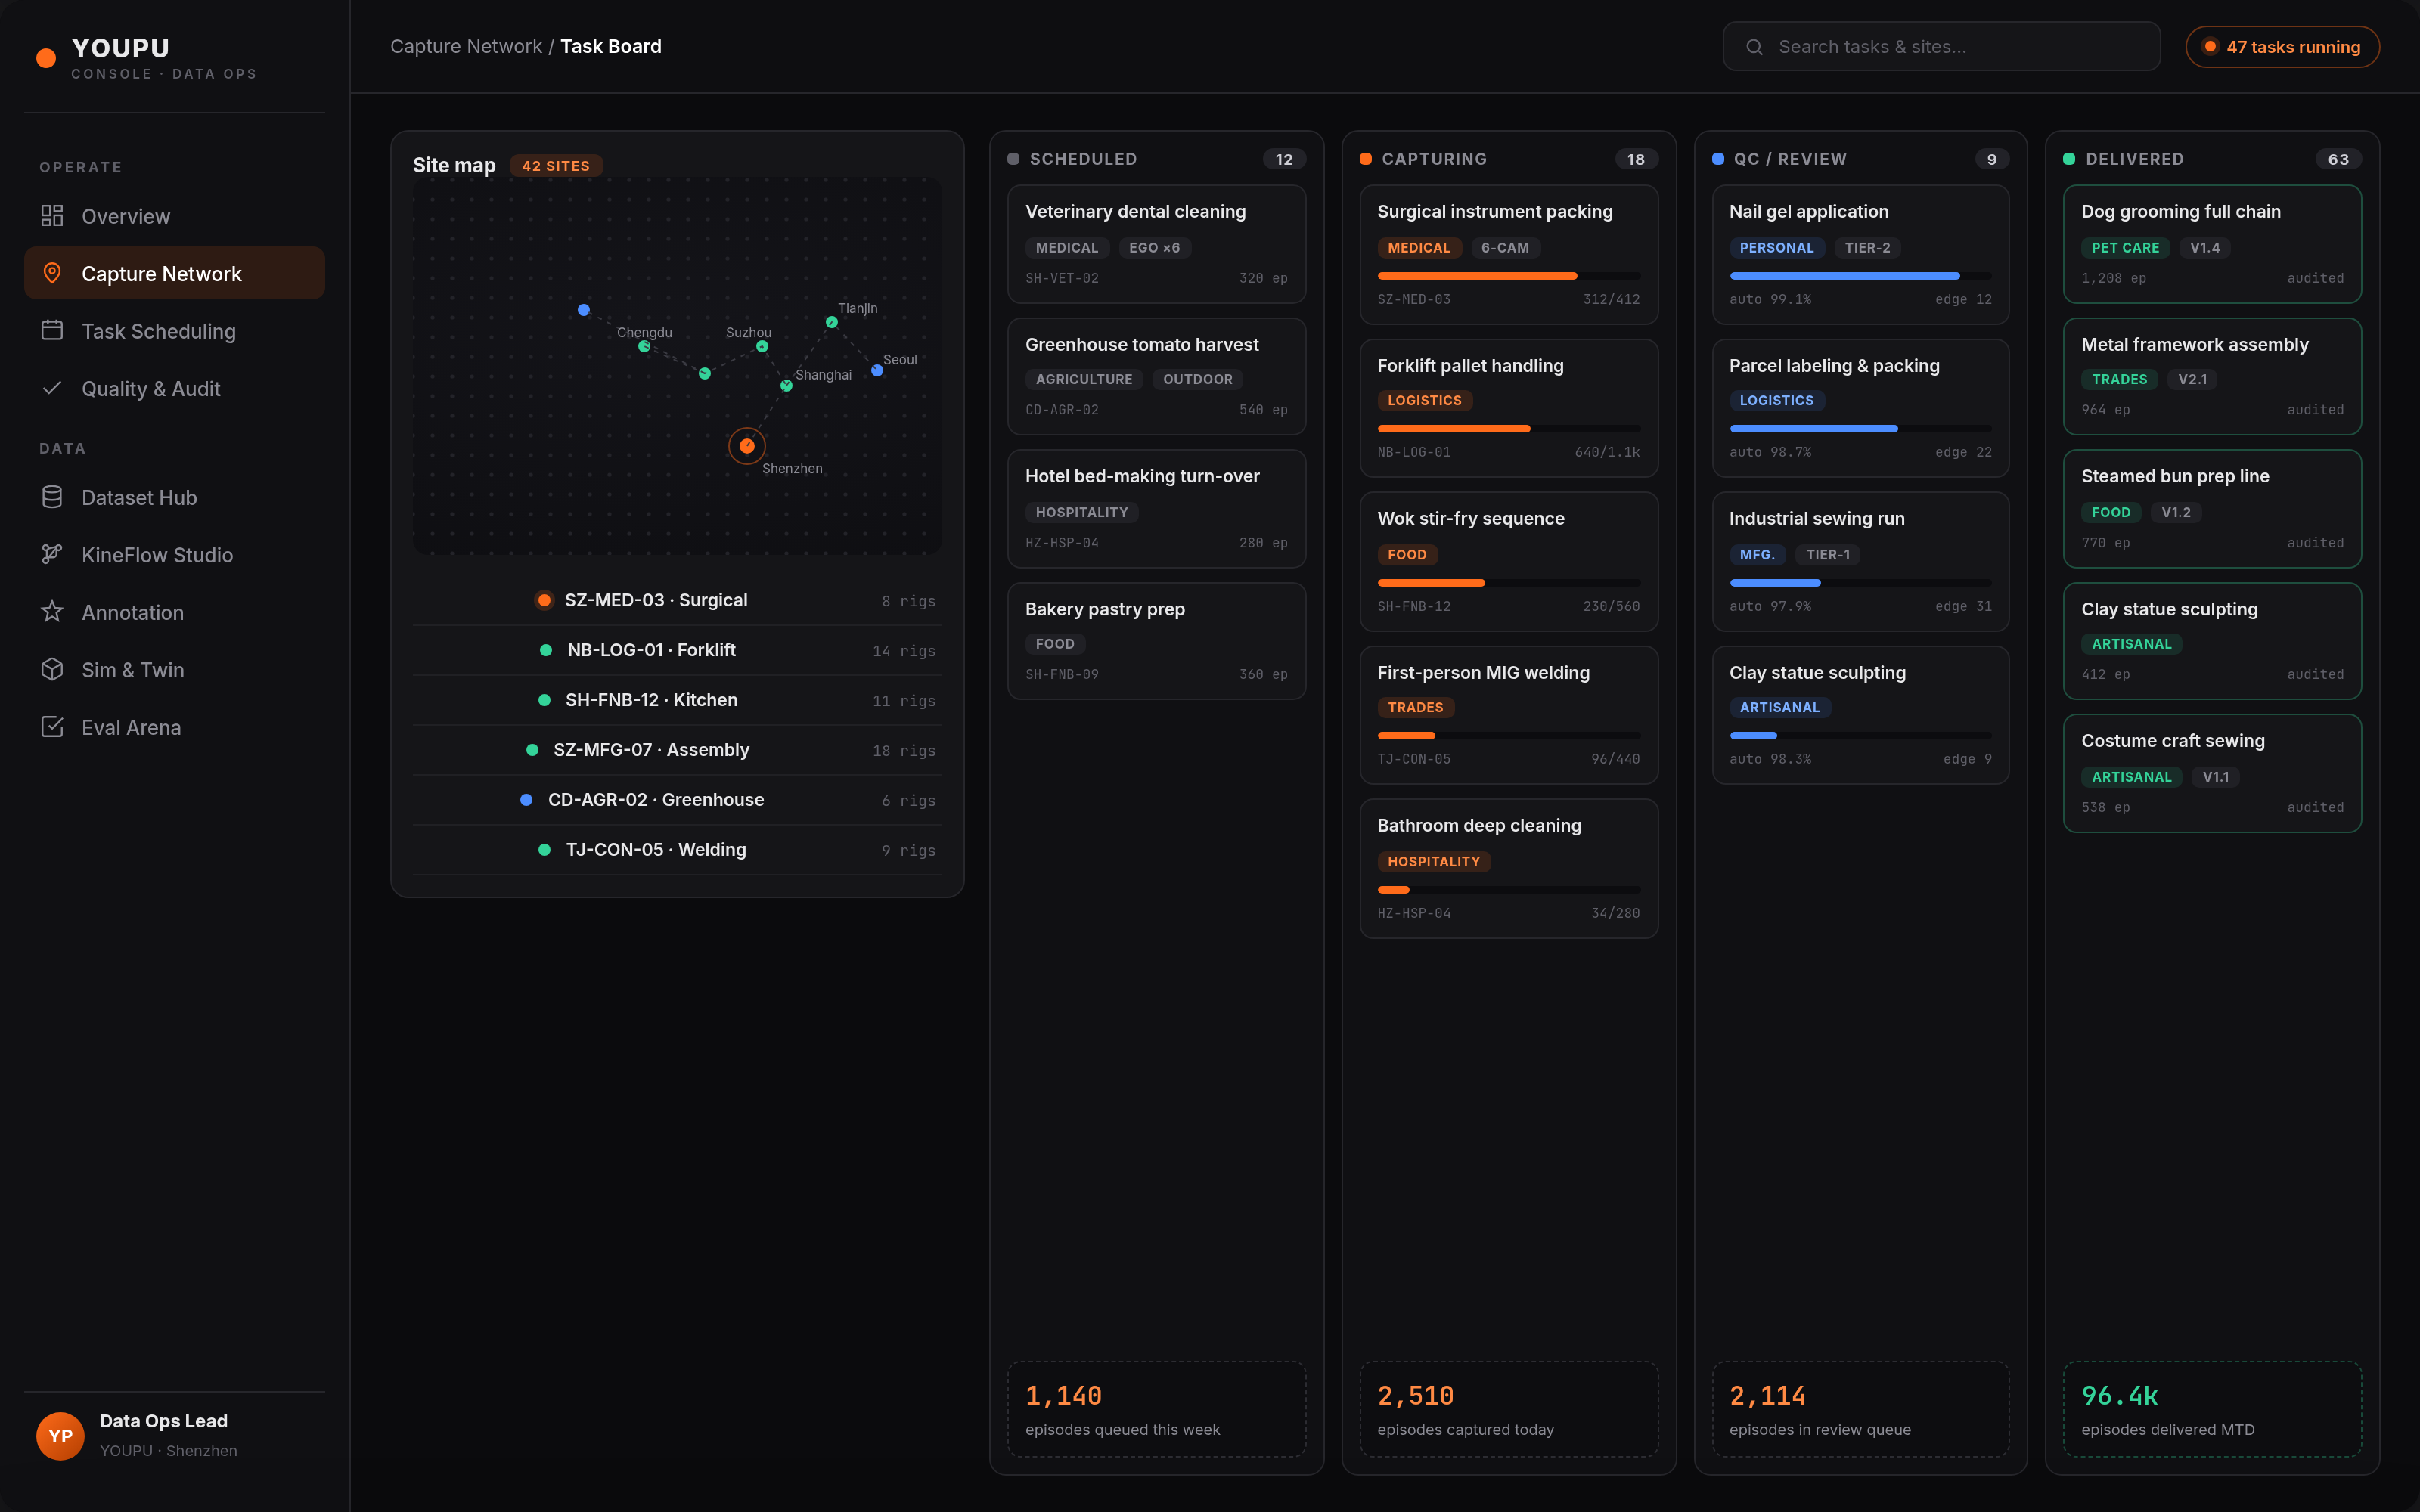
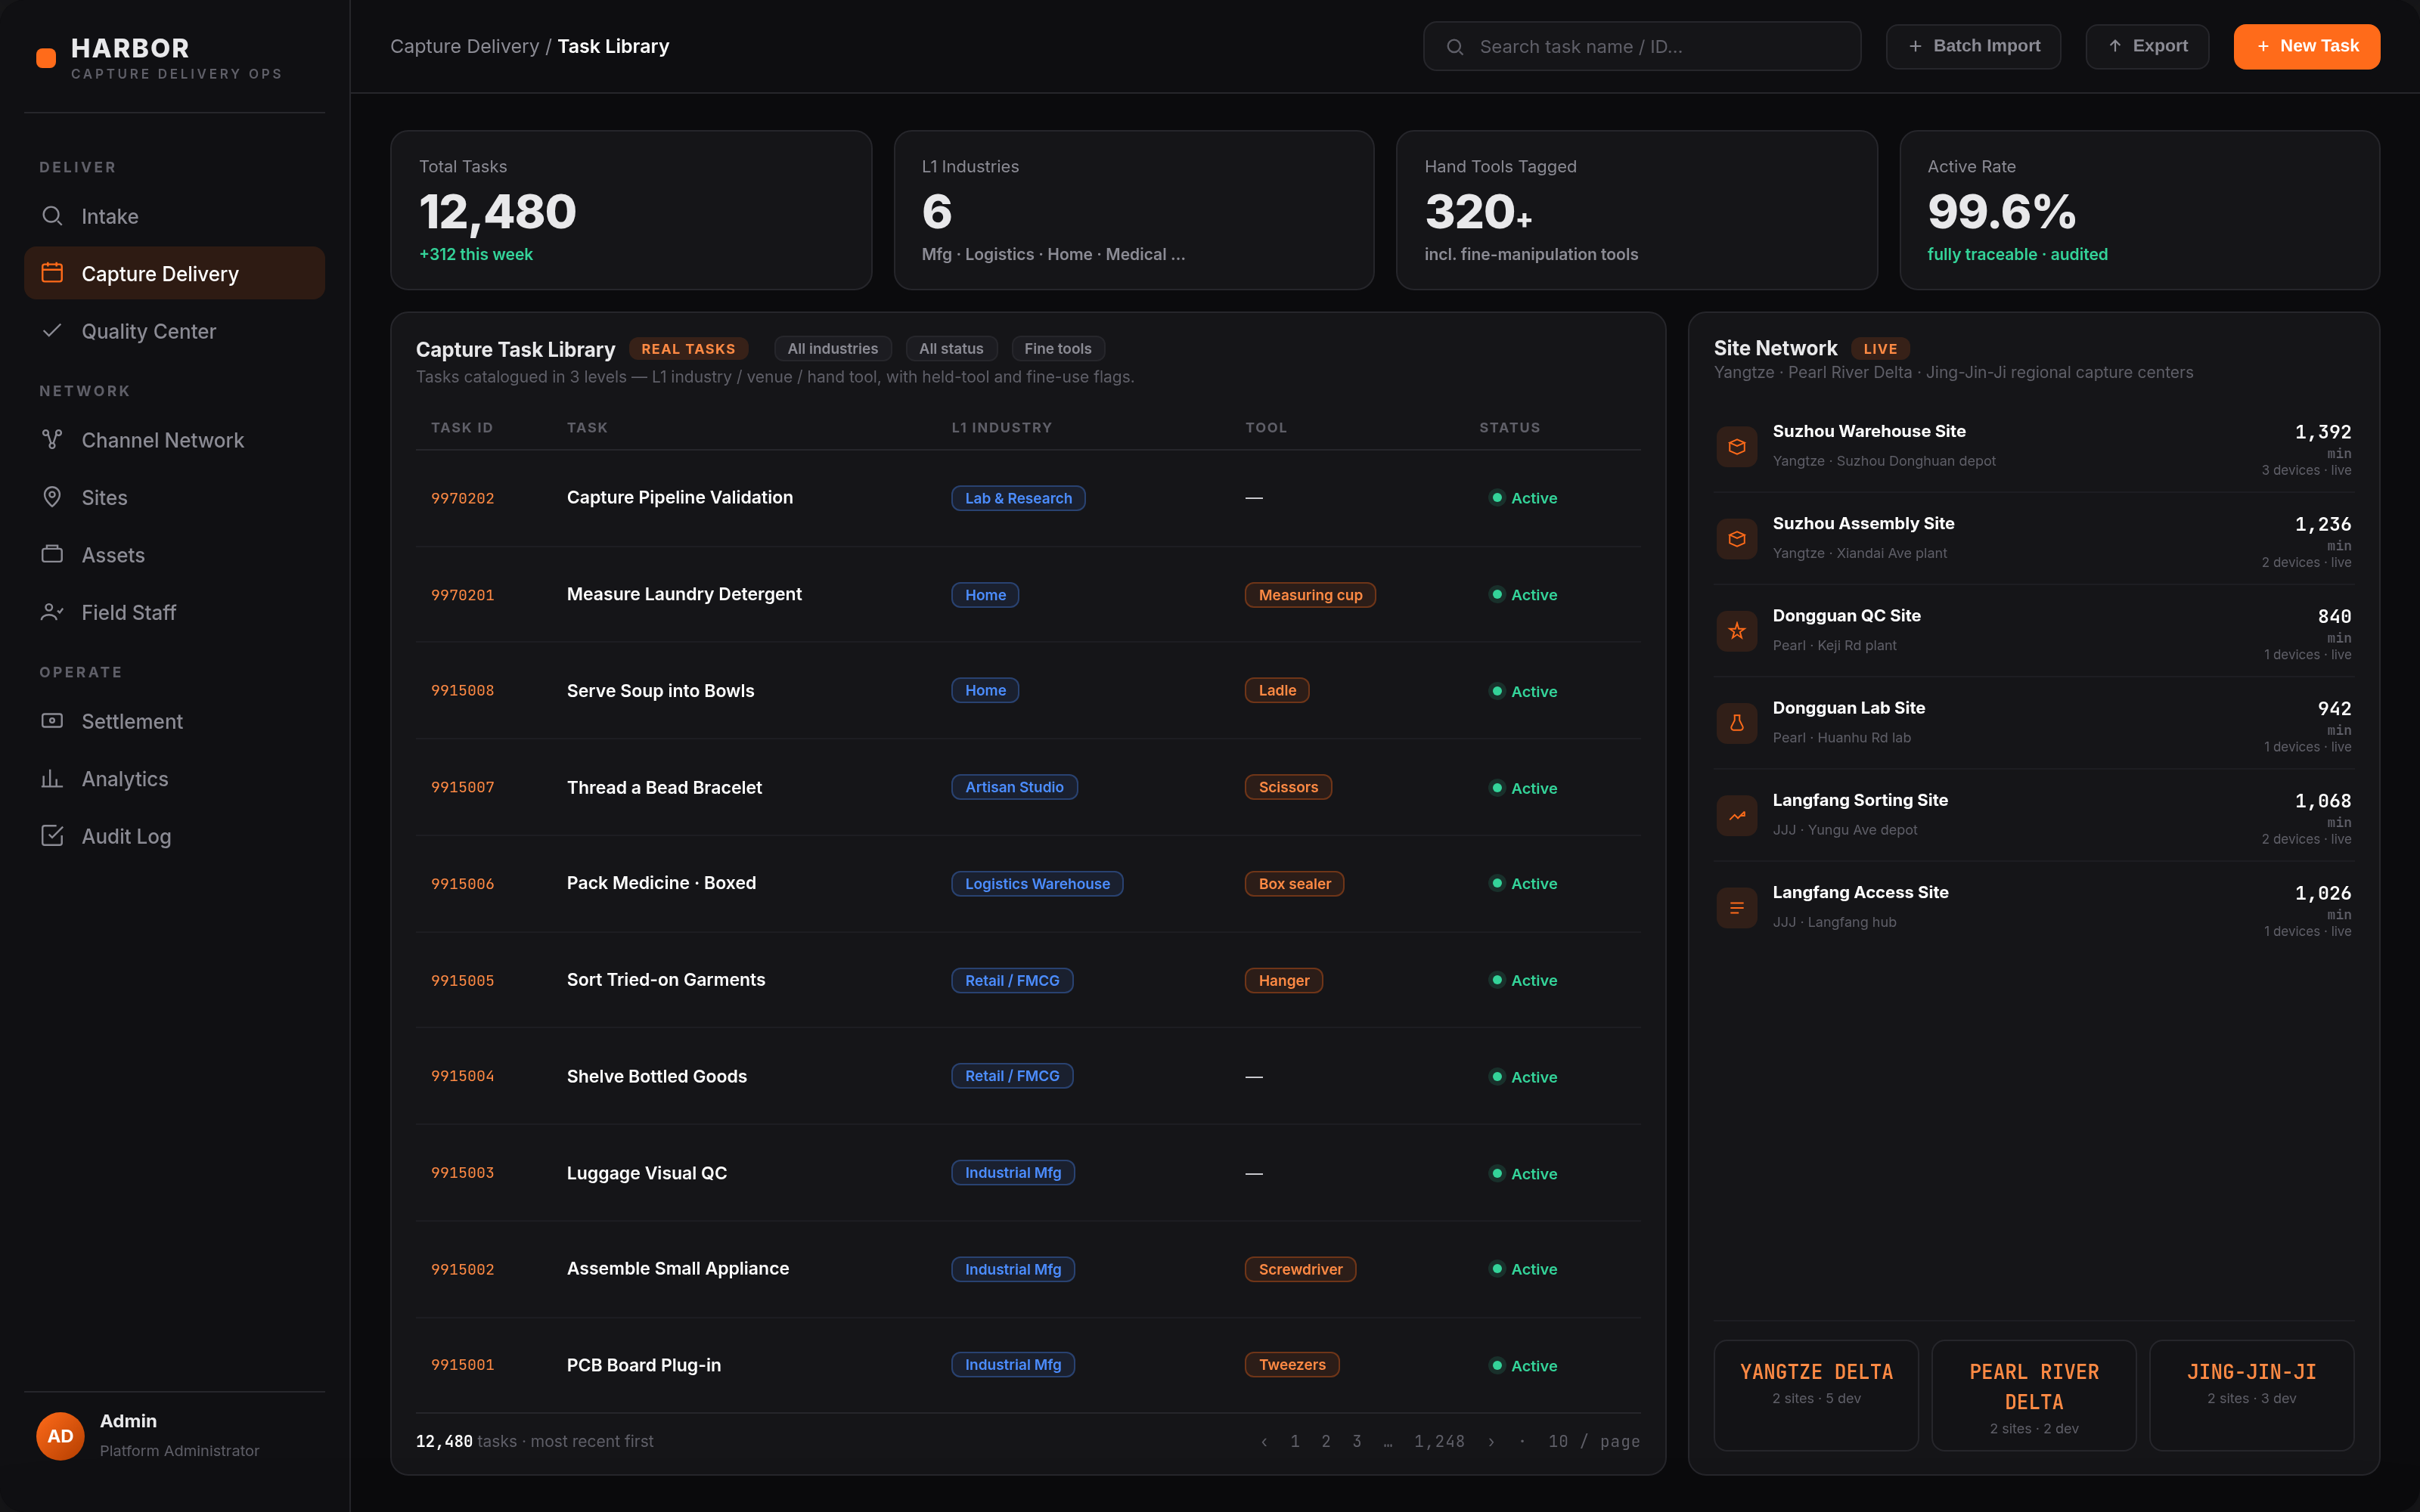
采集交付运营中枢:需求受理、采集交付、质量中心、渠道网络(采集点 / 设备 / 人员)、设备资产、结算与经营分析。Capture-delivery operations: intake, delivery, quality center, channel network (sites / devices / staff), assets, settlement and analytics.
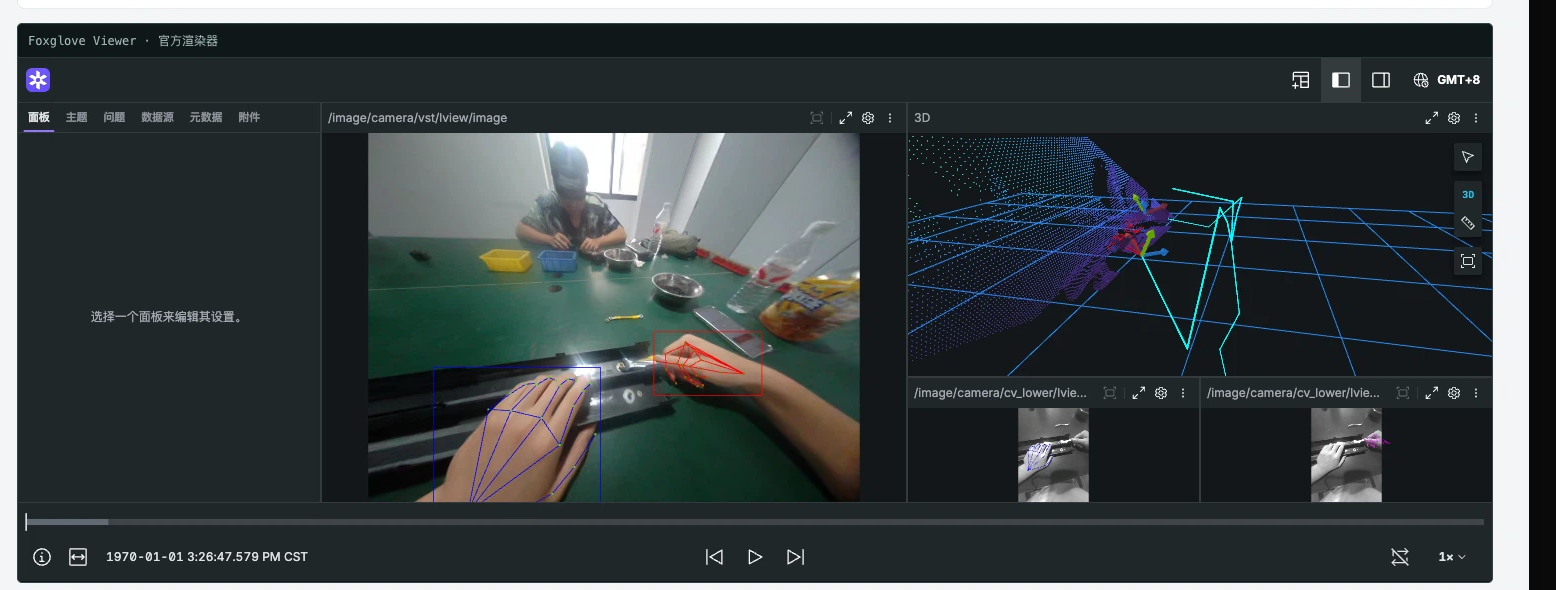
EGO DataHub · 具身数据工具 —— 本地 MCAP 回放(Foxglove 官方渲染器)EGO DataHub · MCAP Tool — local MCAP replay (Foxglove renderer)
82 路通道同步回放:多目 RGB、3D 点云、双手 21 关节骨架、深度与 IMU,逐帧质检与时间轴对齐。82 channels replayed in sync: multi-cam RGB, 3D point cloud, 21-joint two-hand skeleton, depth and IMU, with frame-level QC.
算法产线 · 7 条产线与版本管理Pipeline Registry · 7 lines & versioning
手部活动分段、SLAM 建图、机械臂轨迹规划、检测定位、语义分割、点云配准、深度估计,版本 / 任务 / 产物全程可追溯。Hand segmentation, SLAM, trajectory planning, detection, segmentation, point-cloud registration and depth — versions, jobs and artifacts all traceable.
采集交付 · 三级编目任务库与采集点网络Capture Delivery · 3-level task library & site network
任务按行业 / 场所 / 手持工具三级编目,覆盖家庭、医药仓储、超市、工厂;长三角、珠三角、京津冀采集点实时在线。Tasks catalogued by industry / venue / hand tool across home, pharma storage, supermarket and factory; Yangtze, Pearl-River and Jing-Jin-Ji sites live.
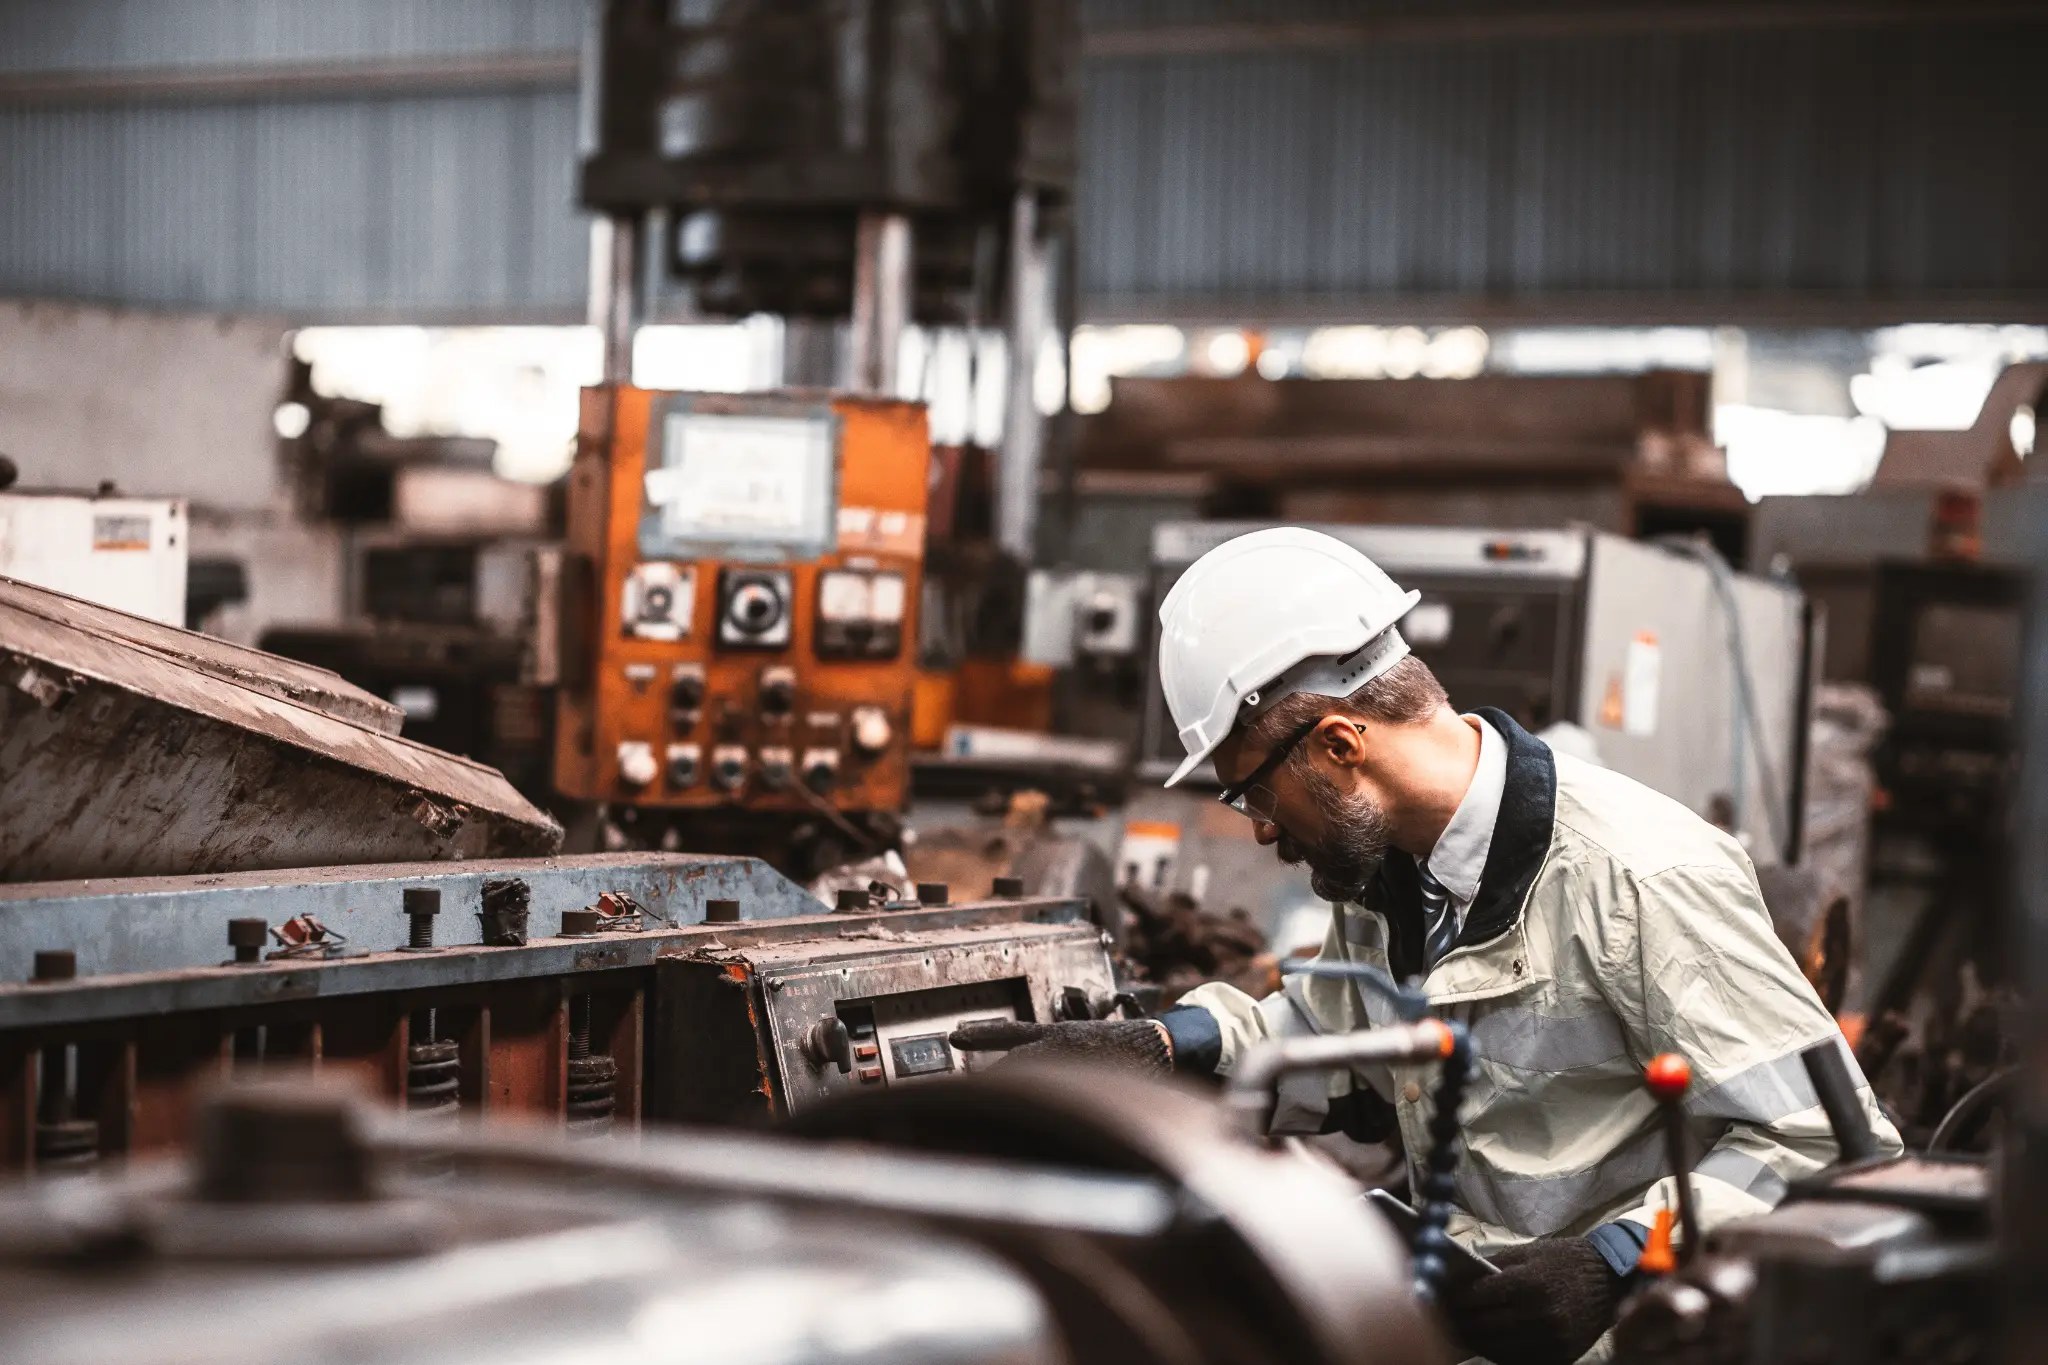
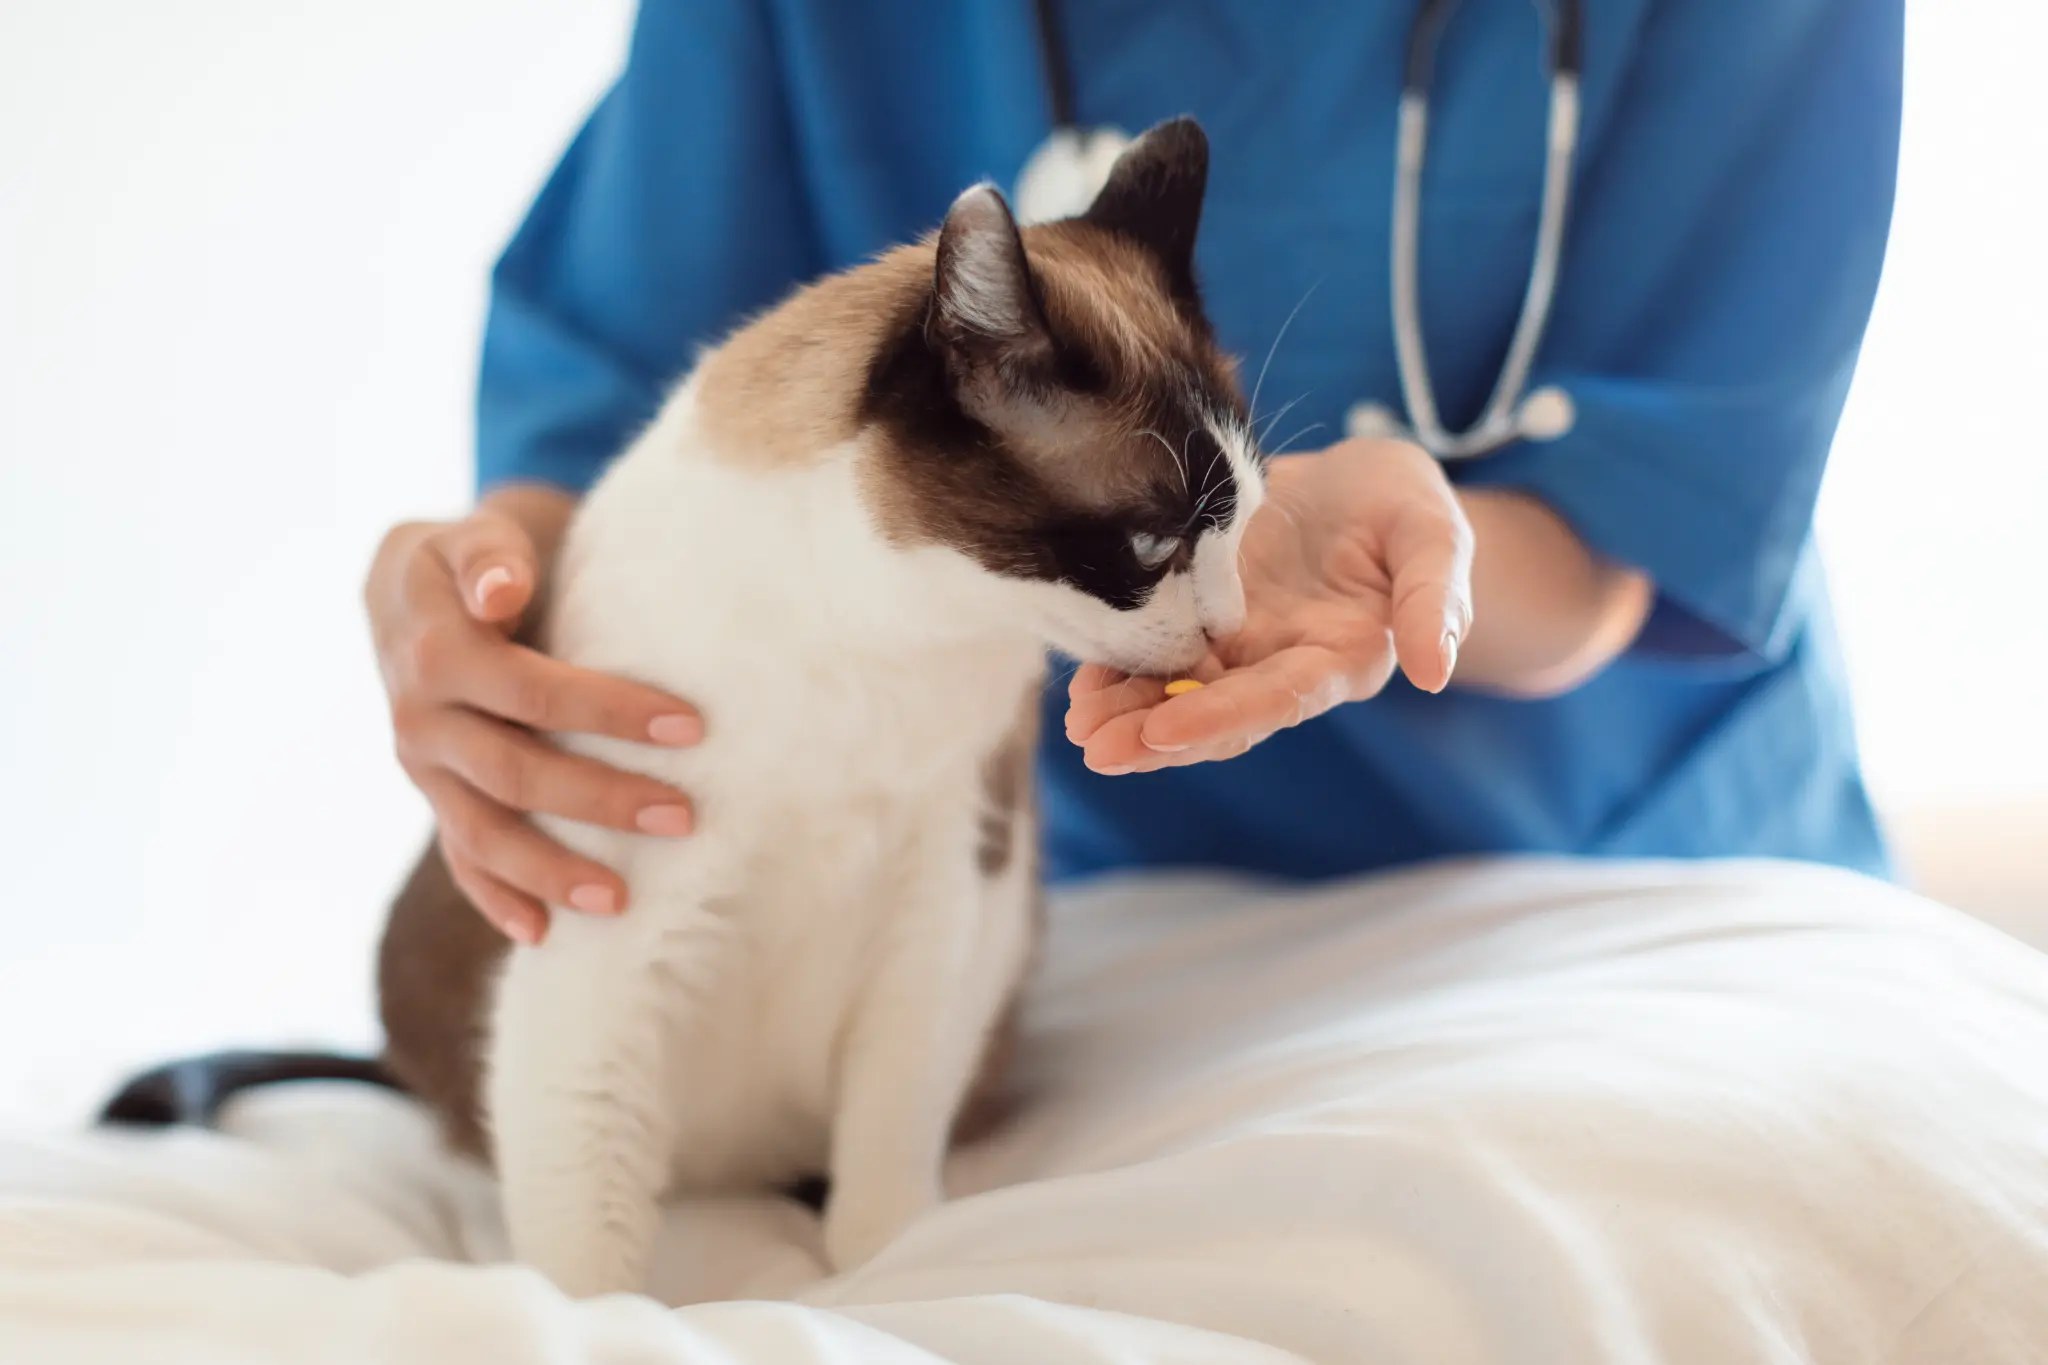
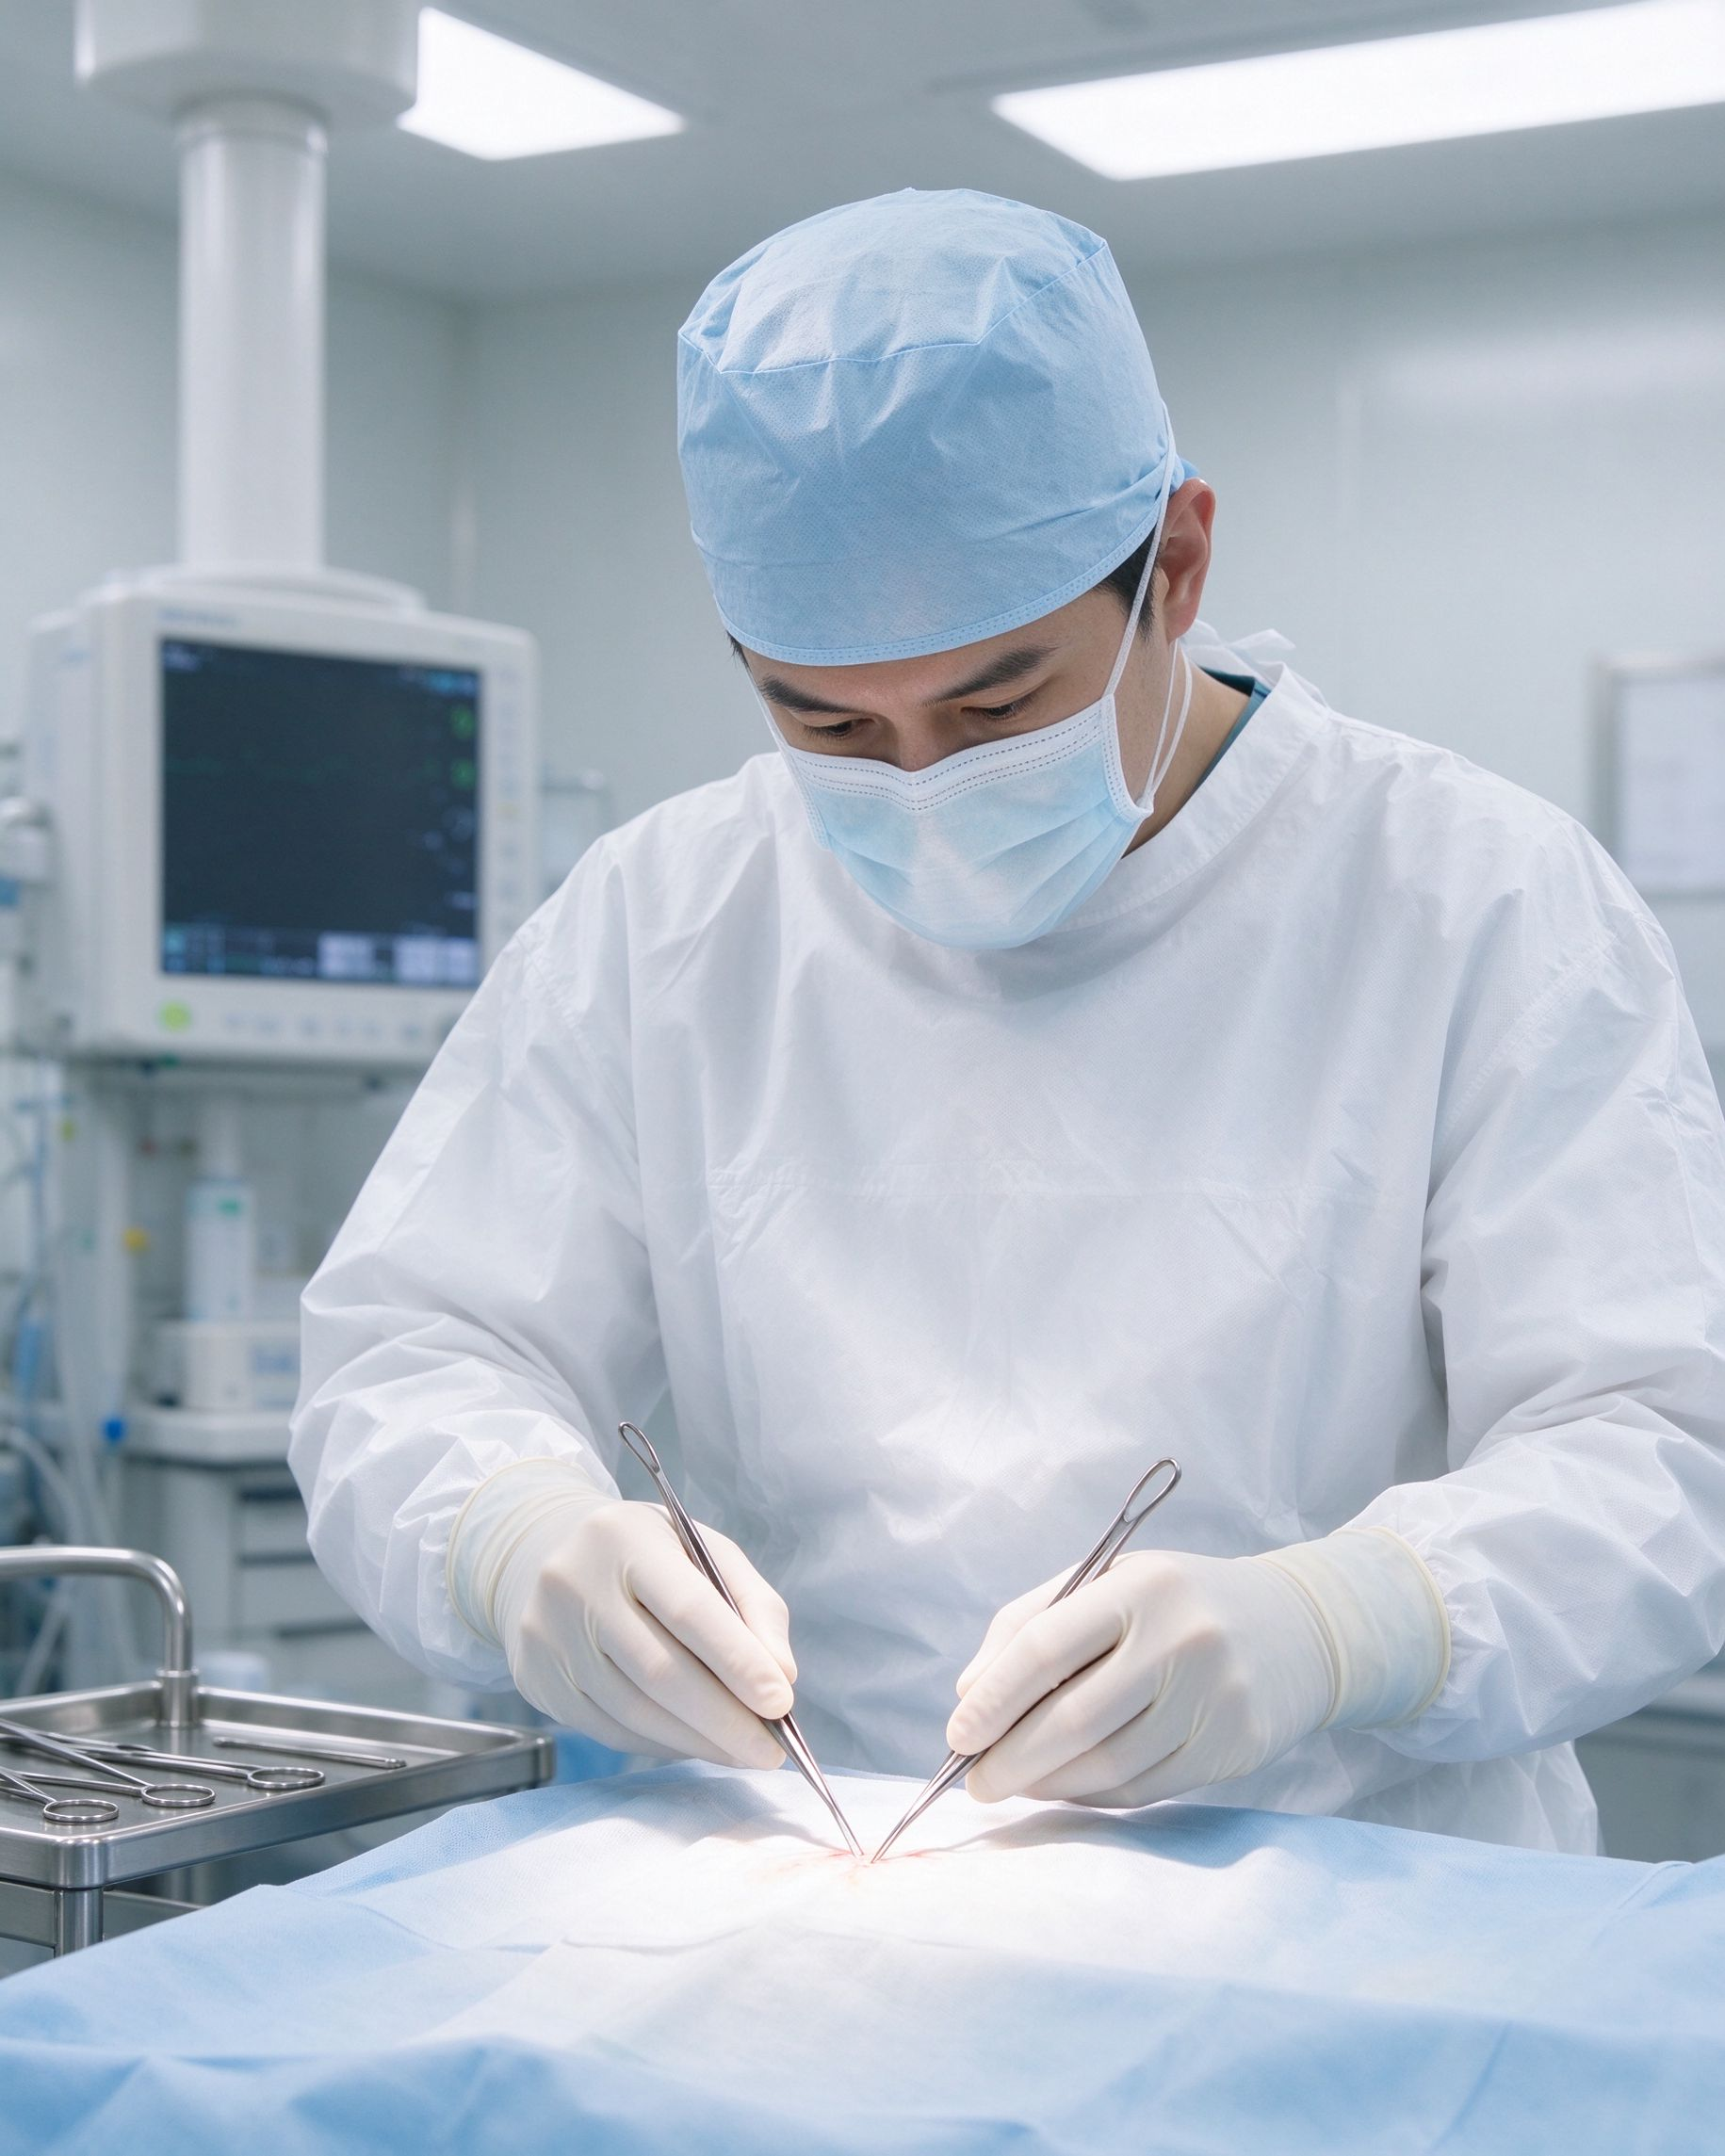
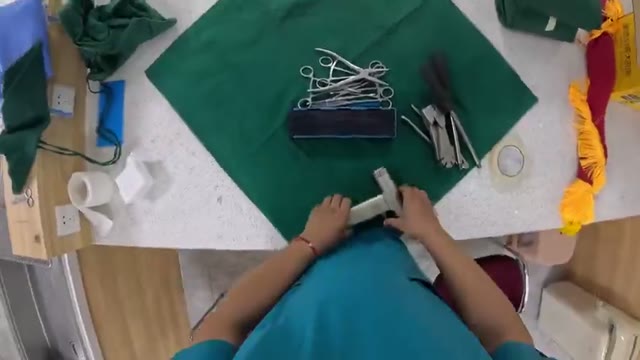
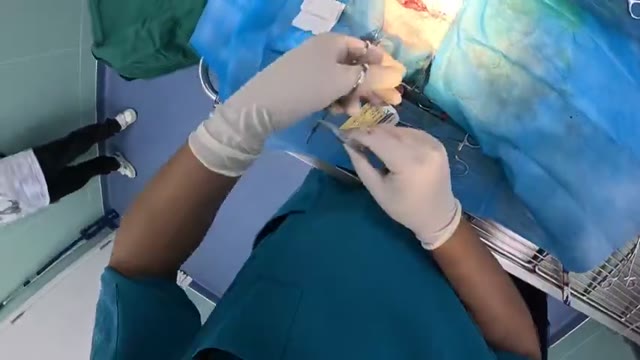
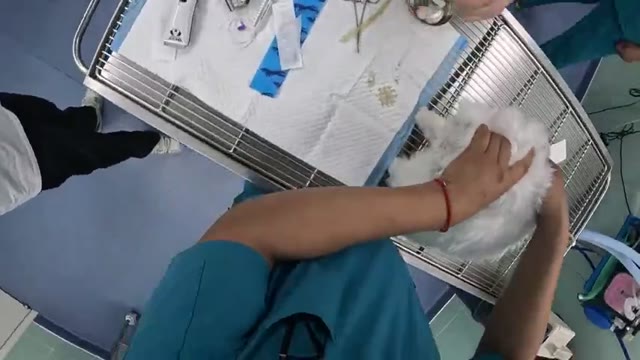
工厂只是其中一小部分。我们的采集网络覆盖制造、施工、物流、餐饮、零售与个人服务,并深入医疗手术、兽医、农业户外等小众长尾场景——全部第一人称视角。Factories are only a small part. Our network spans manufacturing, trades, logistics, F&B, retail and personal services, and reaches into surgery, veterinary and outdoor agriculture — all egocentric.


高精度、强合规要求的医疗作业同样在我们的采集范围内:手术器械打包、外科手术操作、兽医宠物护理等。配合 PII 自动脱敏与企业级数据合规流程,敏感场景也能安全交付。
High-precision, compliance-heavy medical work is within scope: surgical instrument packing, surgical procedures, veterinary pet care and more. Automated PII masking and enterprise compliance make sensitive scenes safe to deliver.


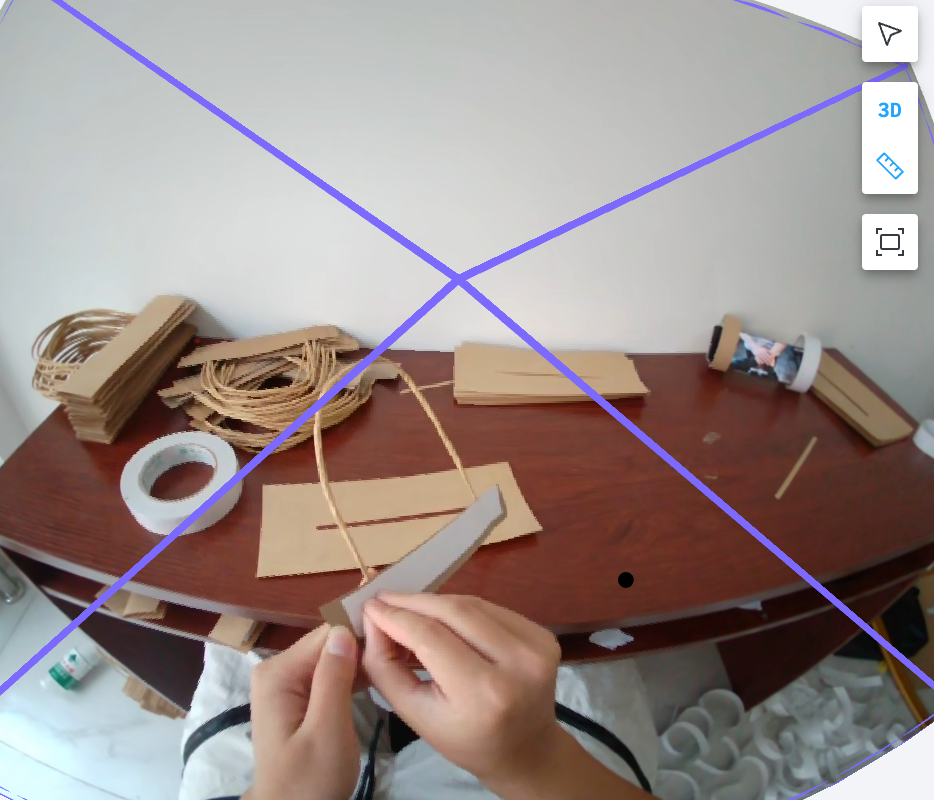
悬停预览,点击进入全屏播放。全部为真实作业现场第一人称画面。Hover to preview, click for fullscreen. All real work-site, first-person footage.
输出标准 MCAP / JSON 与主流数据格式,配套仿真环境,无需再做繁琐的数据清洗与对齐。Standard MCAP / JSON output in mainstream formats, with simulation environments — no tedious re-cleaning or re-alignment.
我们既交付设备与数据管线,也长期通过采集网络收购小众、高价值的第一人称真实作业数据——两条通道都开放。We deliver hardware and data pipelines, and continuously buy niche, high-value egocentric real-task data through our capture network — both channels are open.
长期收购双目第一人称小众、高价值真实作业数据,合格数据 US$15–20/小时;钟表修理、金属加工、牙科、宠物美容等场景优先,饱和场景不收。We continuously buy stereo egocentric niche, high-value real-task data at US$15–20 per accepted hour; watch repair, metalworking, dental and pet grooming prioritized; saturated scenes excluded.
下载数据收购指南 Download Sourcing GuideY6 设备阶梯定价、批量与 OEM/ODM、管线软件授权 / 订阅方案,完整报价与条款请查阅价格表,或直接联系商务。Tiered Y6 pricing, volume & OEM/ODM, and pipeline license / subscription plans — see the price list for full rates and terms, or contact sales.
下载 Y6 价格表 Download Price List从六目设备、采集网络到 KineFlow 处理产线、EGO DataHub 平台与仿真评测,整套私有化、交钥匙落地,让你的团队持续自产归你所有、可直接训练的第一人称数据;设备也可单独批量采购。From six-camera headsets and the capture network to KineFlow processing, the EGO DataHub platform and sim/eval — delivered turnkey, on-premises — so your team keeps producing its own ready-to-train egocentric data. Headsets are also sold separately in volume.